

ENGINEAI PM01
Technical Highlights
-
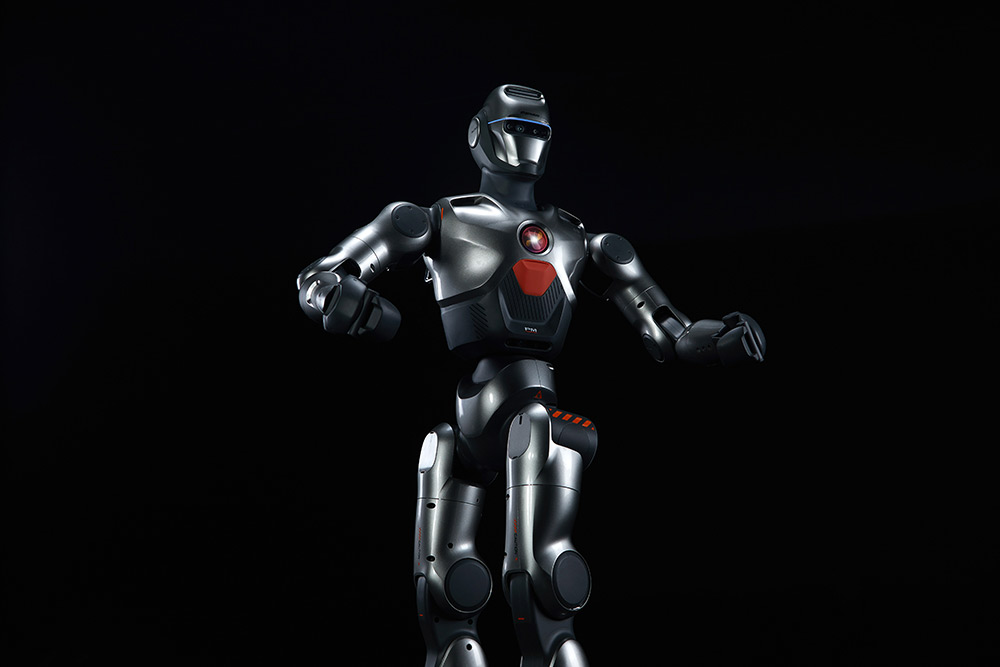
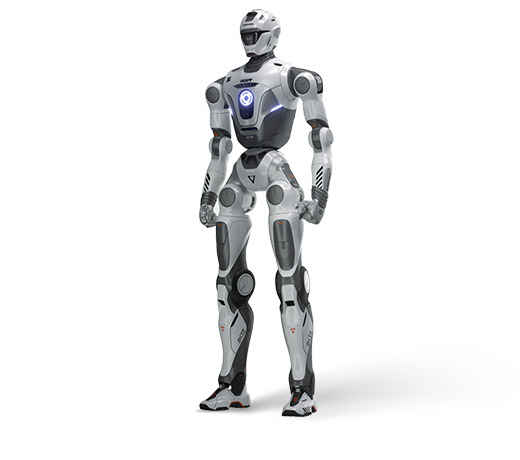
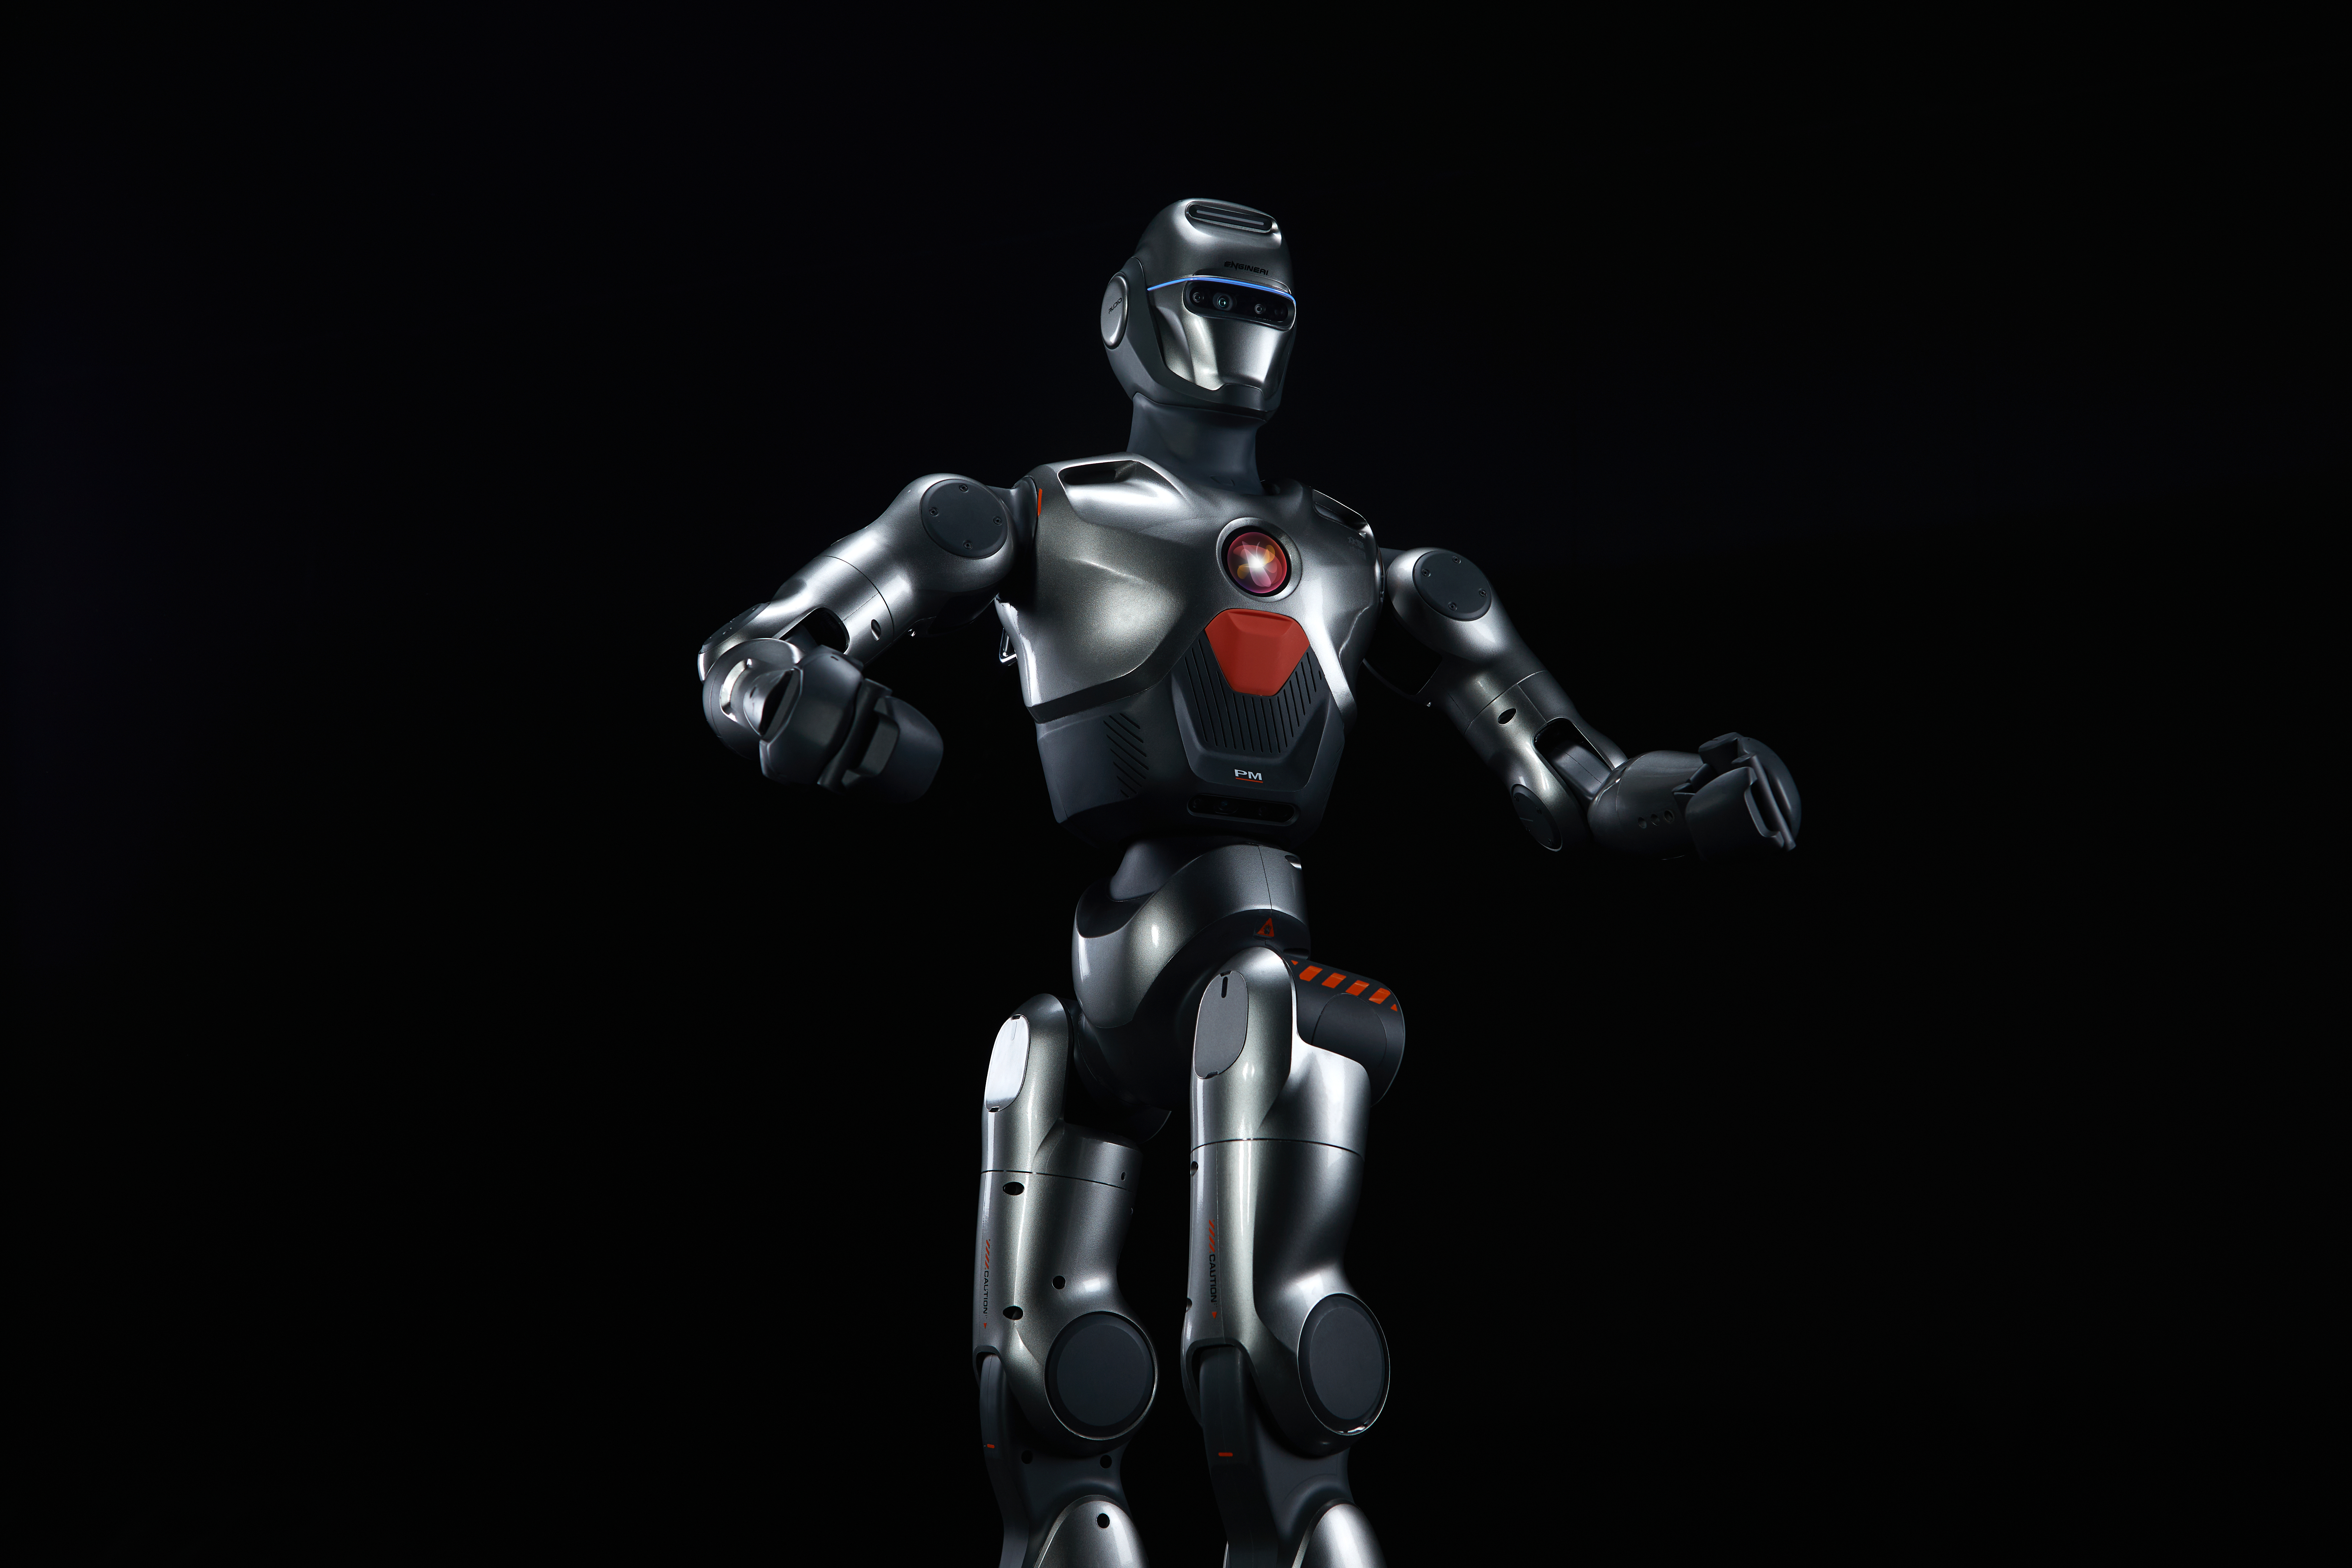
Elegant Aesthetic, Evolving a Classic
Balancing design beauty with mechanical dynamic performance.
-
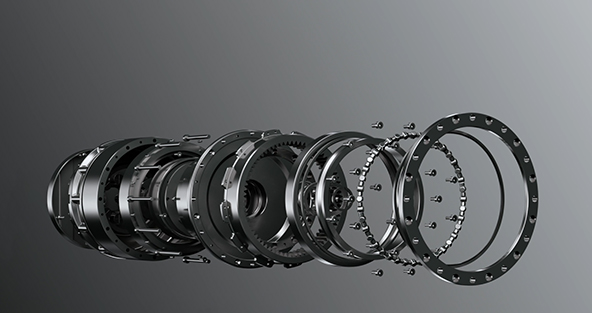
Full-Stack Proprietary Actuator Design
Integrated joint module delivering a peak torque of 130 N·m.
-
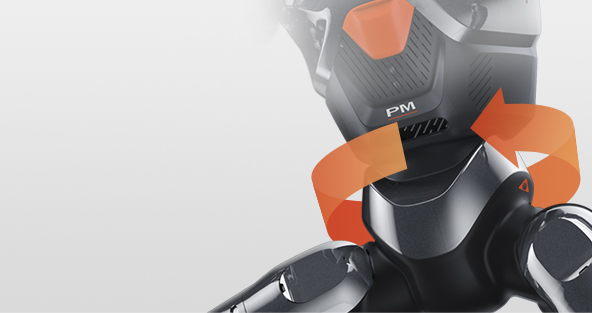
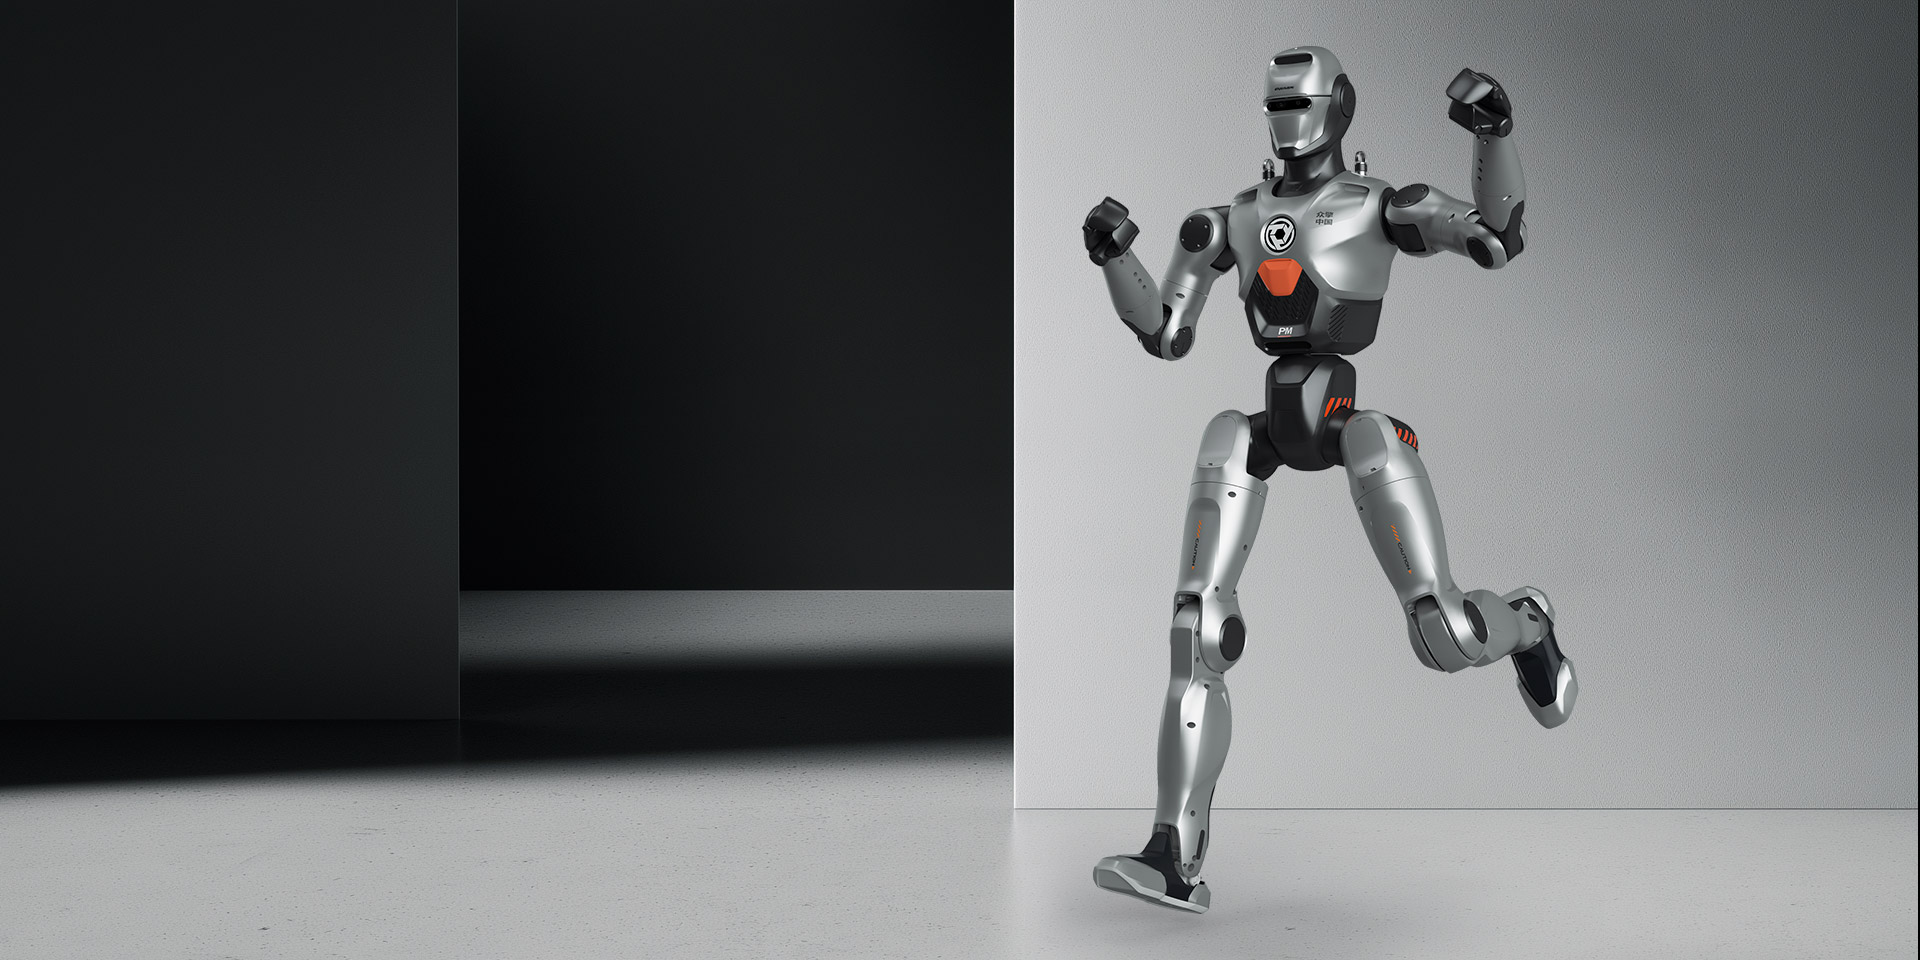
Exceptional Mobility
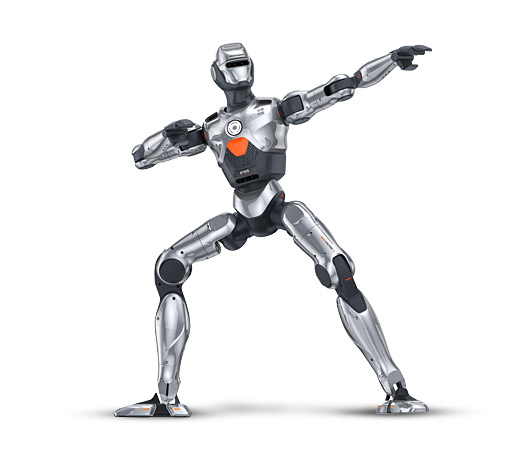
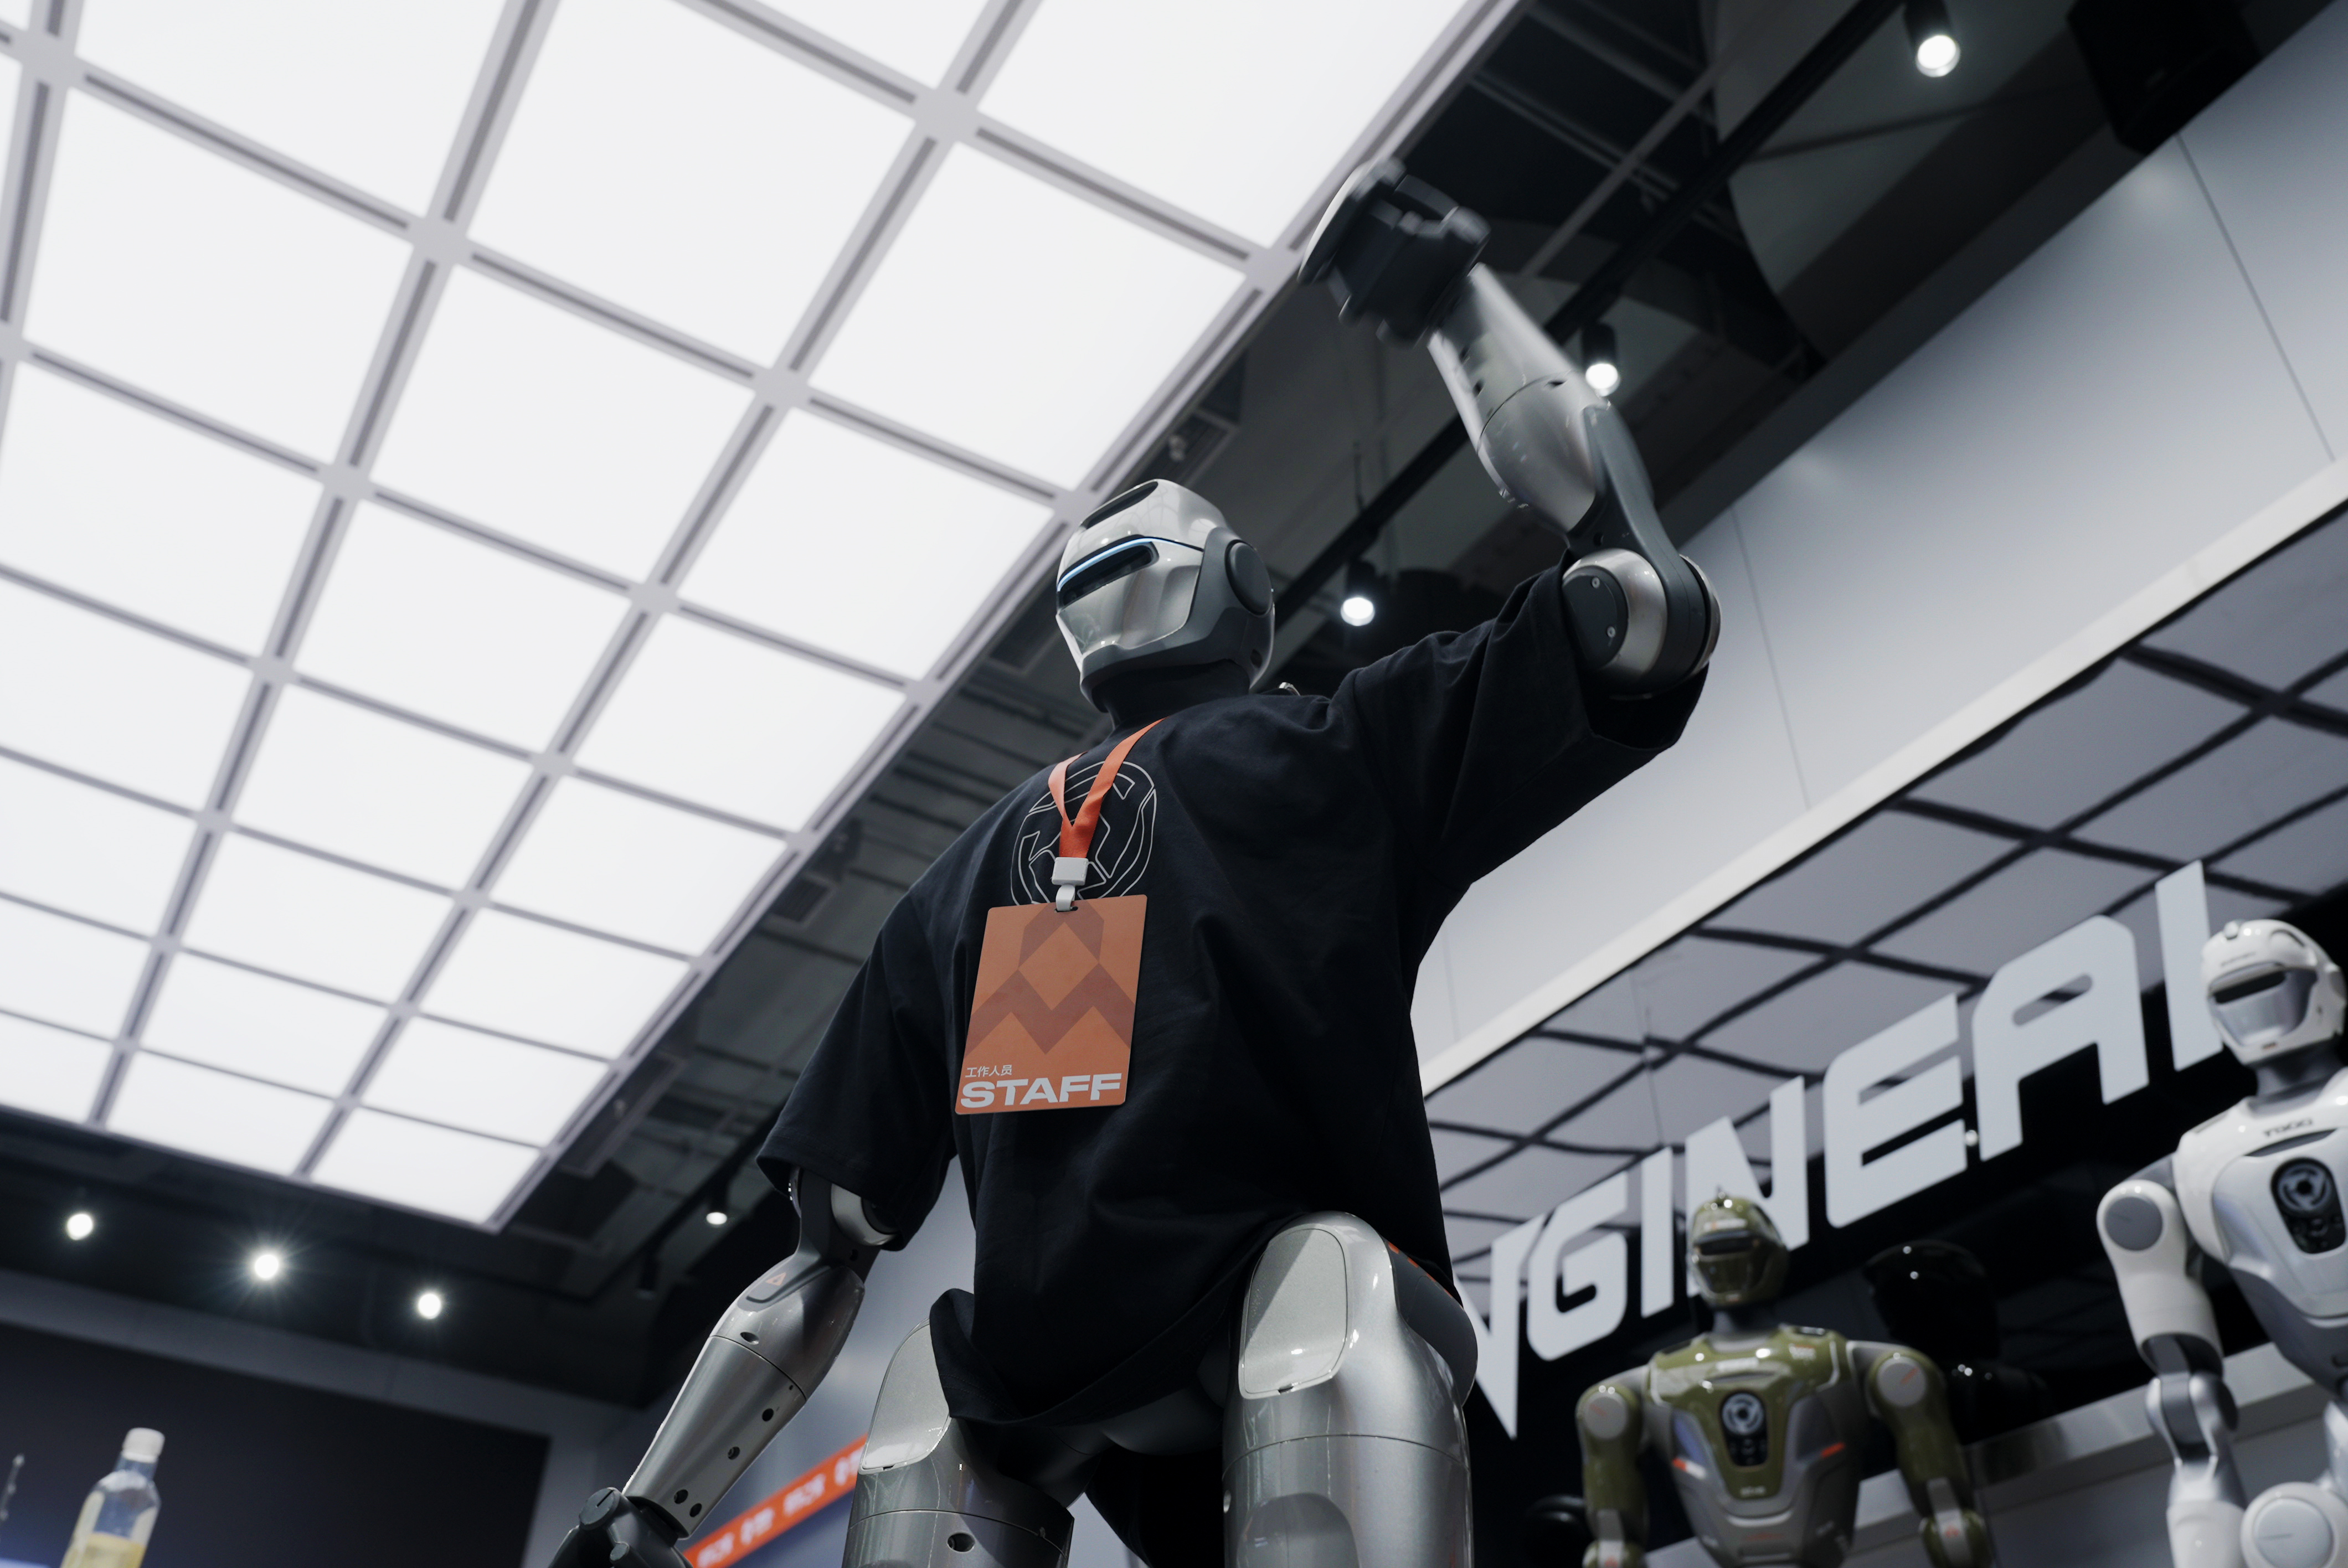
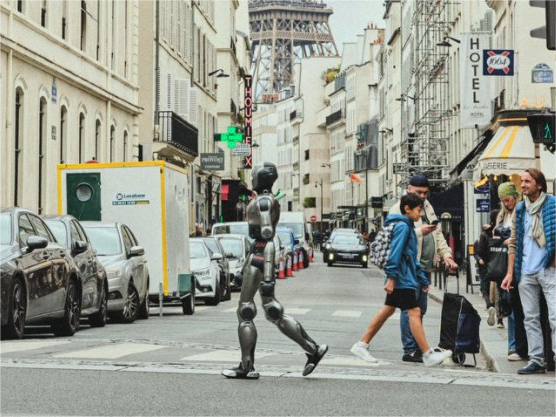
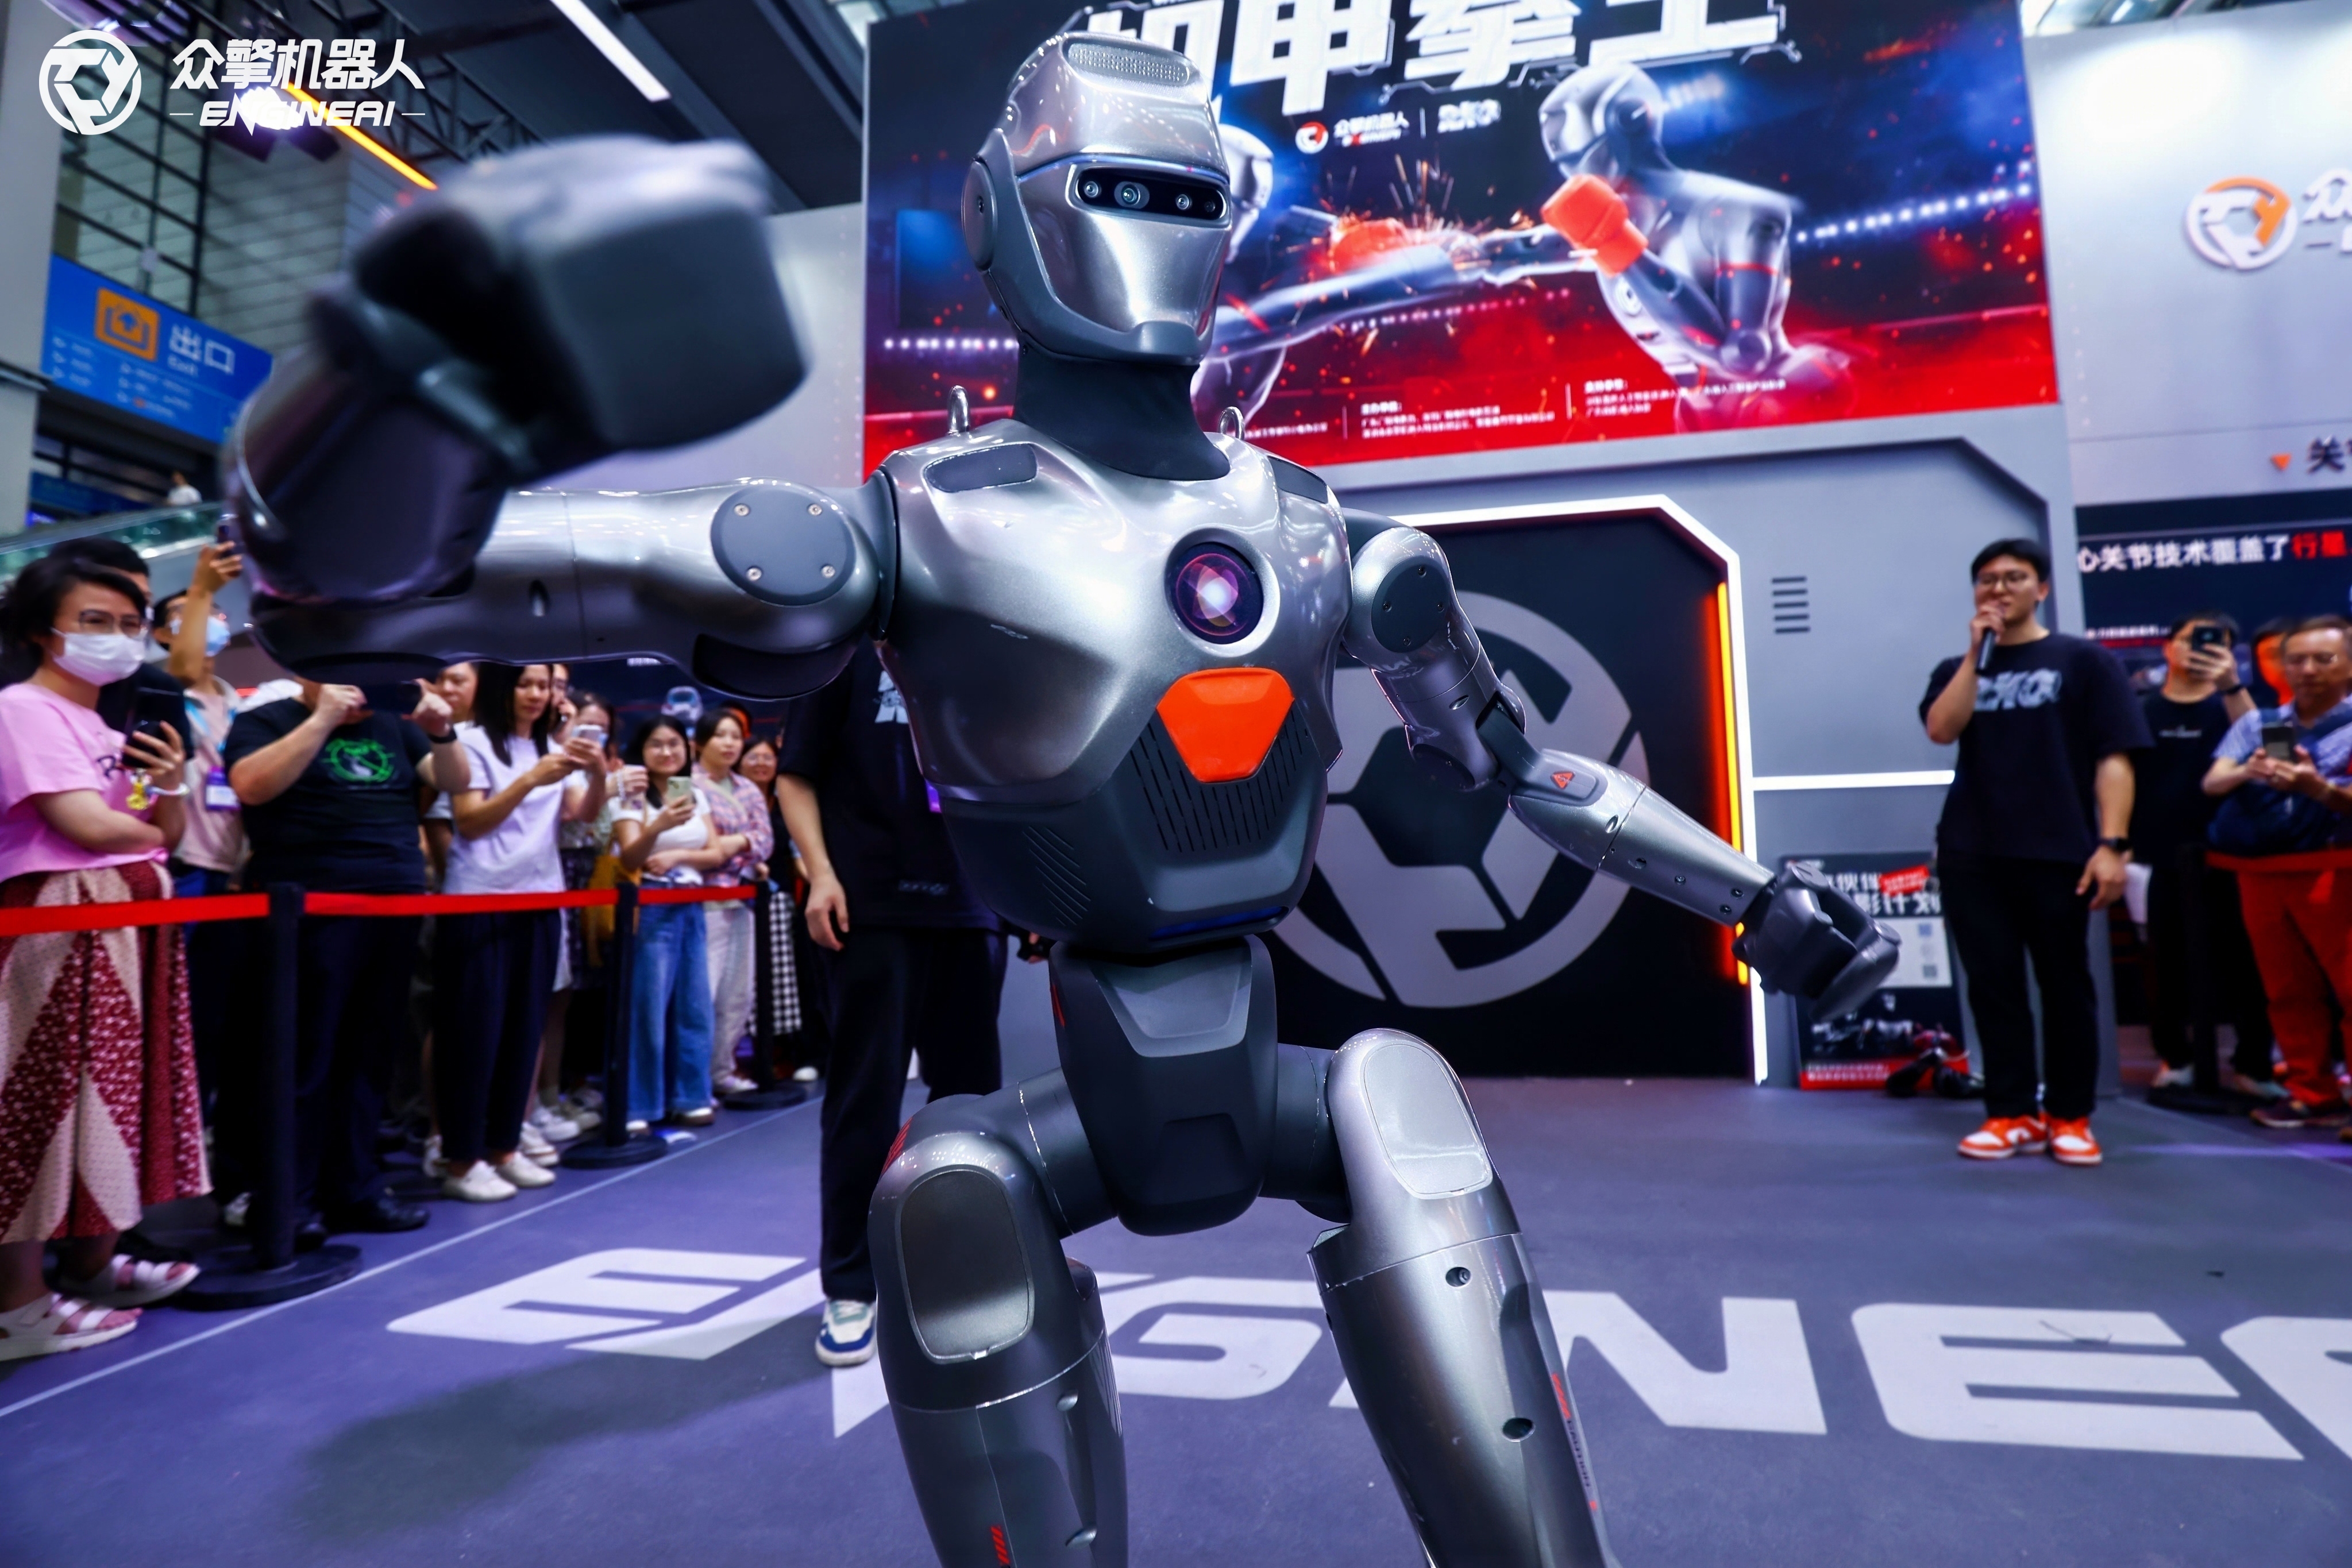
≥23 total degrees of freedom (DoF), 320° waist rotation, enabling complex movements like the "Axe Dance."
-
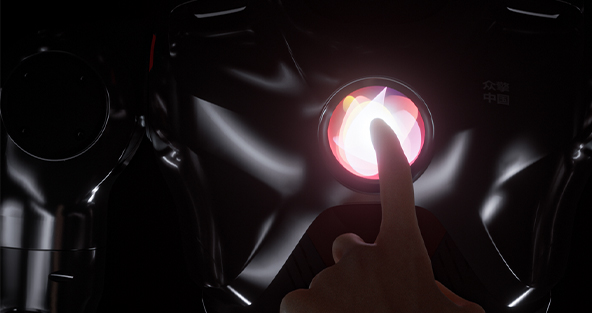
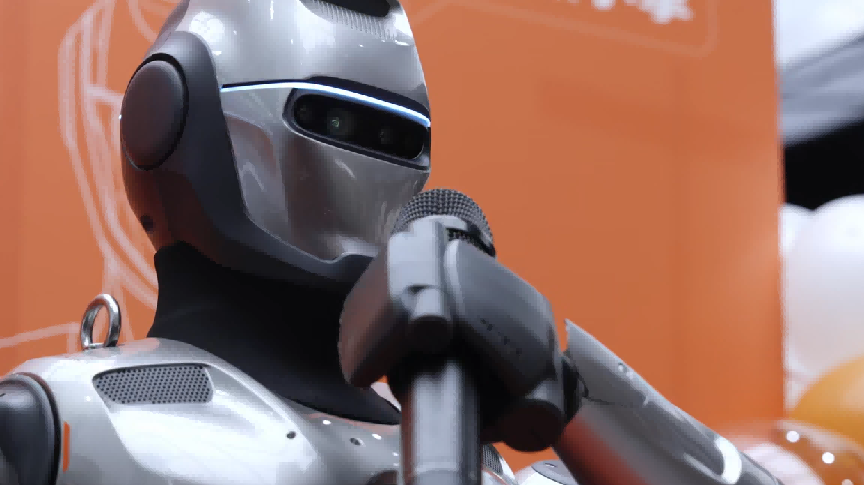
Interactive Core Display
Creating a new multi-dimensional intelligent interaction experience.
-
Ultimate Openness, Co-creating the Ecosystem
Providing low-level hardware interfaces and code support for training and deployment.

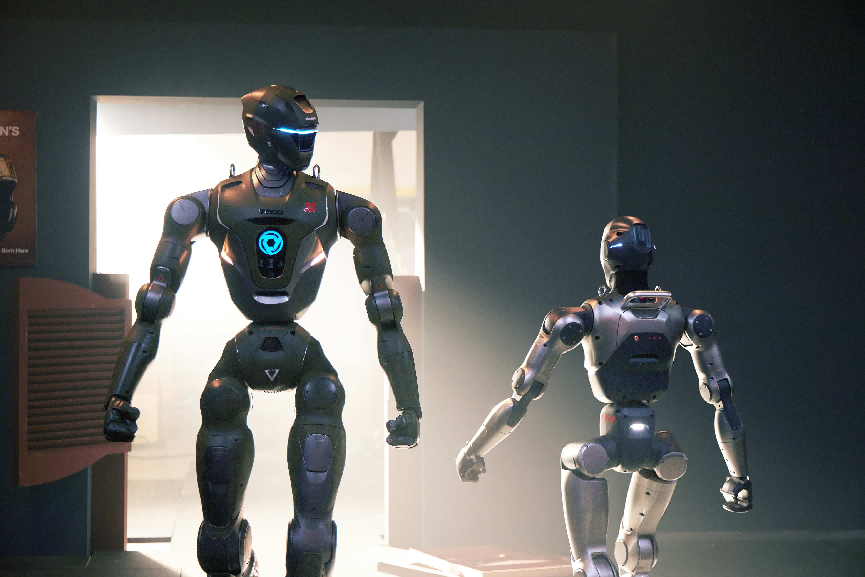
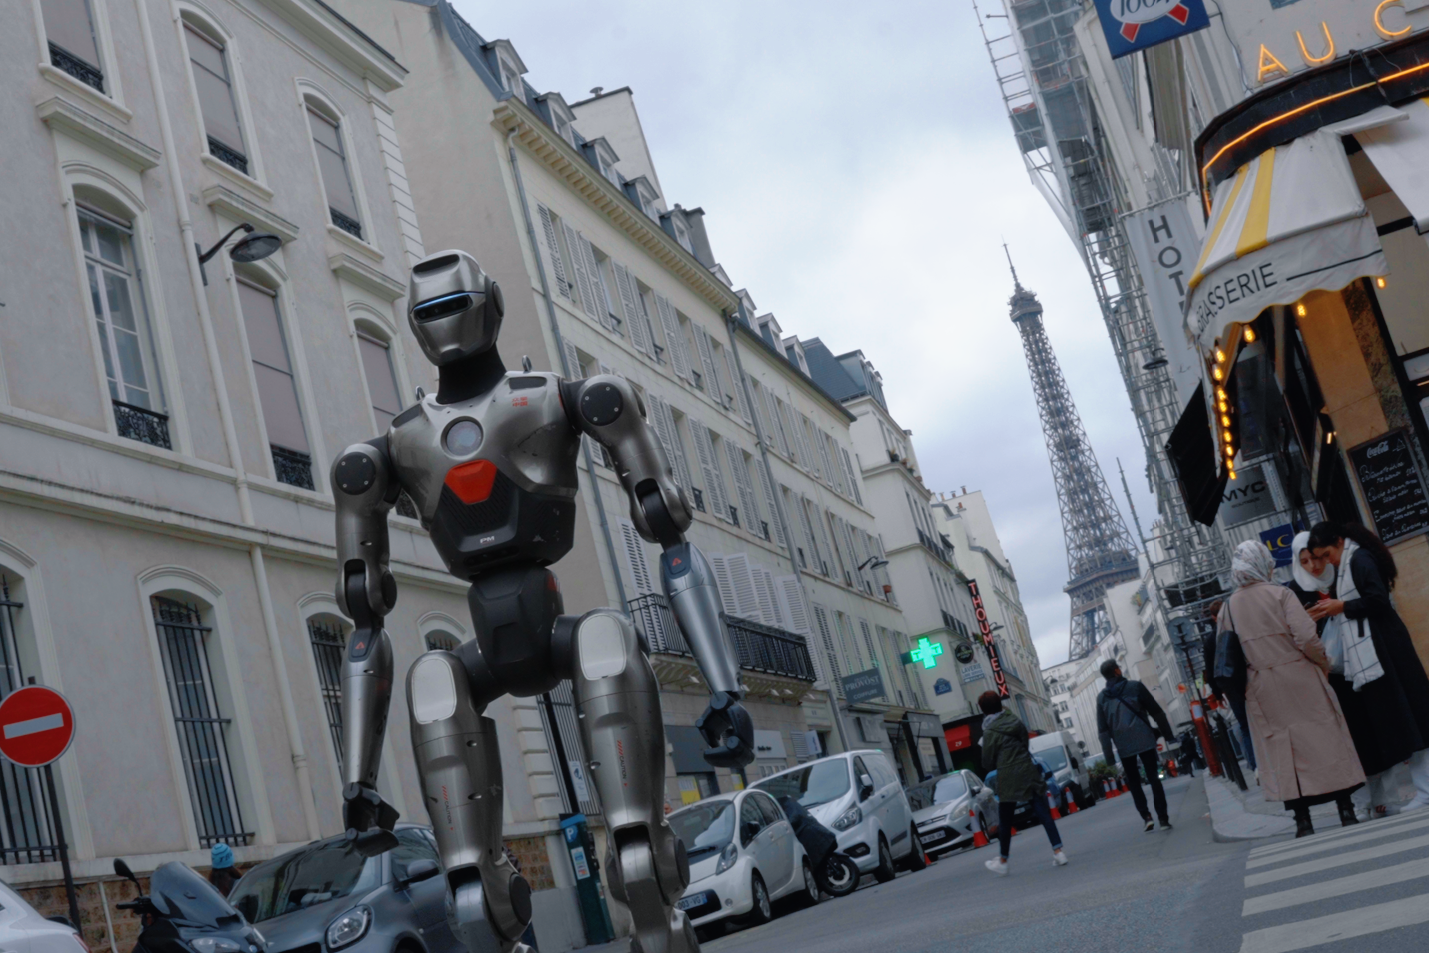
ENGINEAI's Most Agile Embodied Agent to Date
Thanks to exceptional body movement control algorithms and fully self-developed joint actuators, every motion can be executed with precision and stability.
 Play video
Greater Flexibility, Greater Freedom
Superlative agility, enabled by an ultra-wide range of motion and a total body freedom of ≥23 DOF


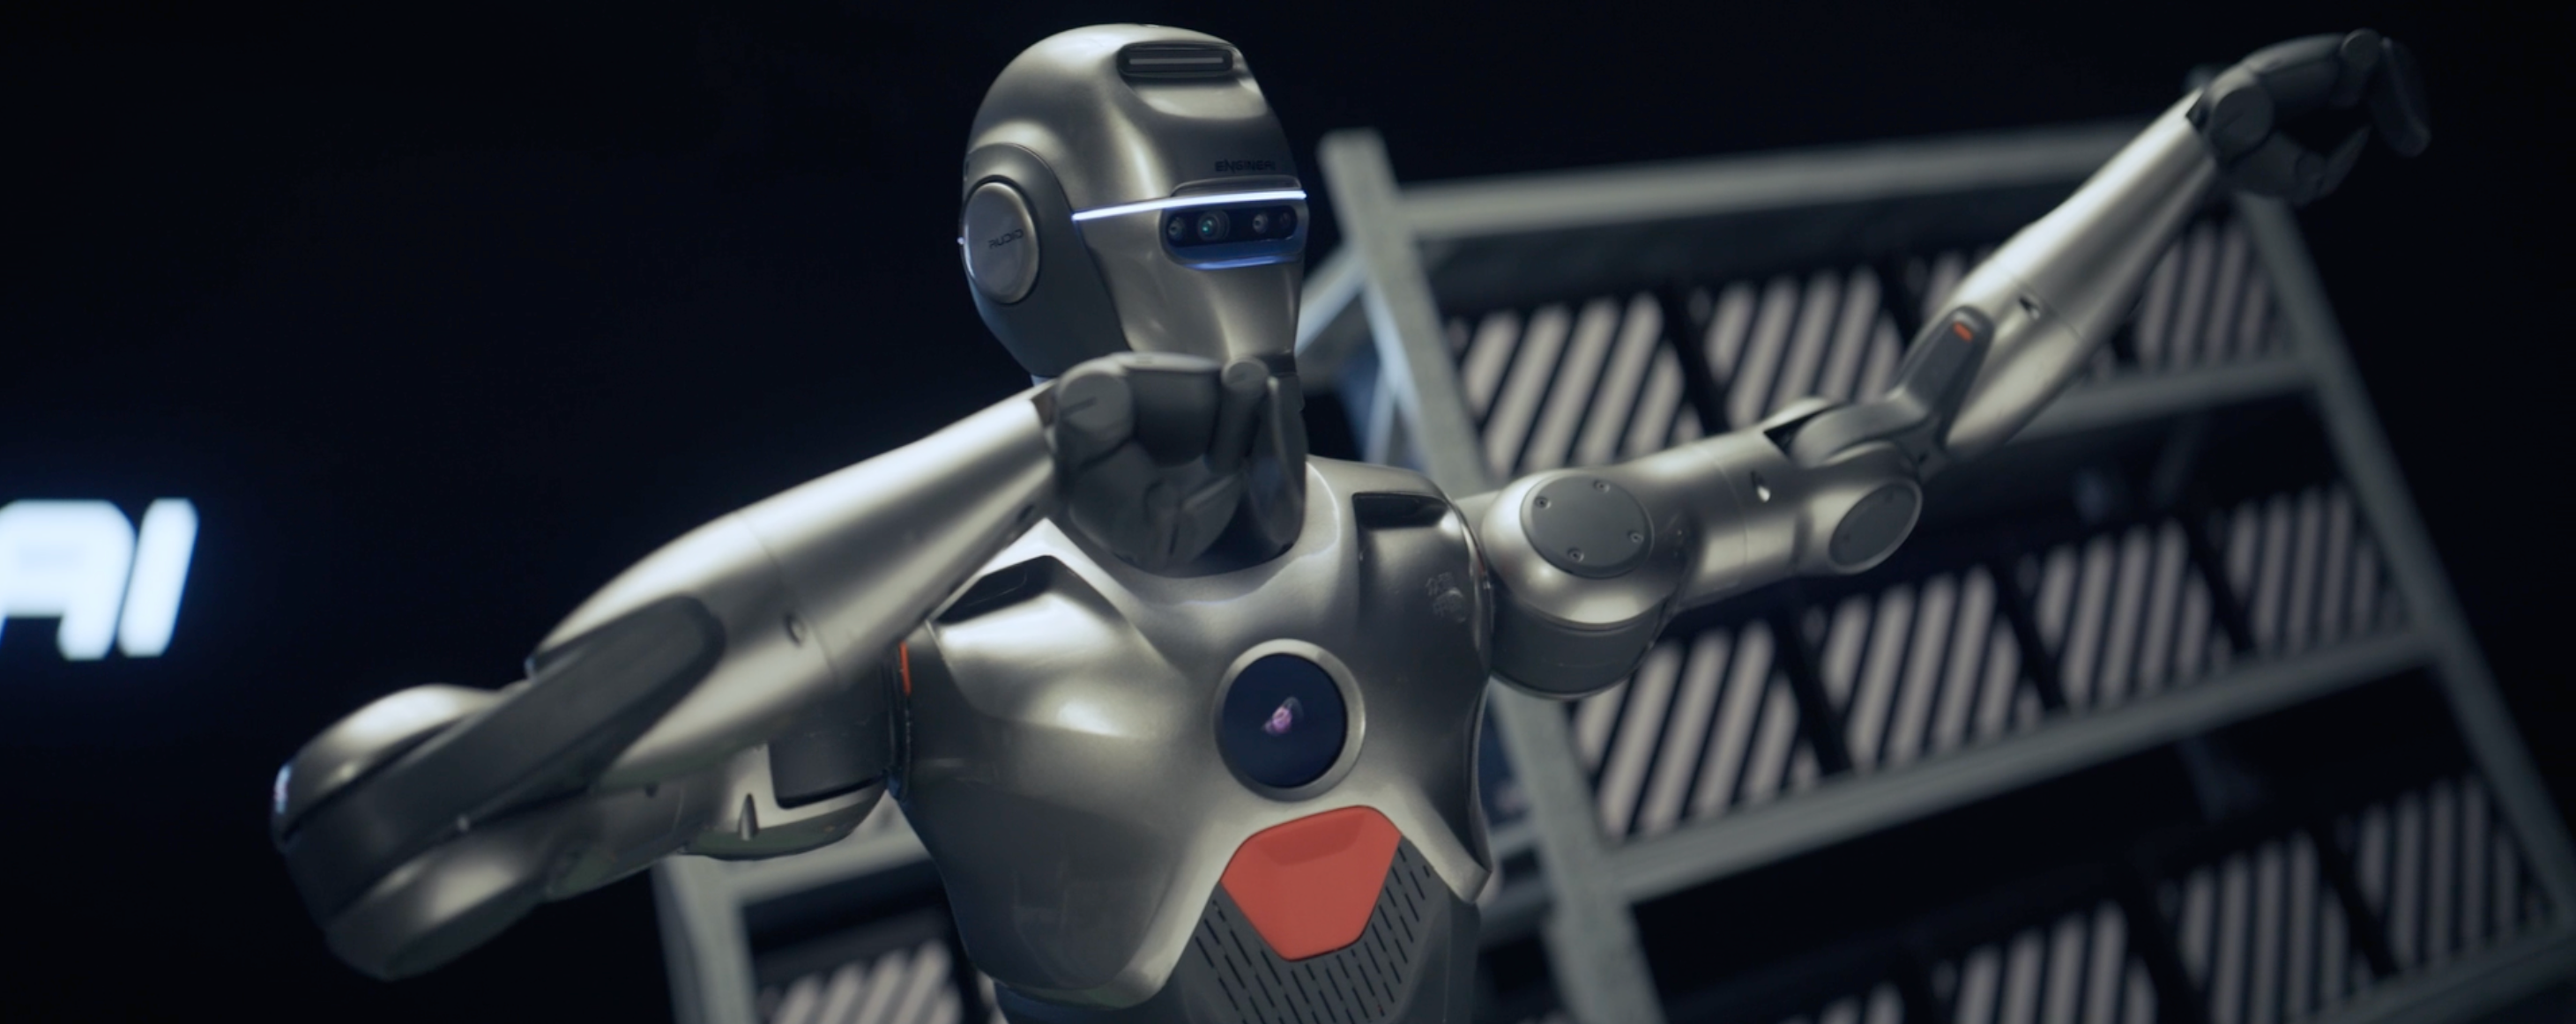


DOF of a Single Arm
5
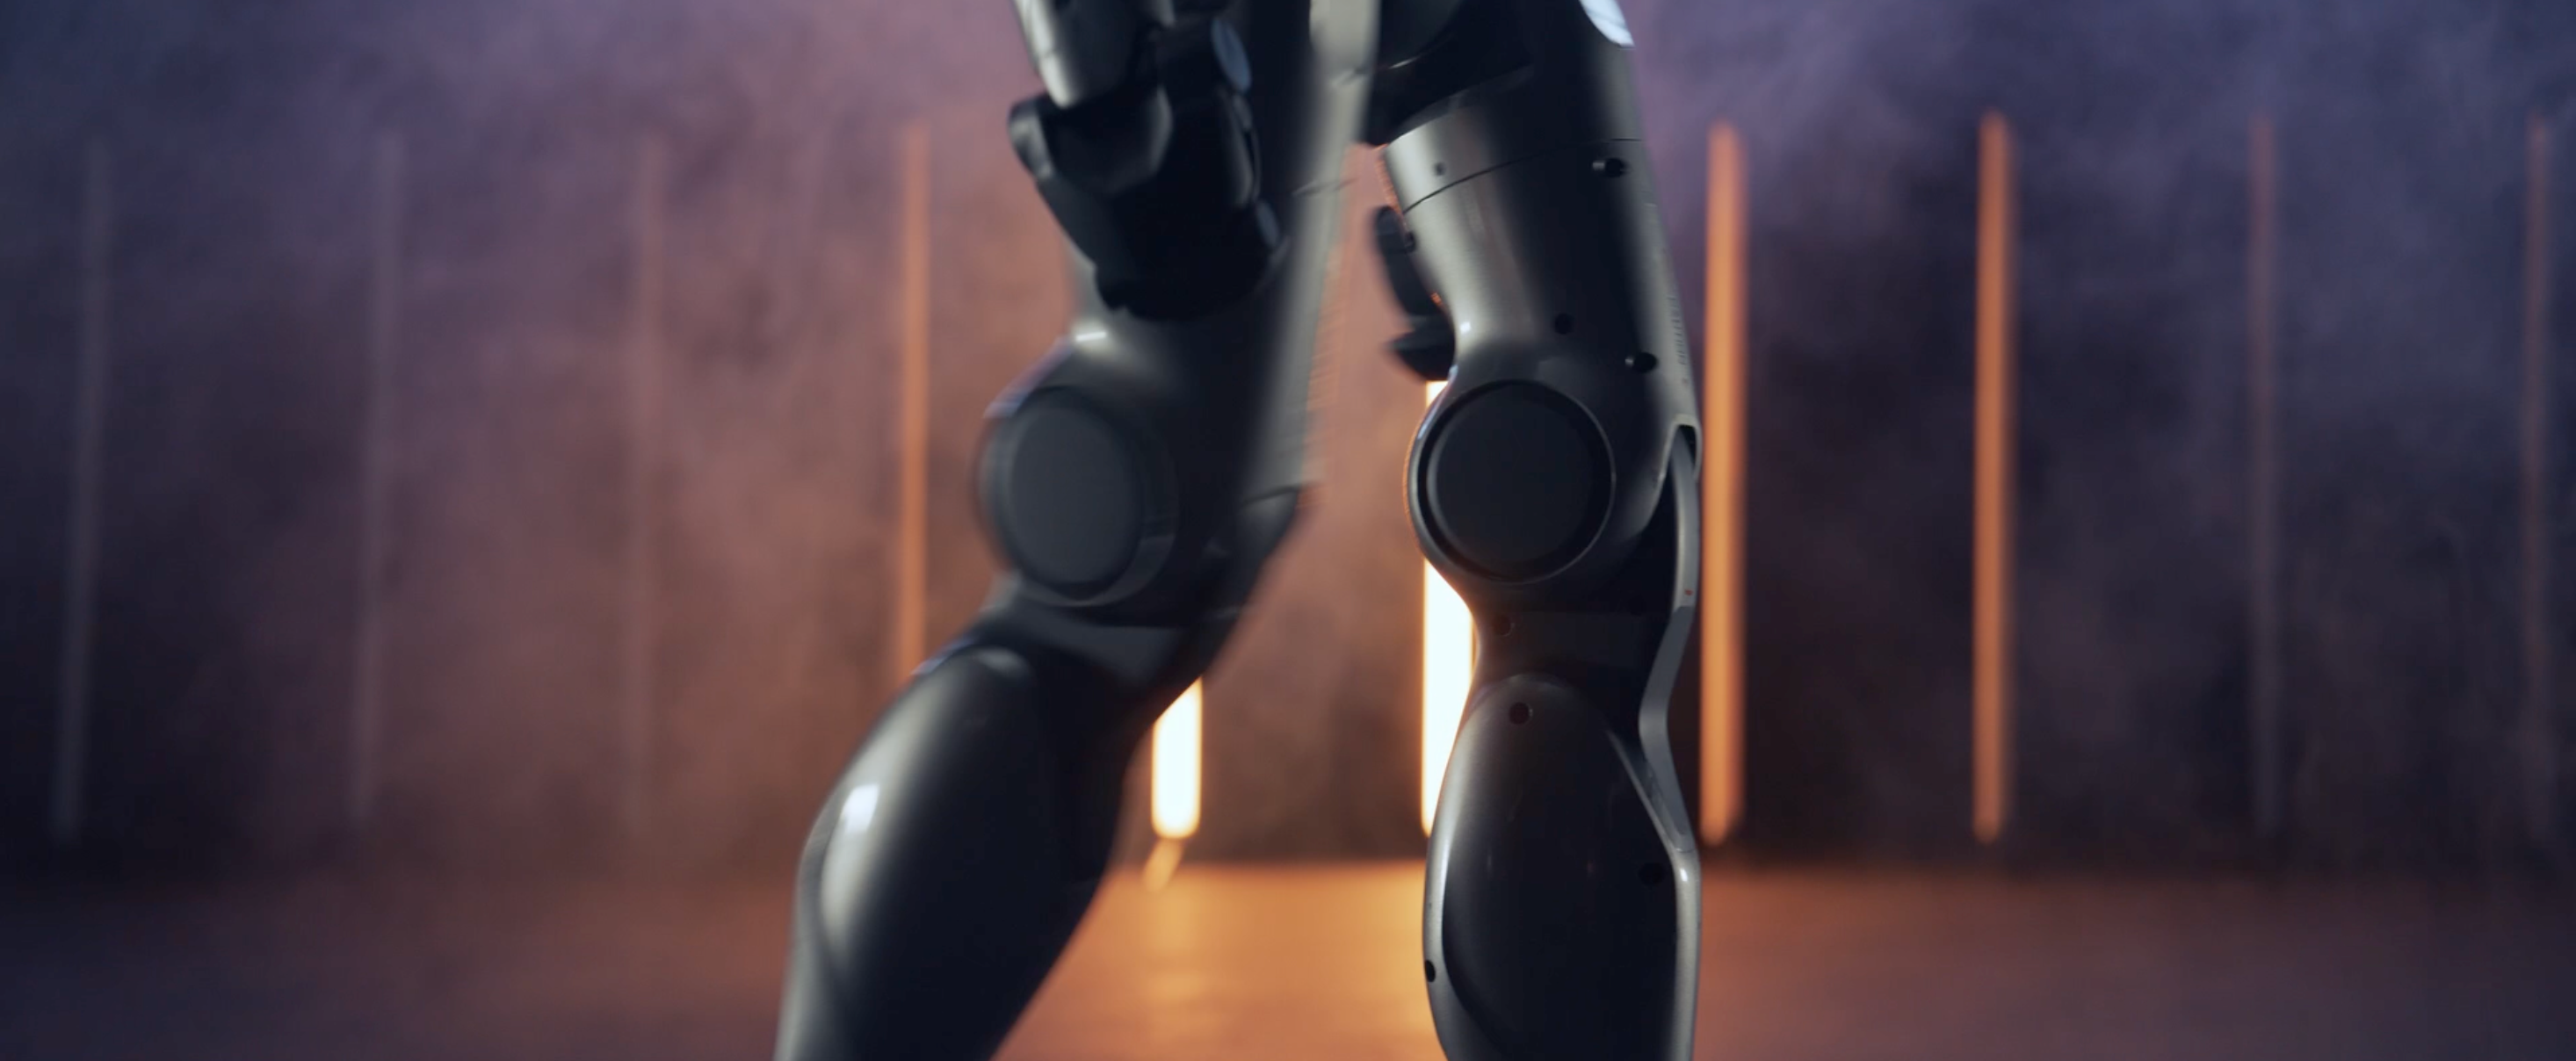
Leg DOF
6
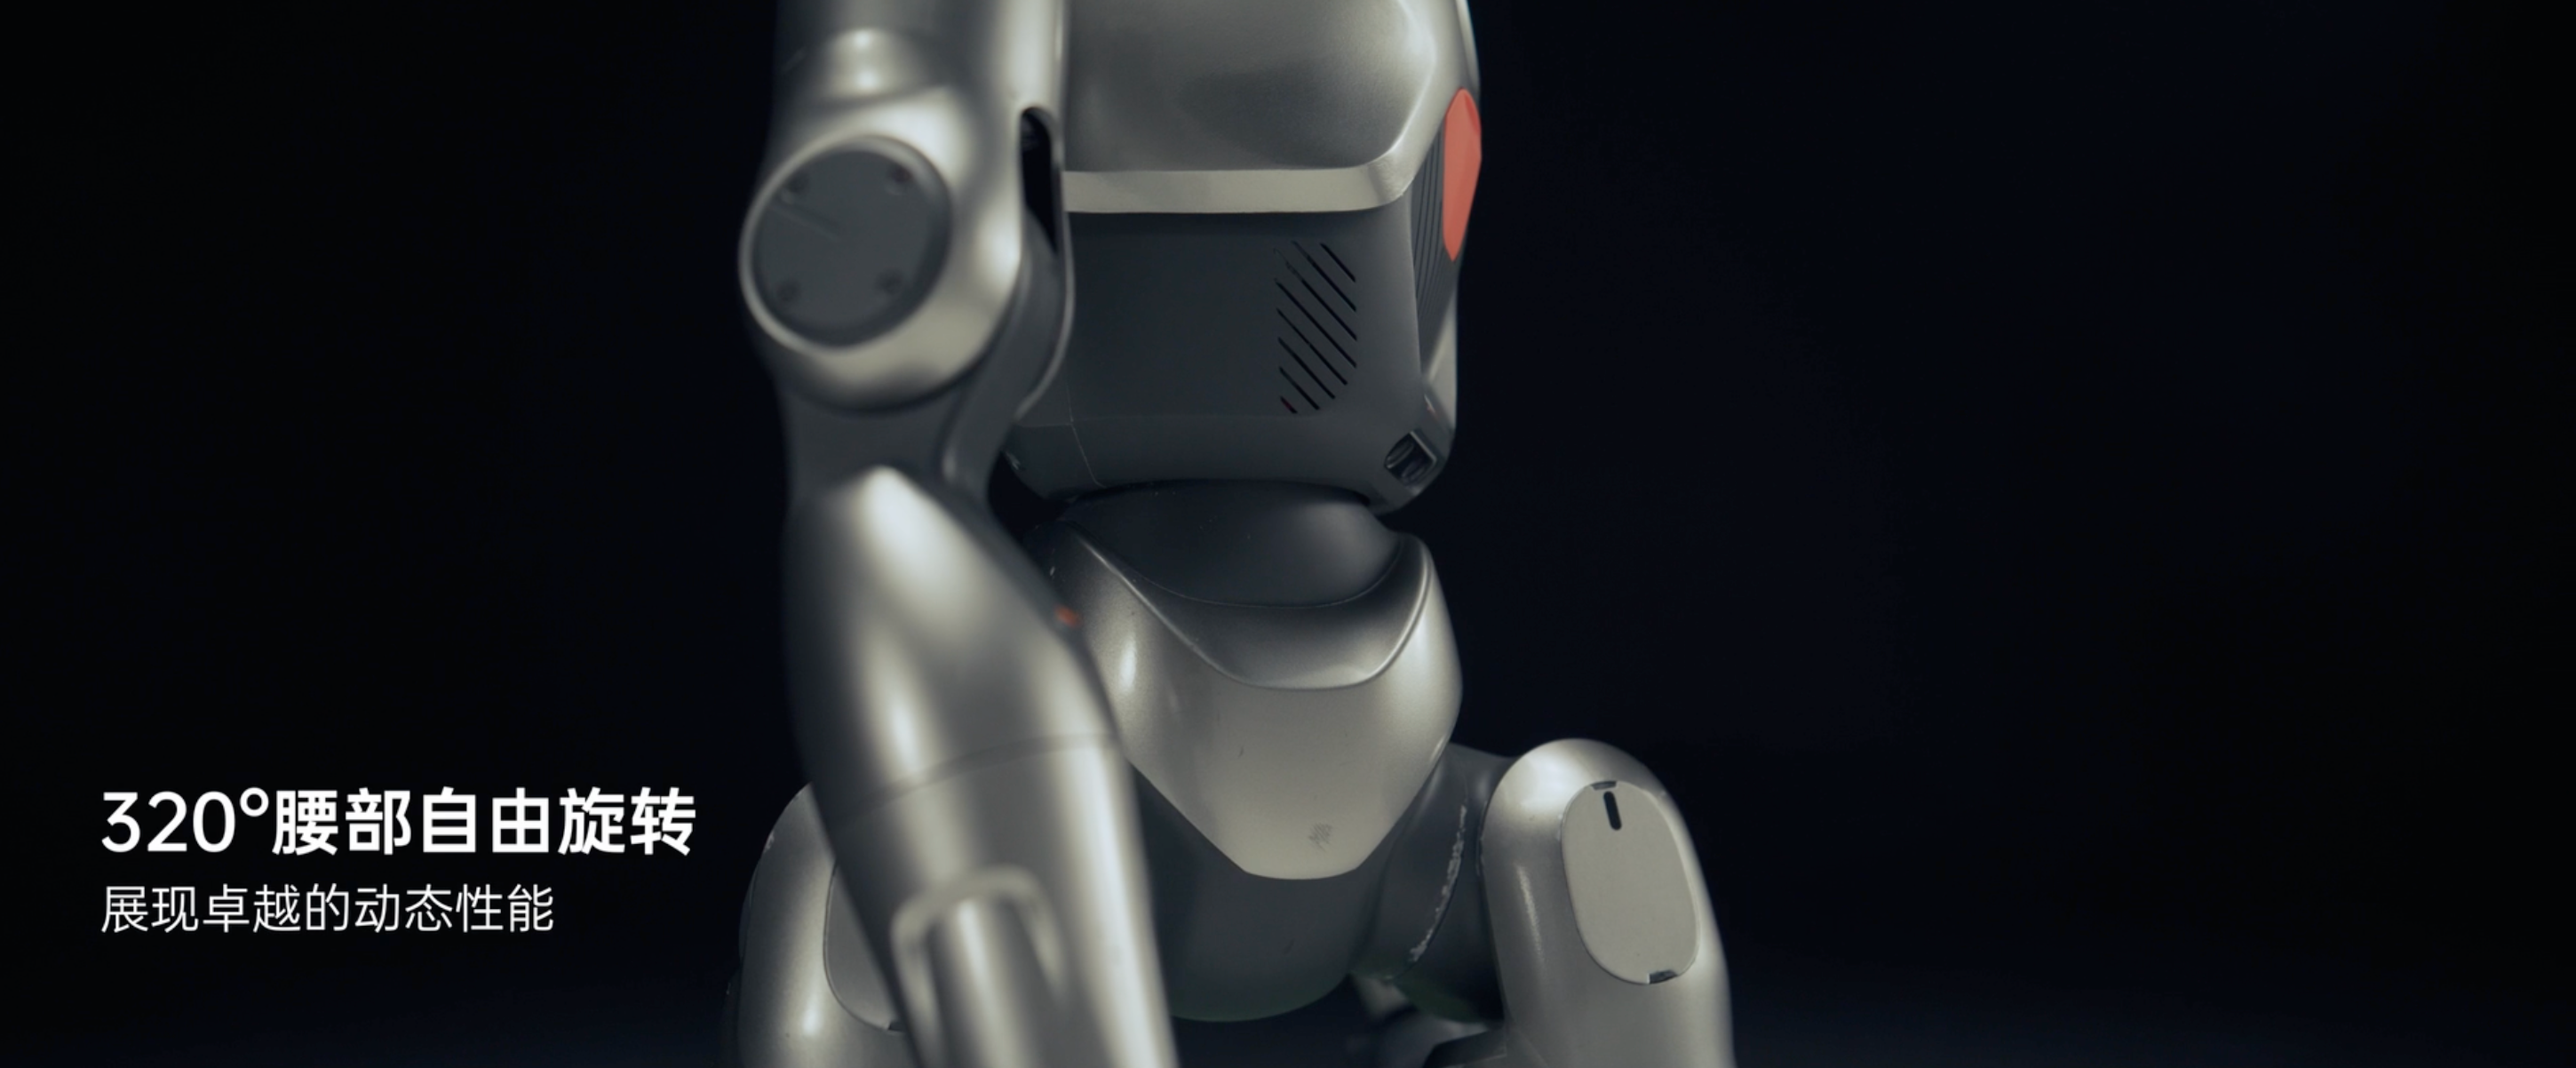
Waist Rotation Angle
>300 °
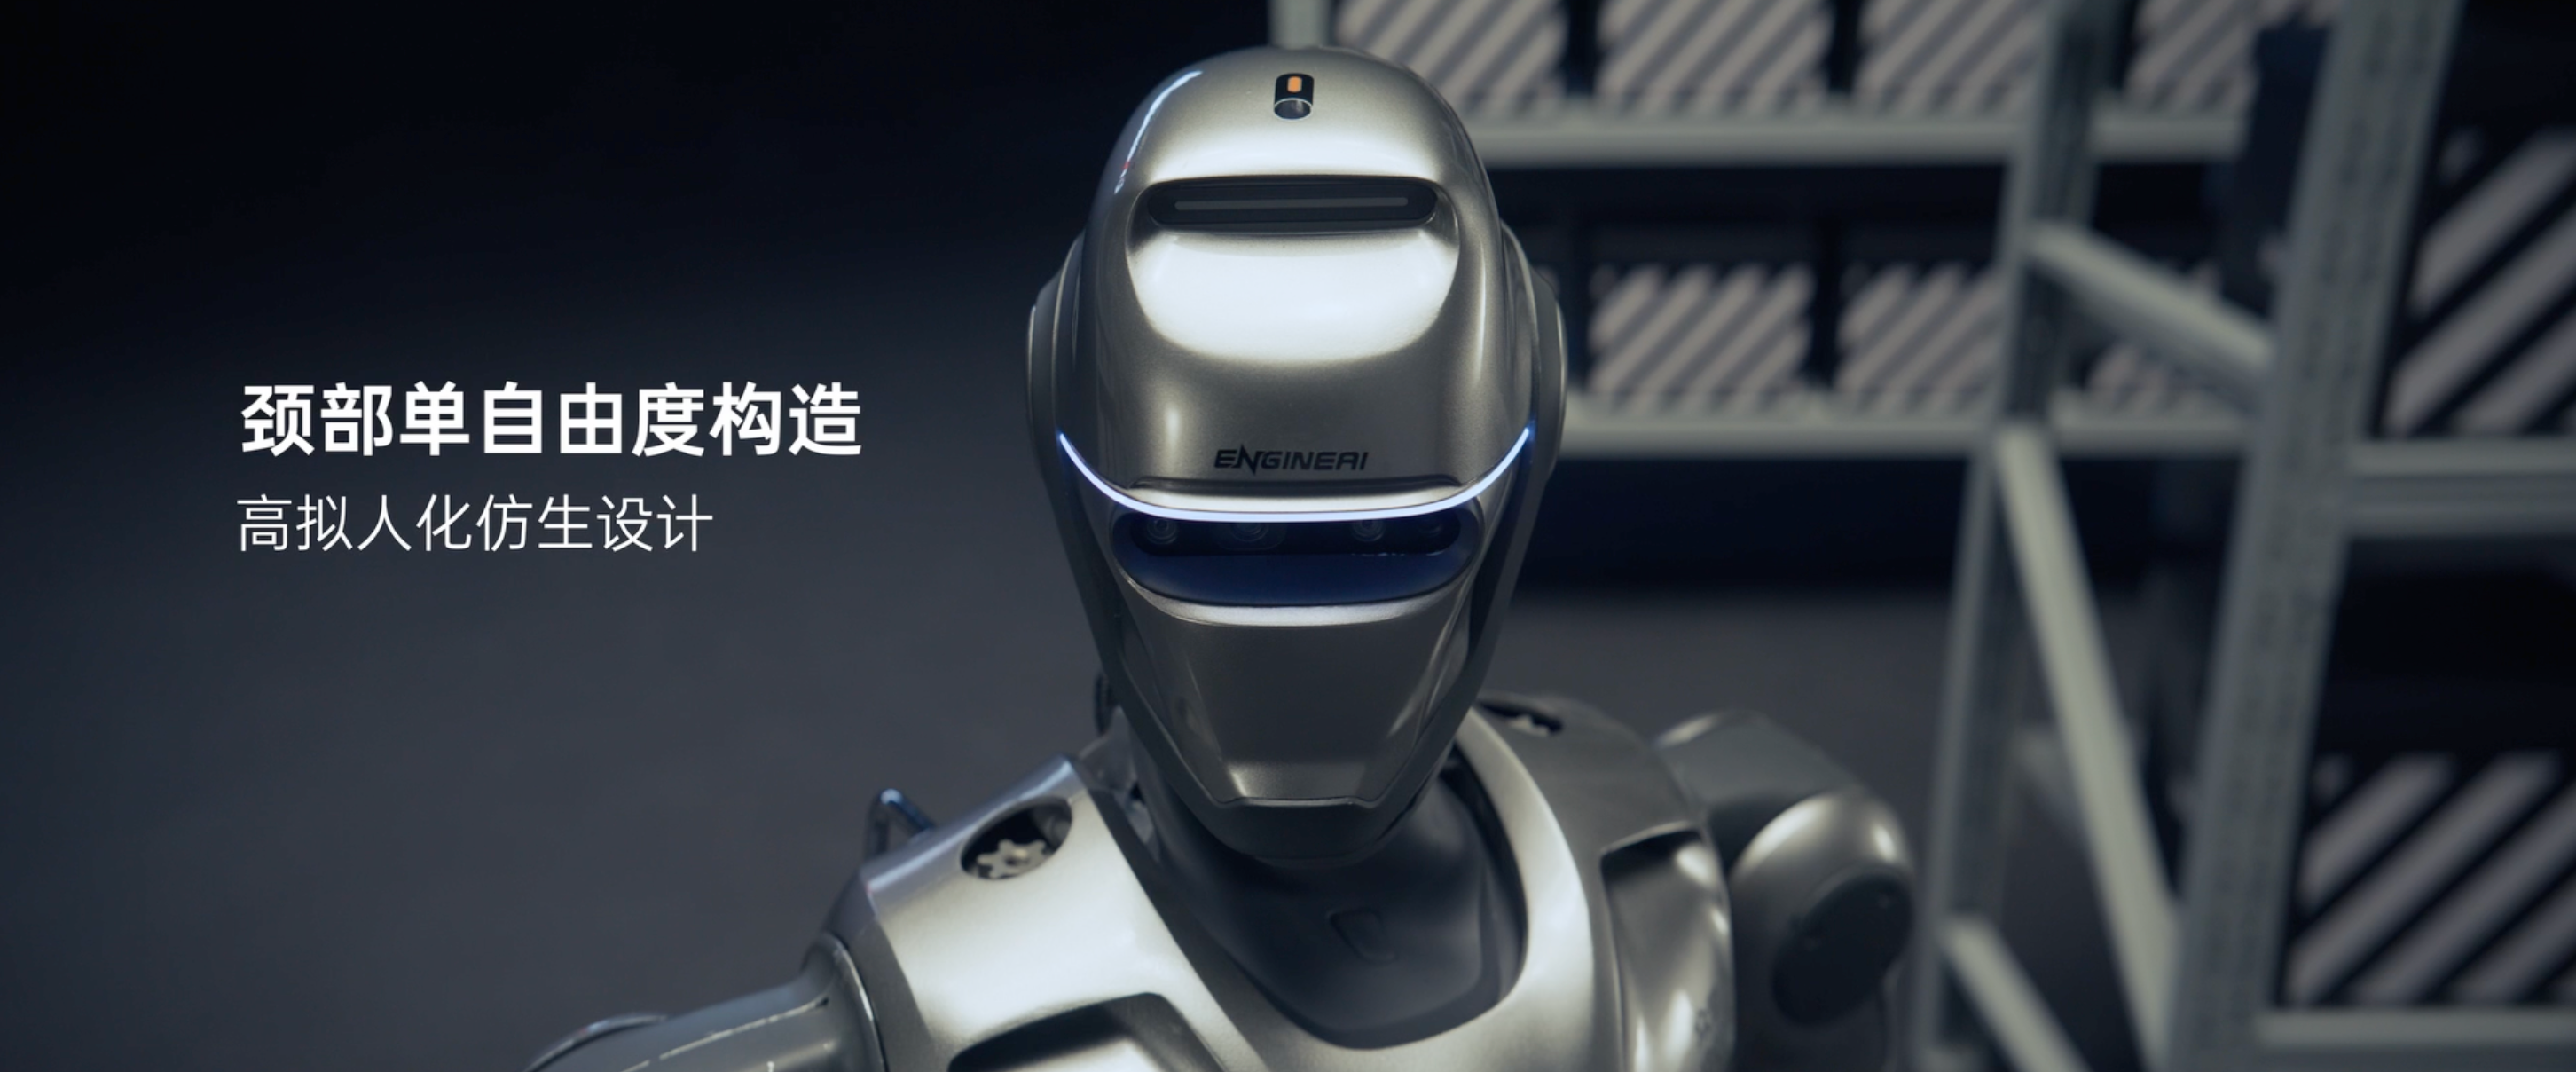
Head DOF
Personified Interactive Experience
5
6
>300 °
Personified Interactive Experience
PM01 High-Mobility Performance
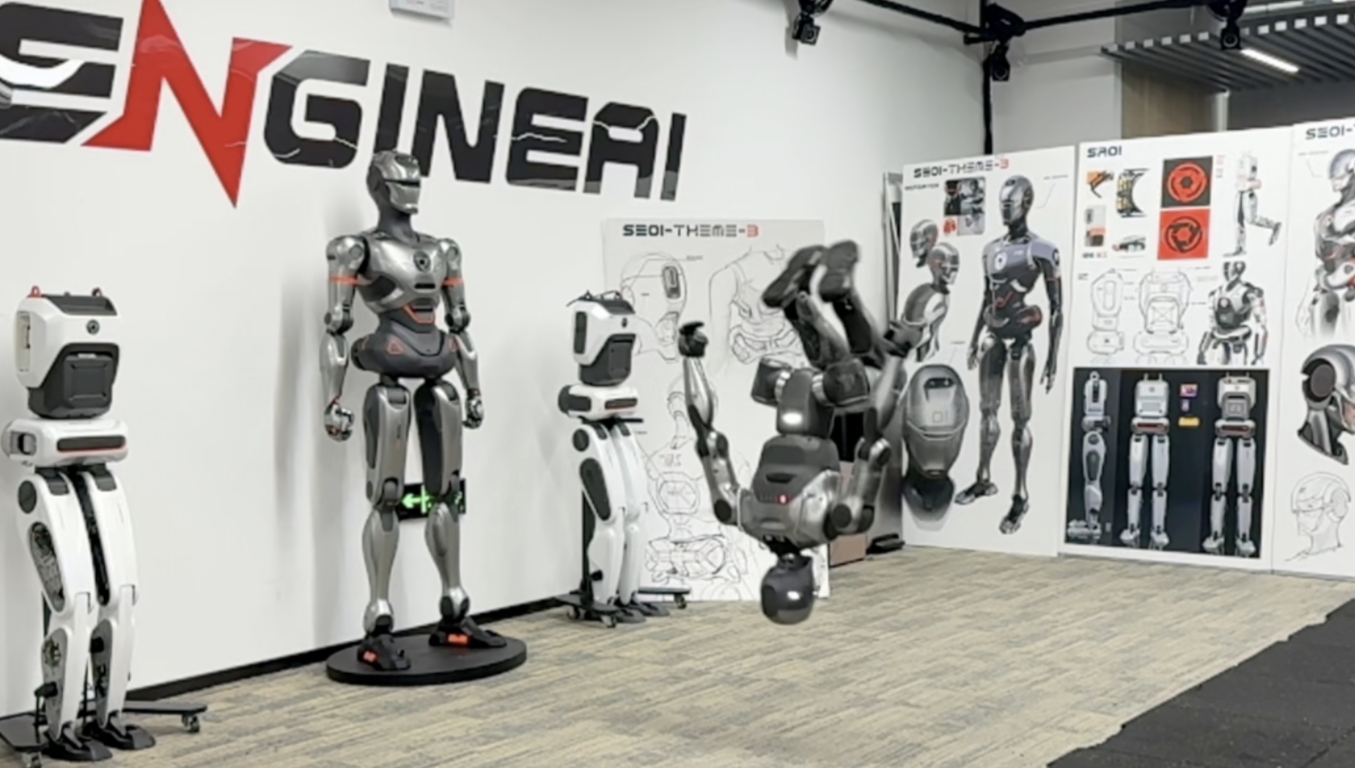
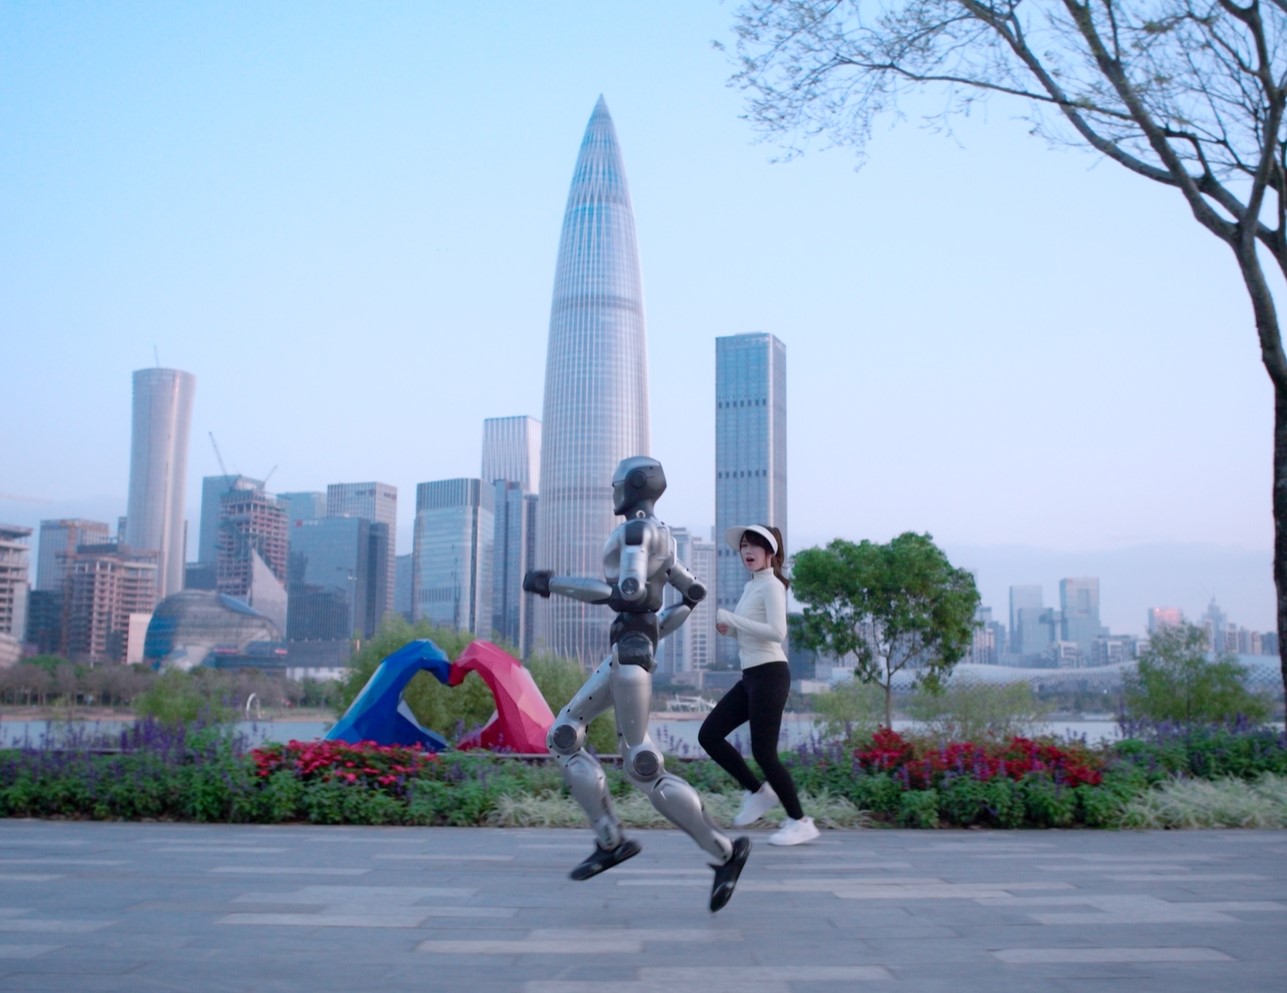
Excellence, in Every Move
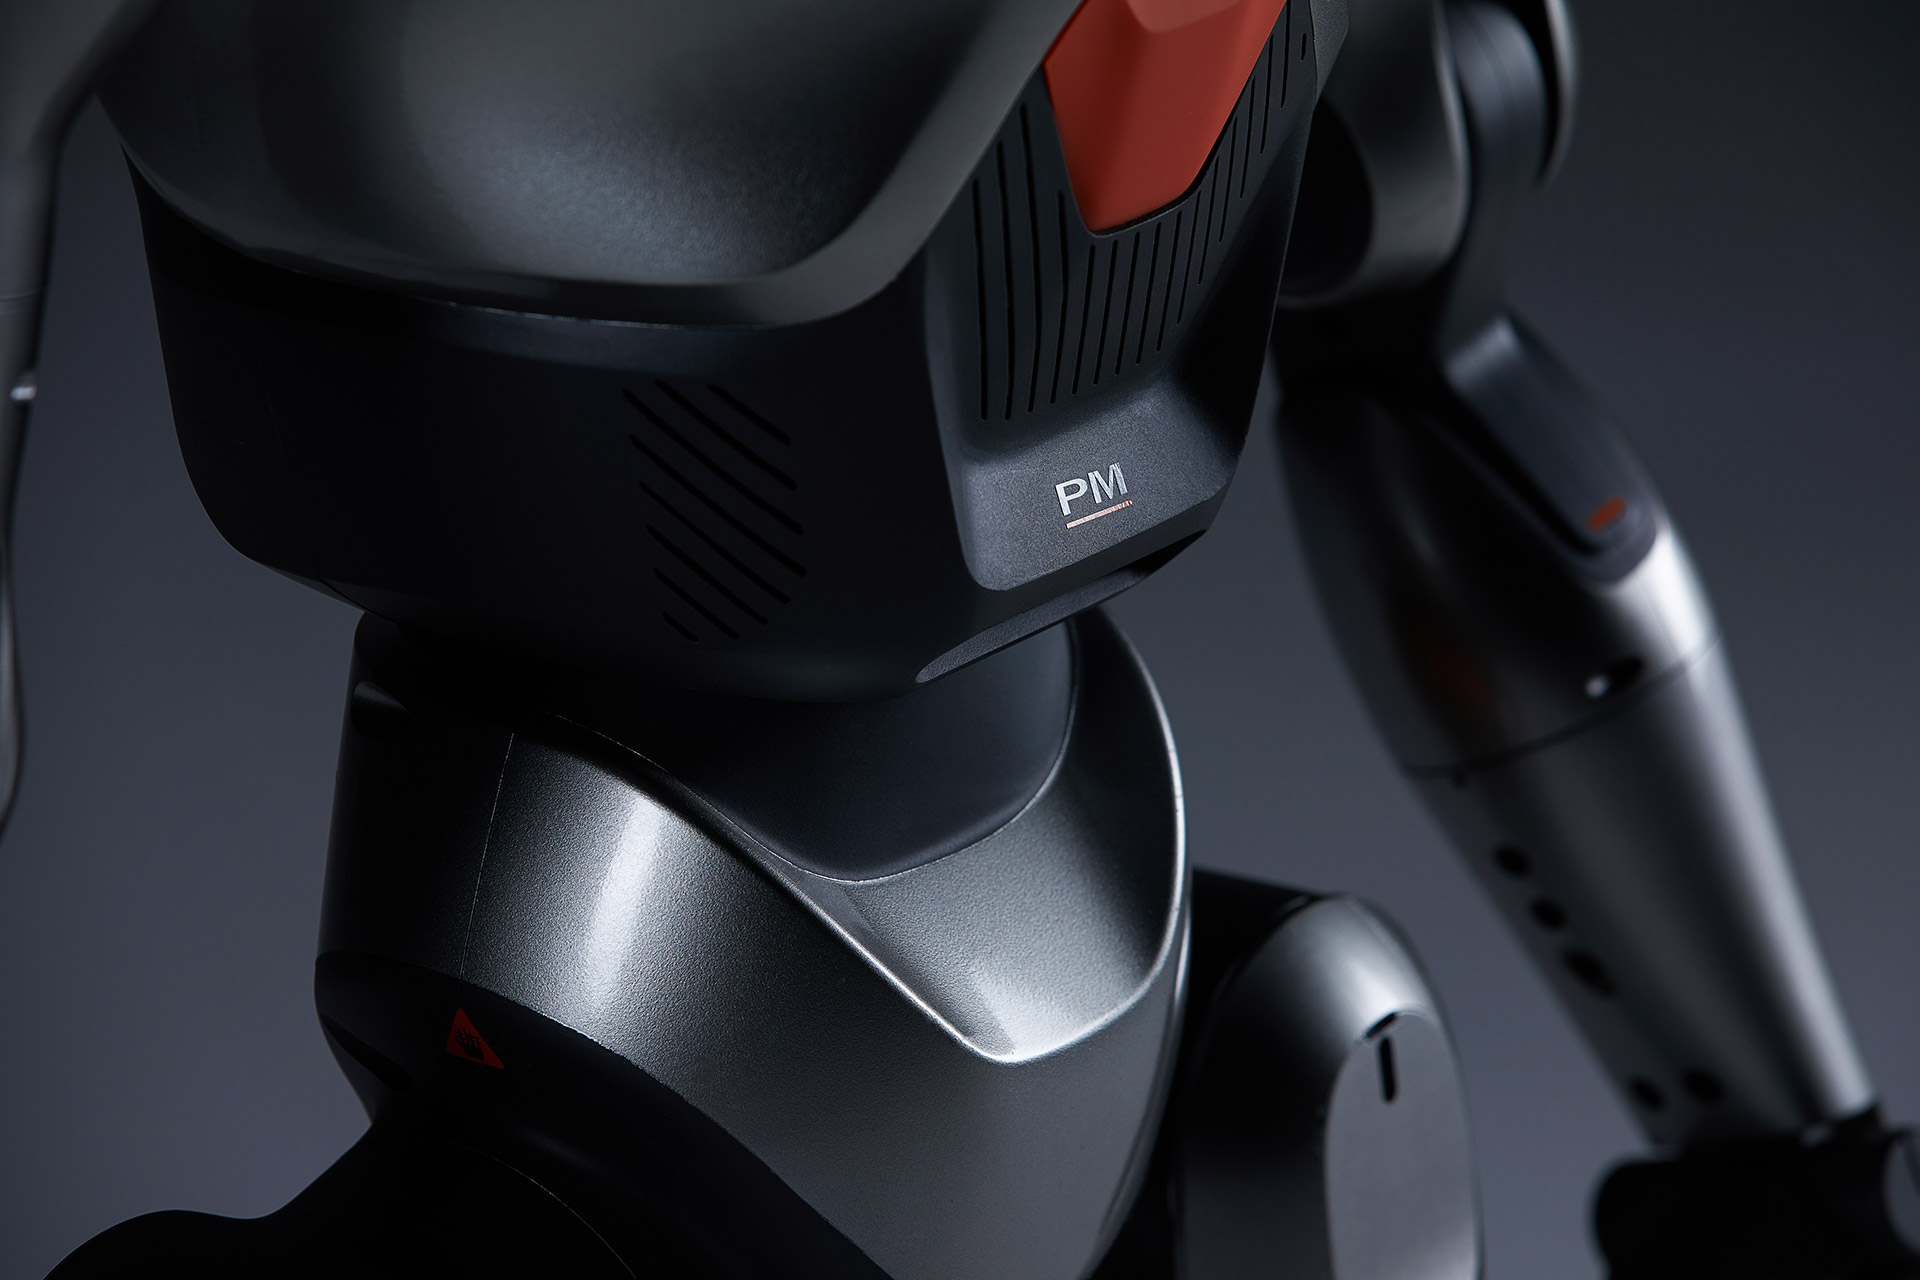
The Ultimate Mechanical Aesthetics01
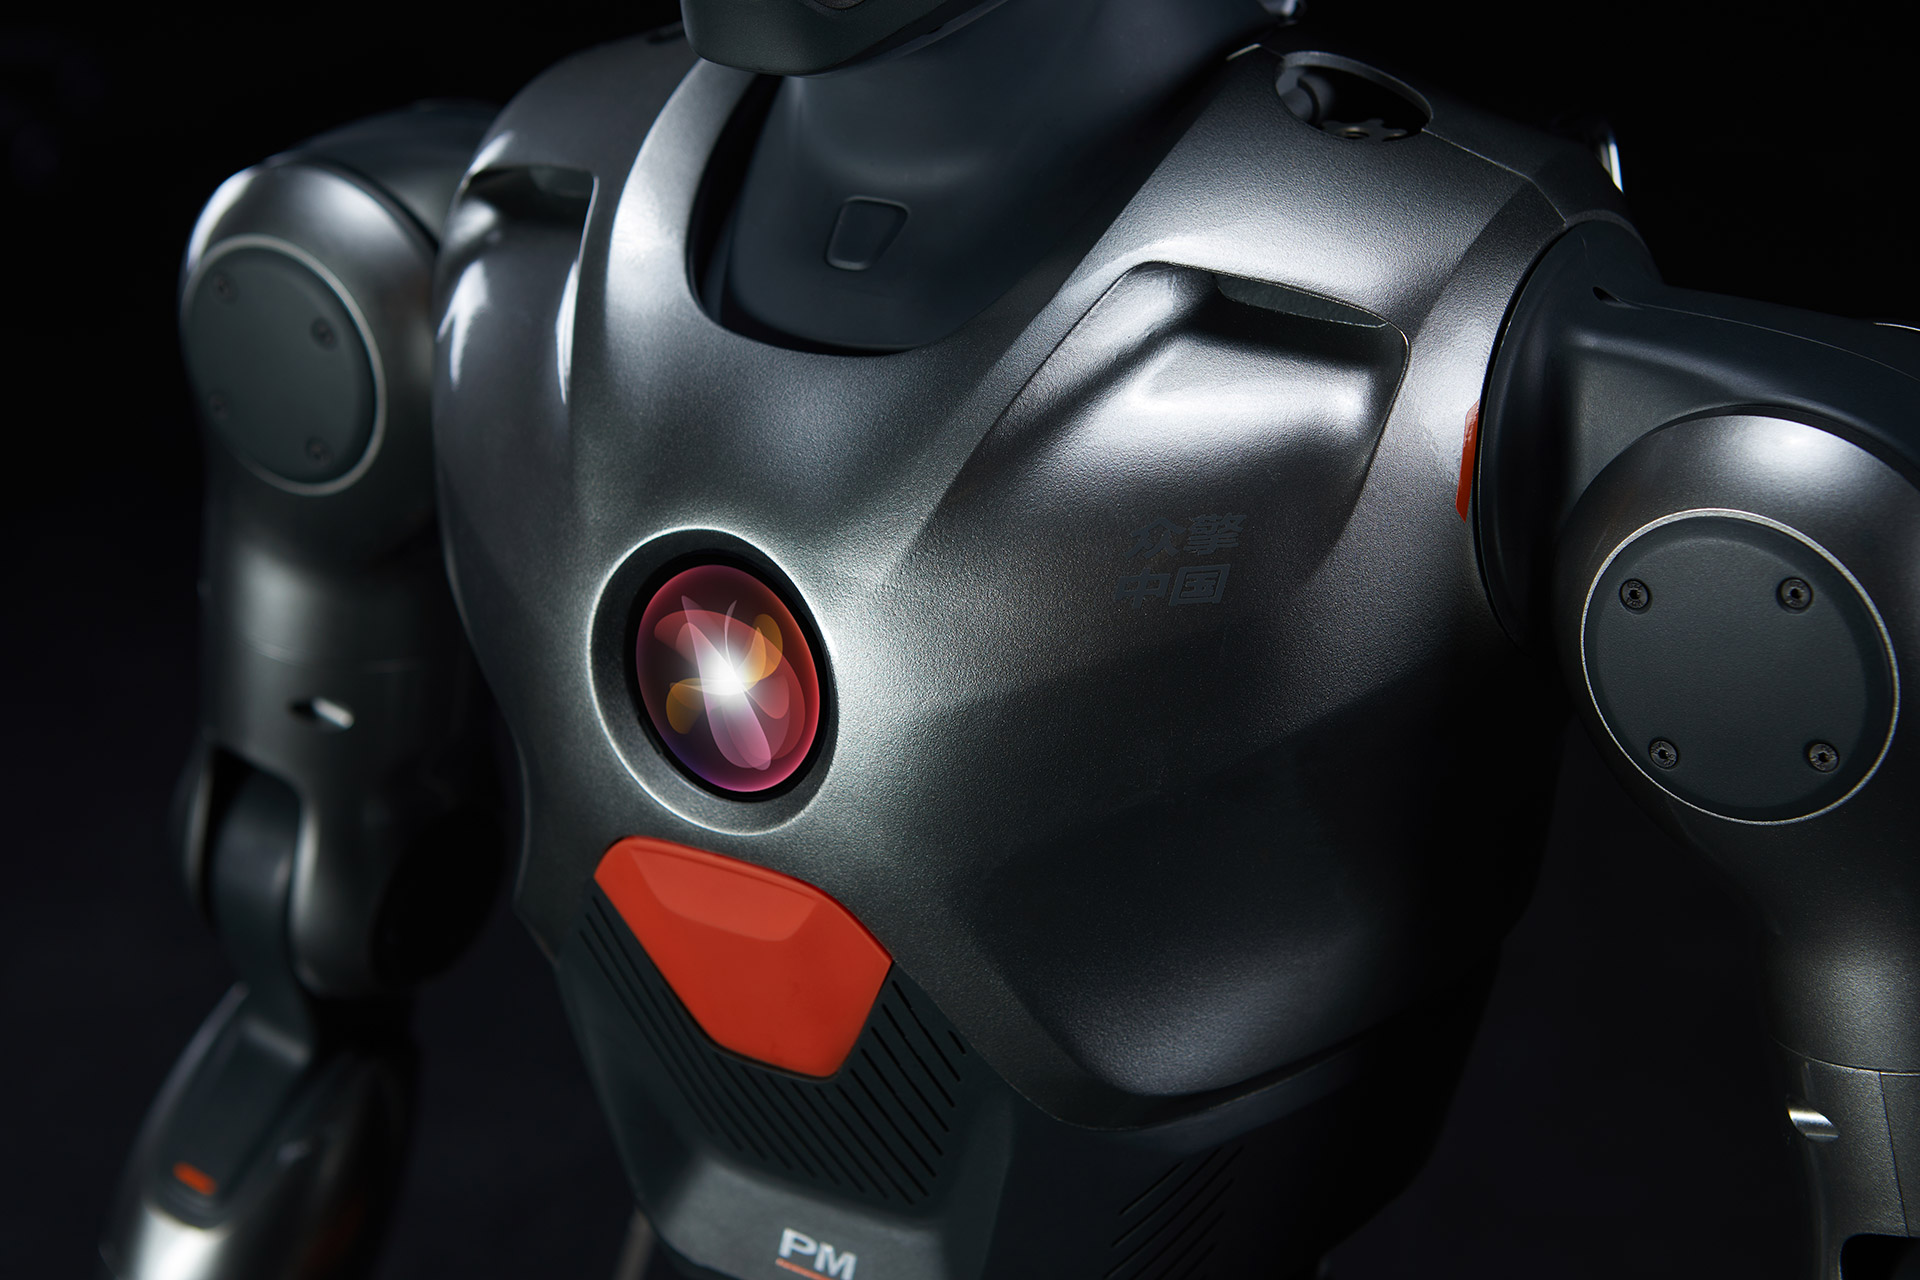
Smart Interactive Core Hub02
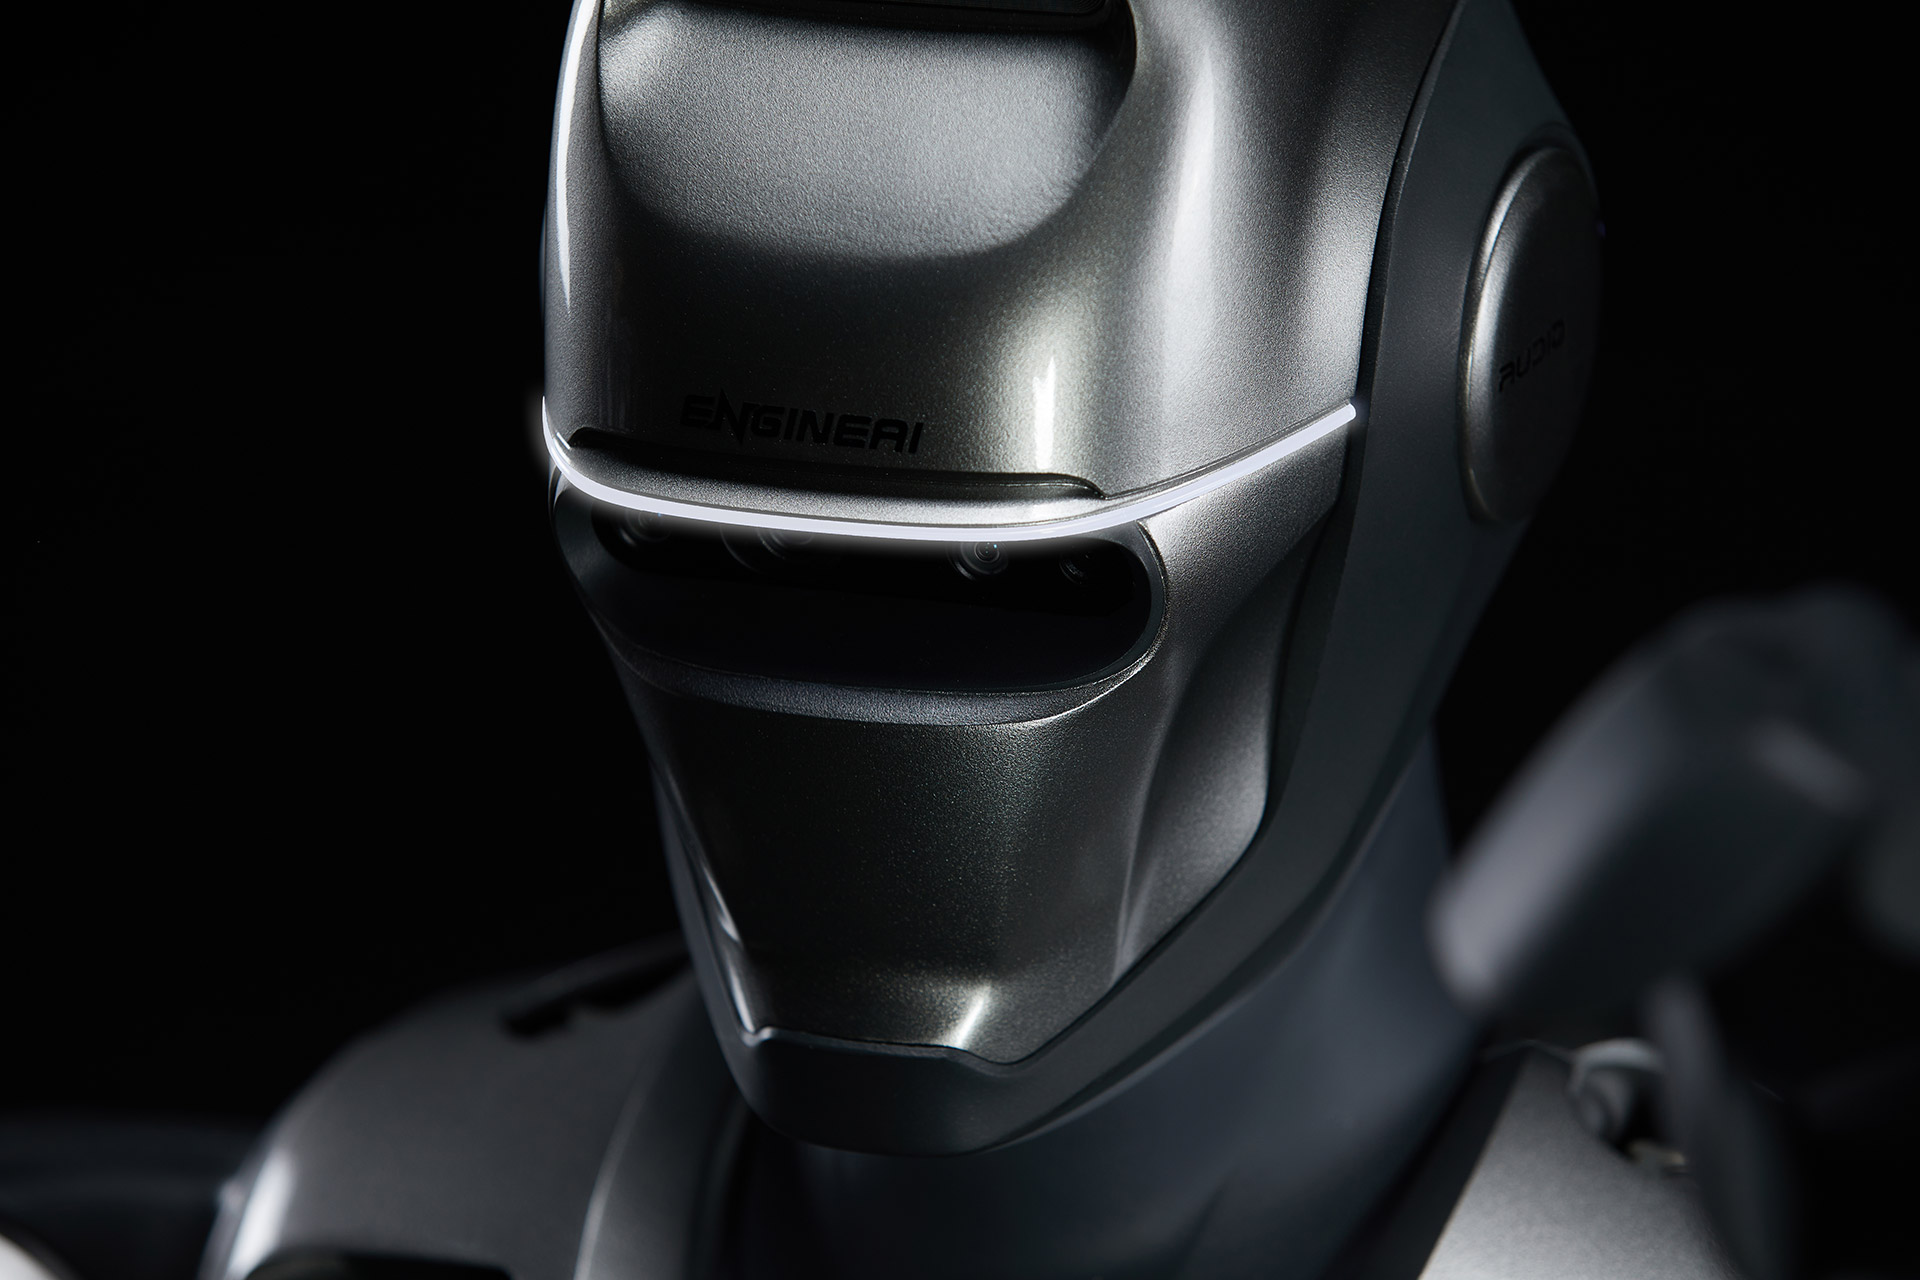
Family-Design Star Ring Light03

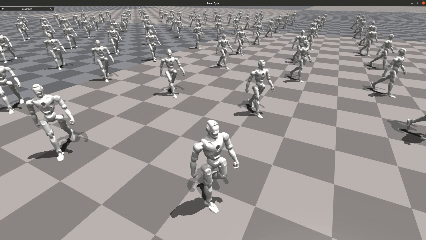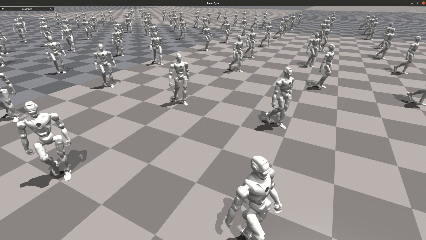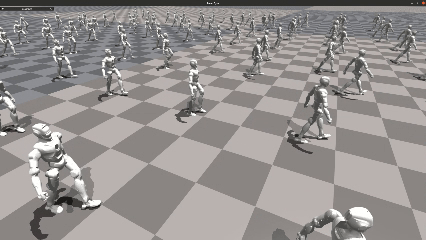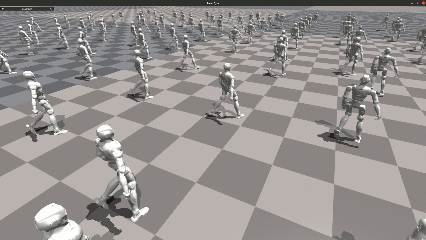
Learning in Simulation, Evolving Continuously
This end-to-end neural network, trained on optical motion capture data and adversarial learning, rapidly evolves in simulation. It adapts to complex terrains and scenarios, quickly mastering optimal strategies.
Join the Ecosystem, Co-create the Future of Robotics
-

Training Code Repository: Integrate cutting-edge algorithms such as reinforcement learning and deep learning to provide optimized, reusable frameworks, eliminating the need for repetitive ground-up development.
Open-Source Training Code

-
Deploy code repository: Achieve seamless transition from model to application, supporting efficient operation across diverse scenarios.
Open-Source Deployment Code
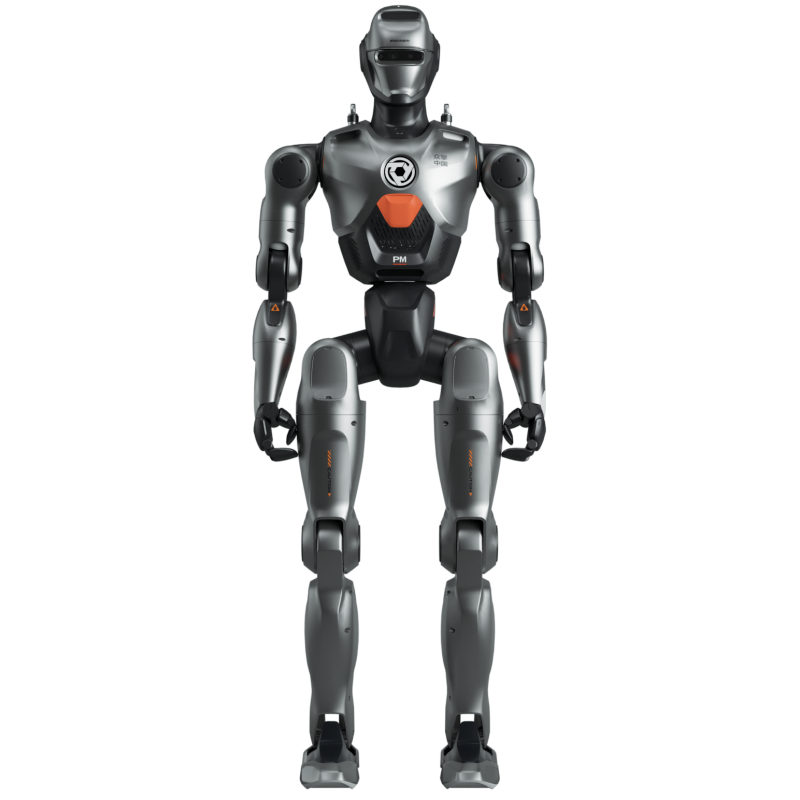

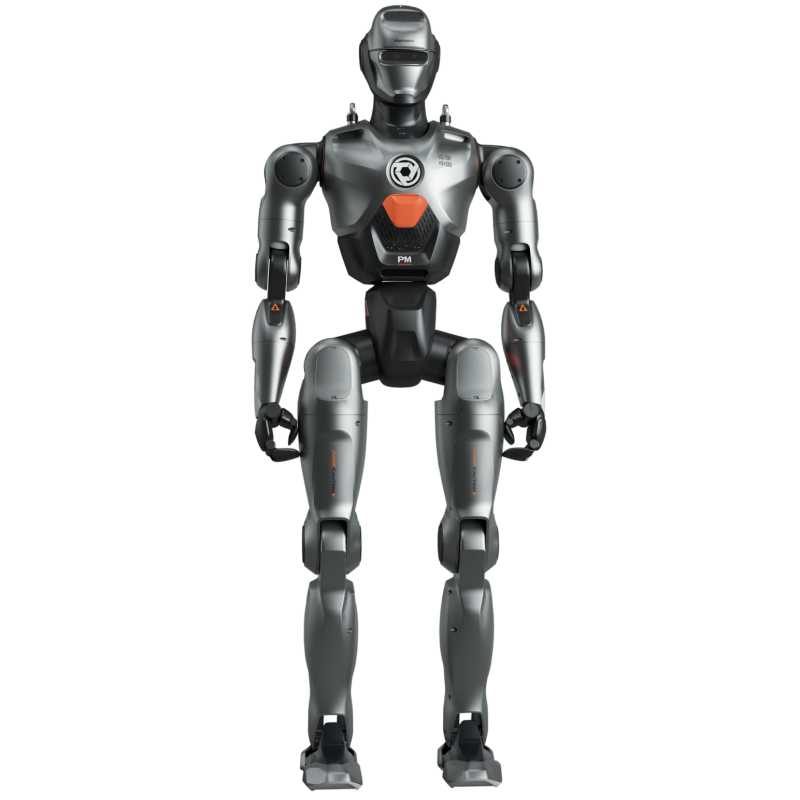
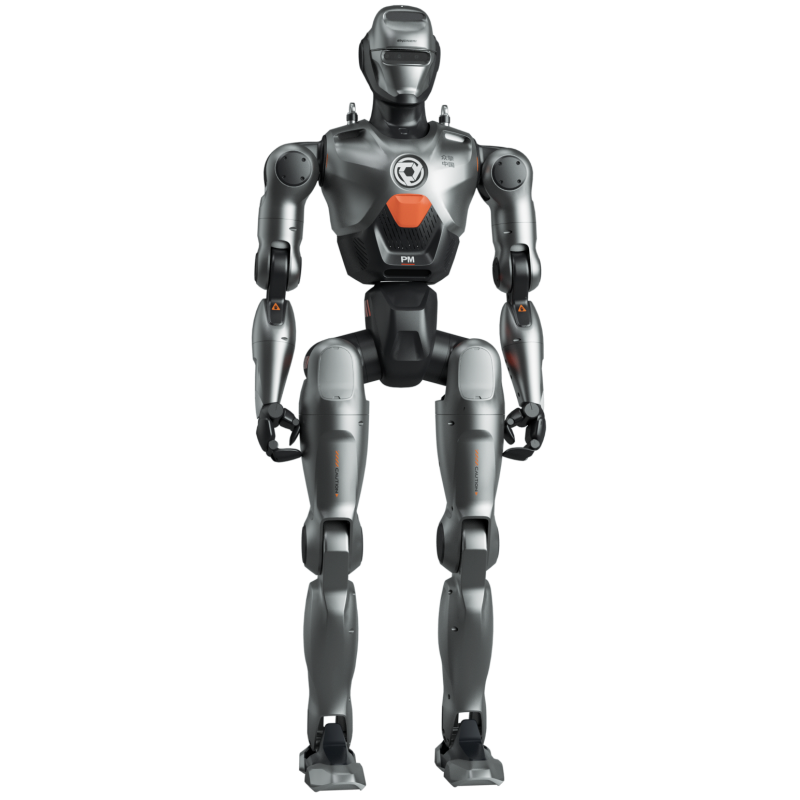
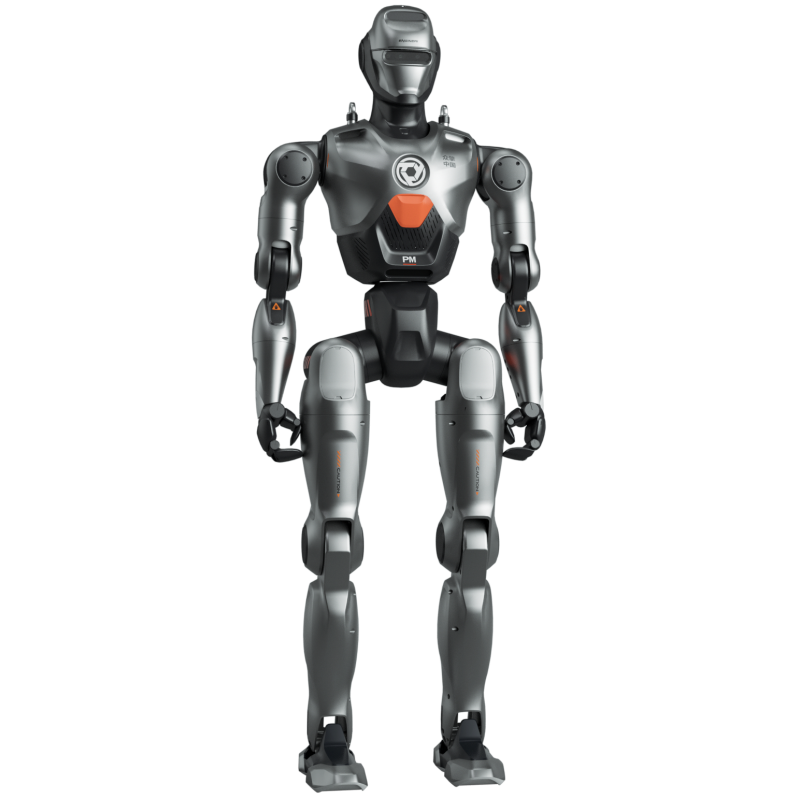
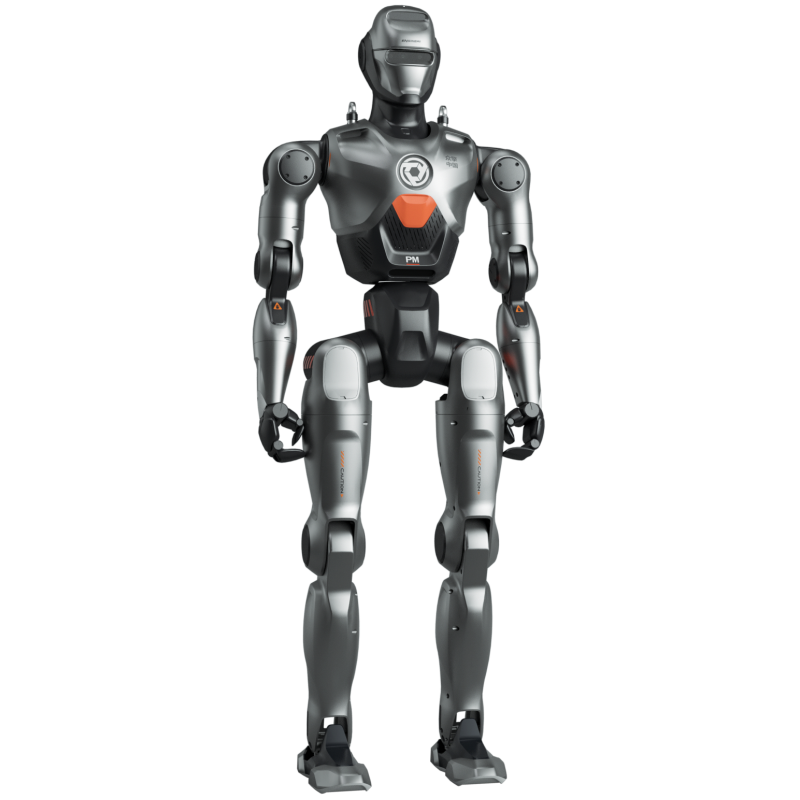

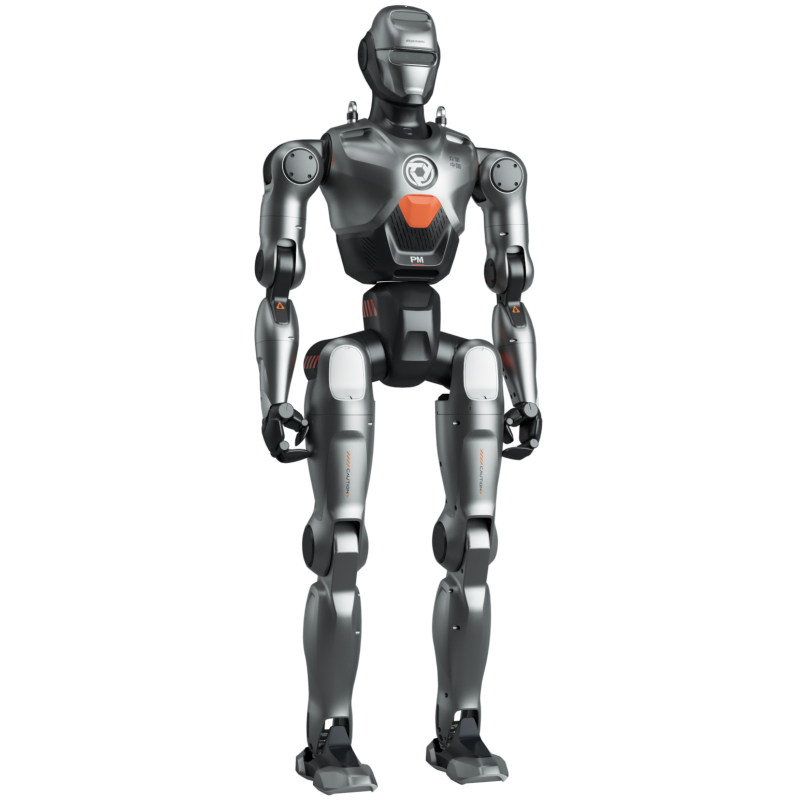


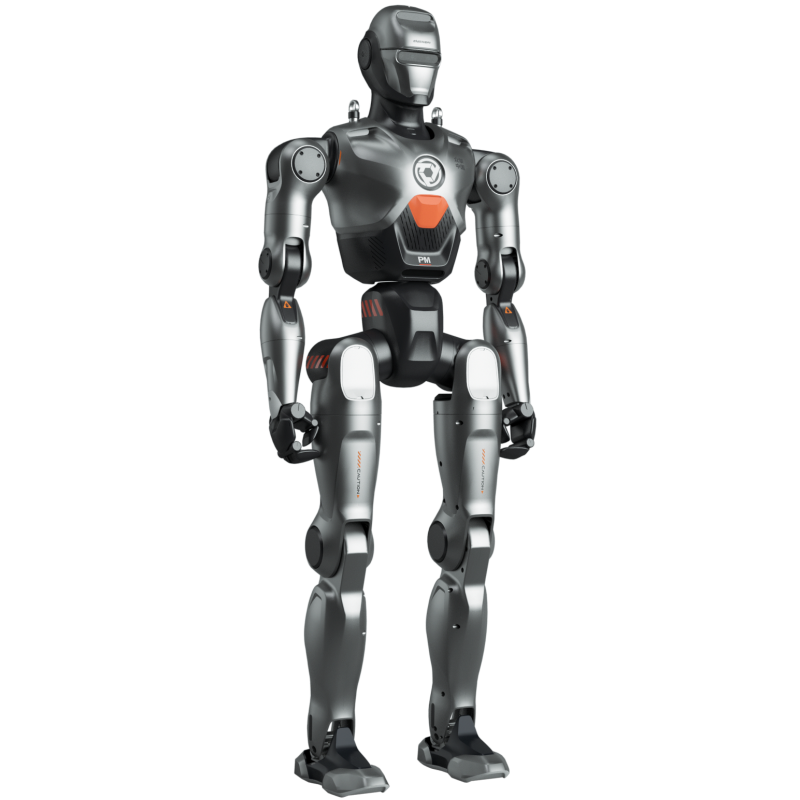

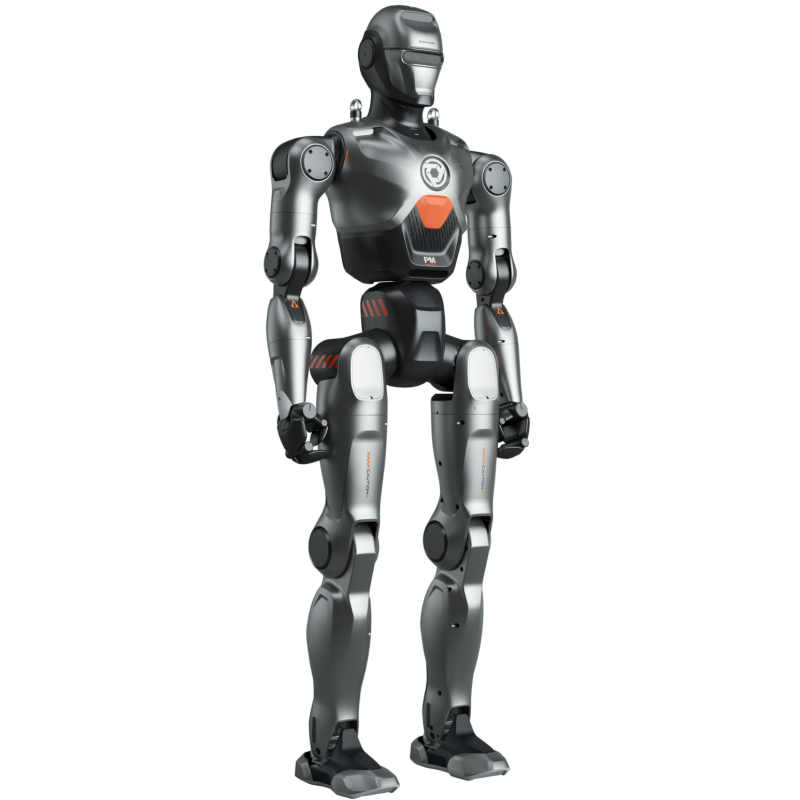
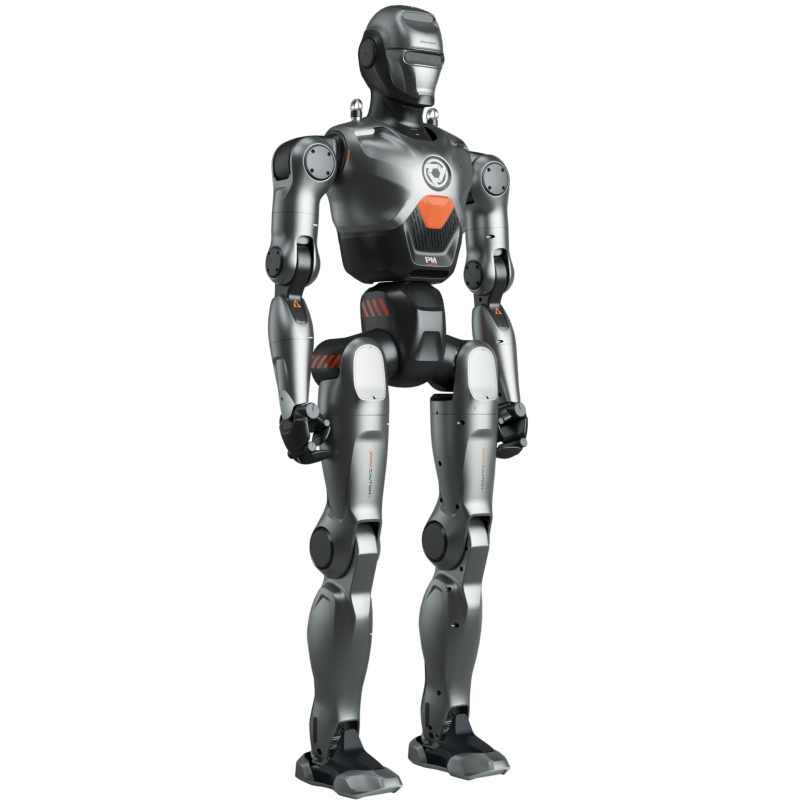
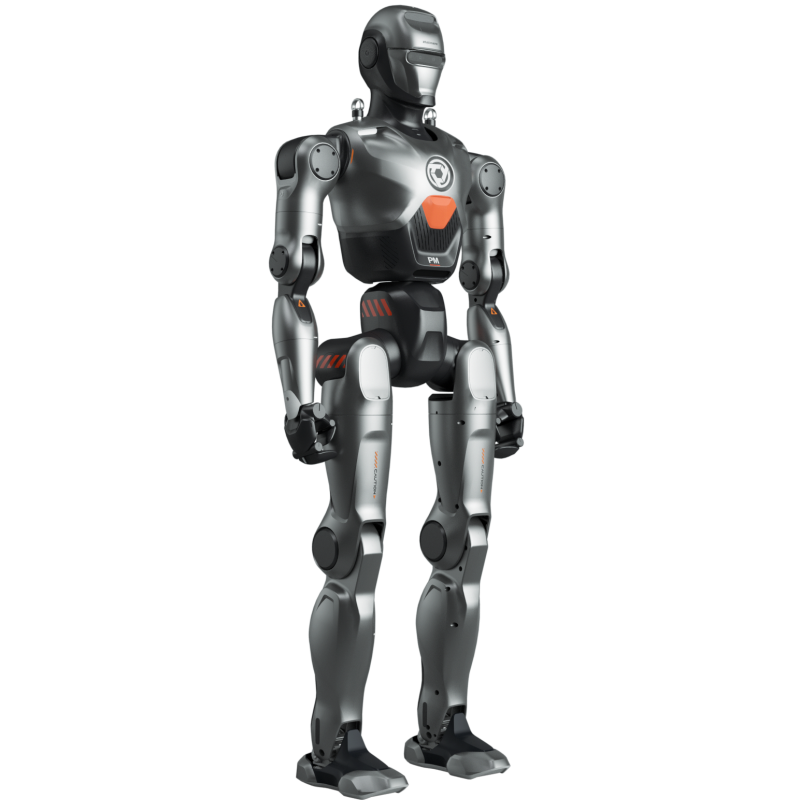
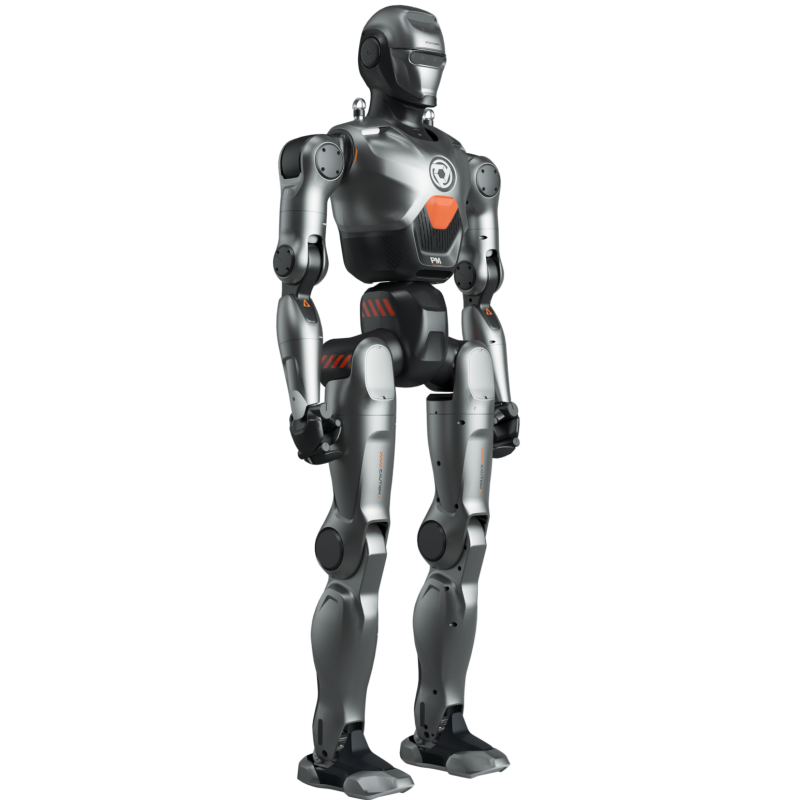

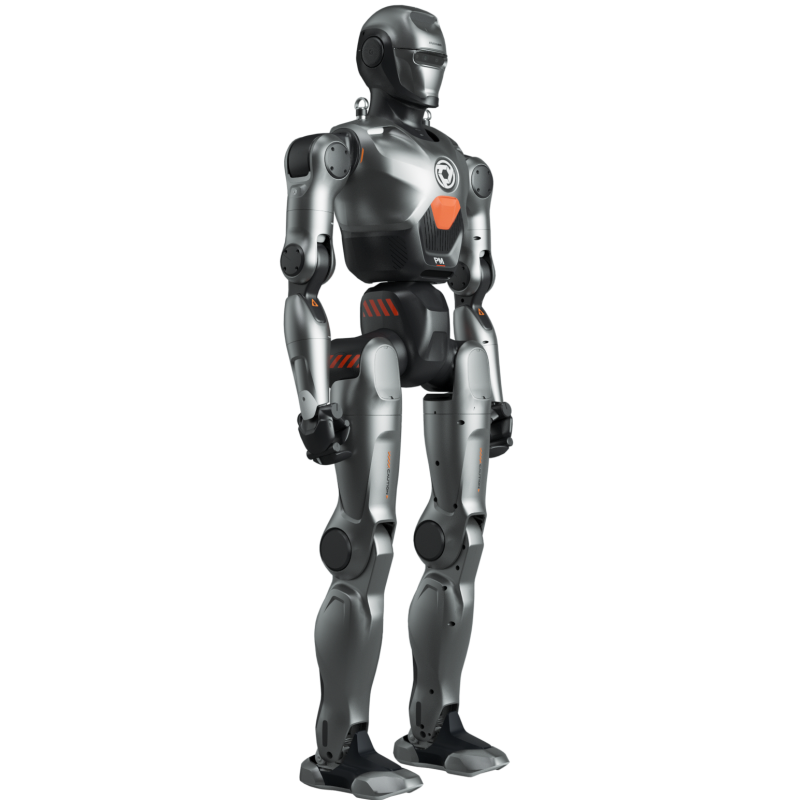
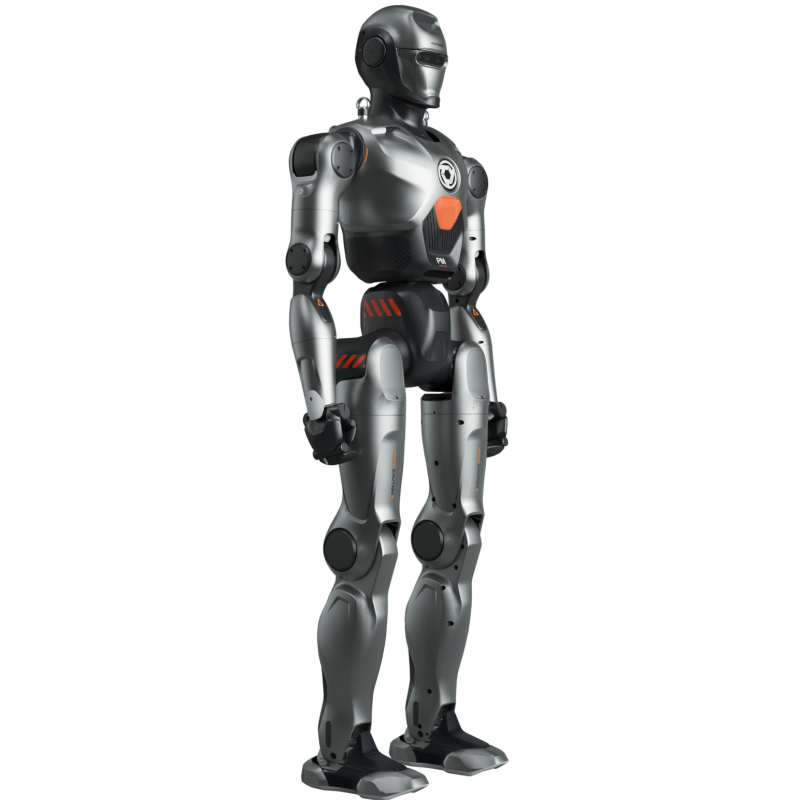


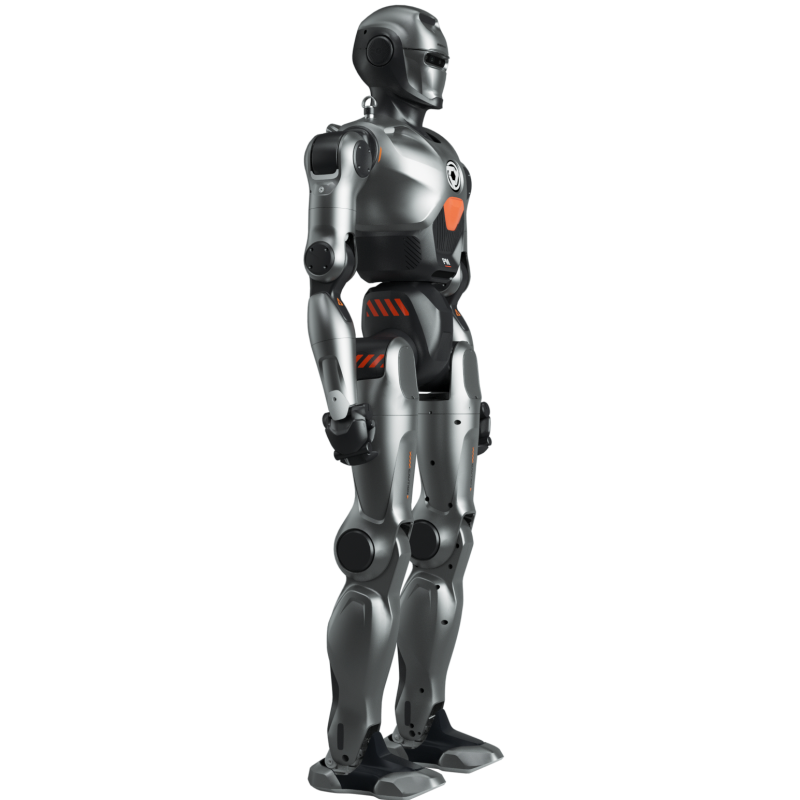


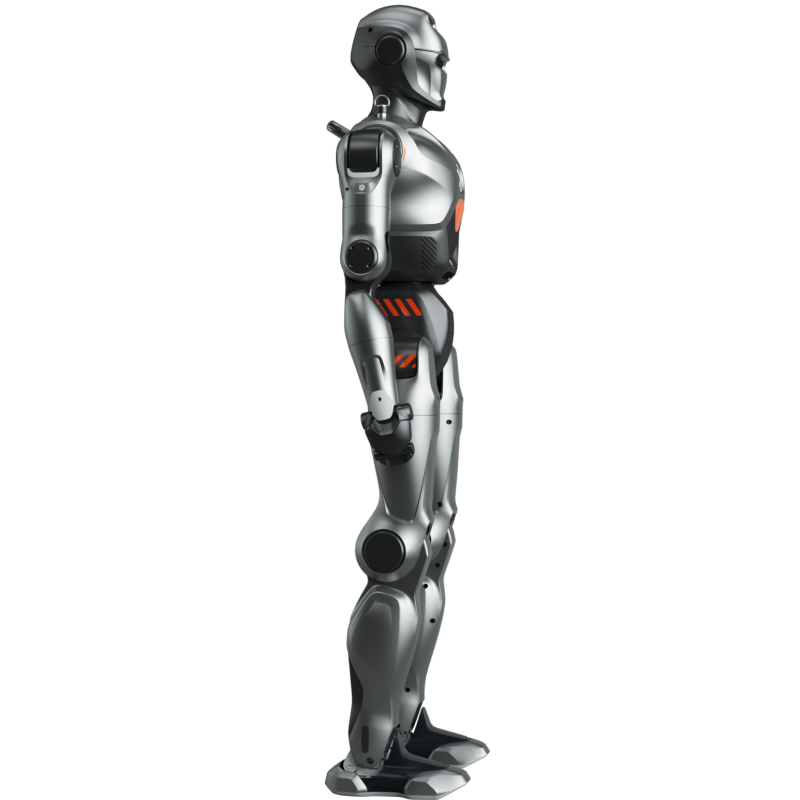
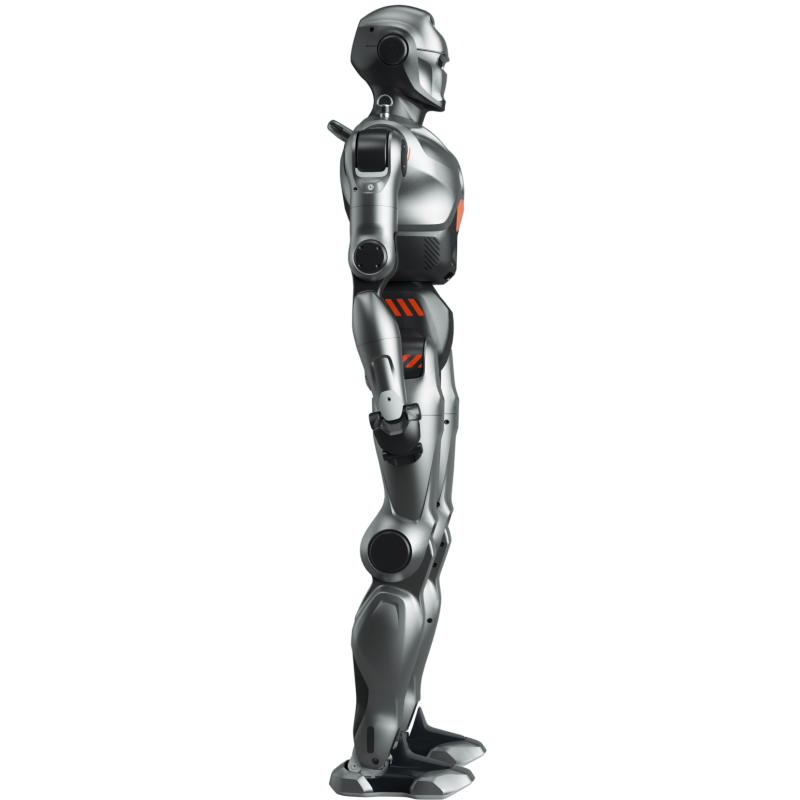
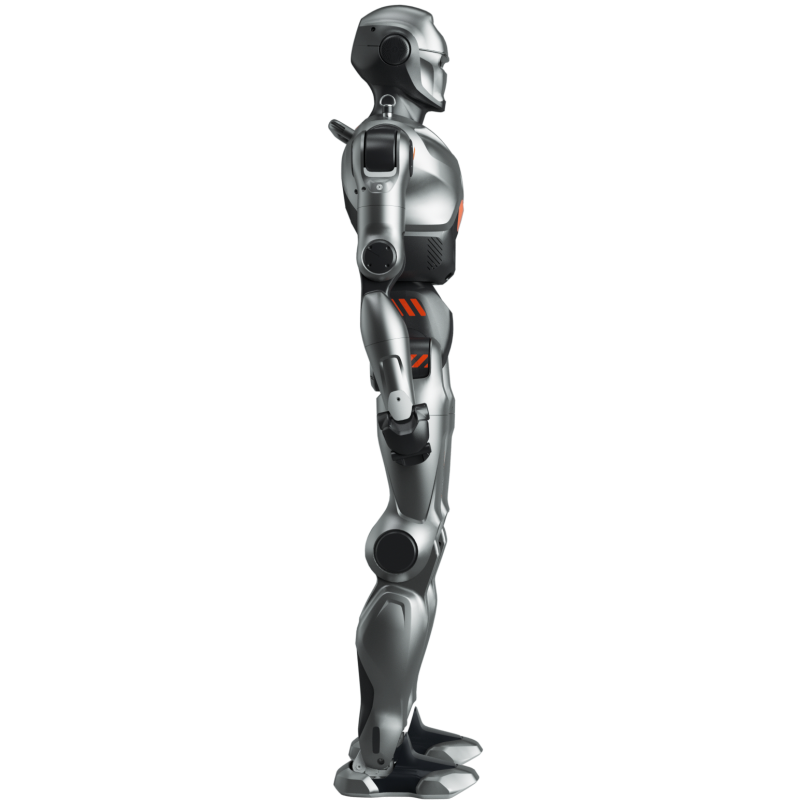

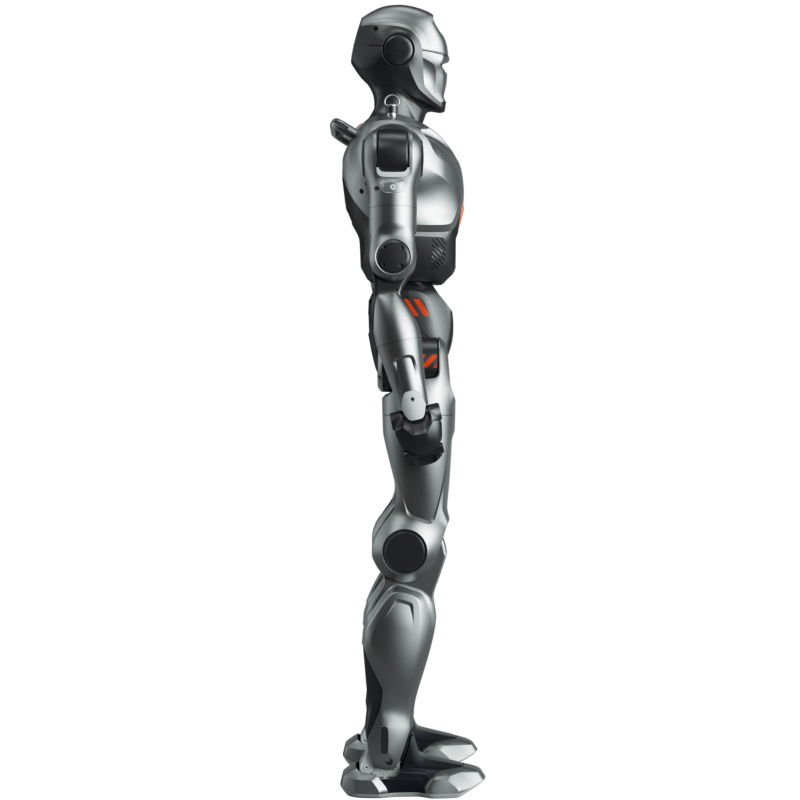
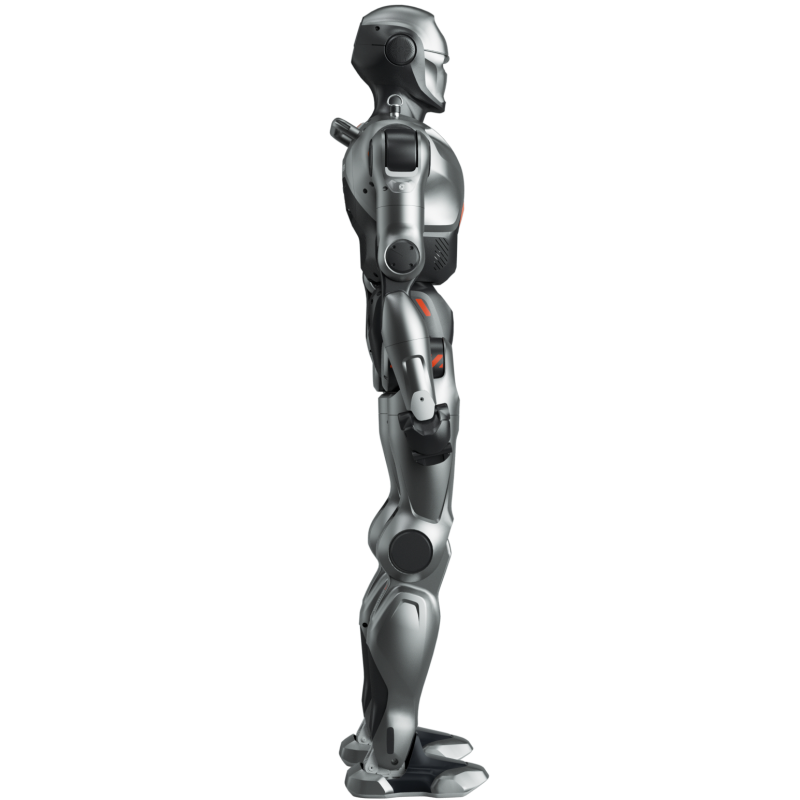

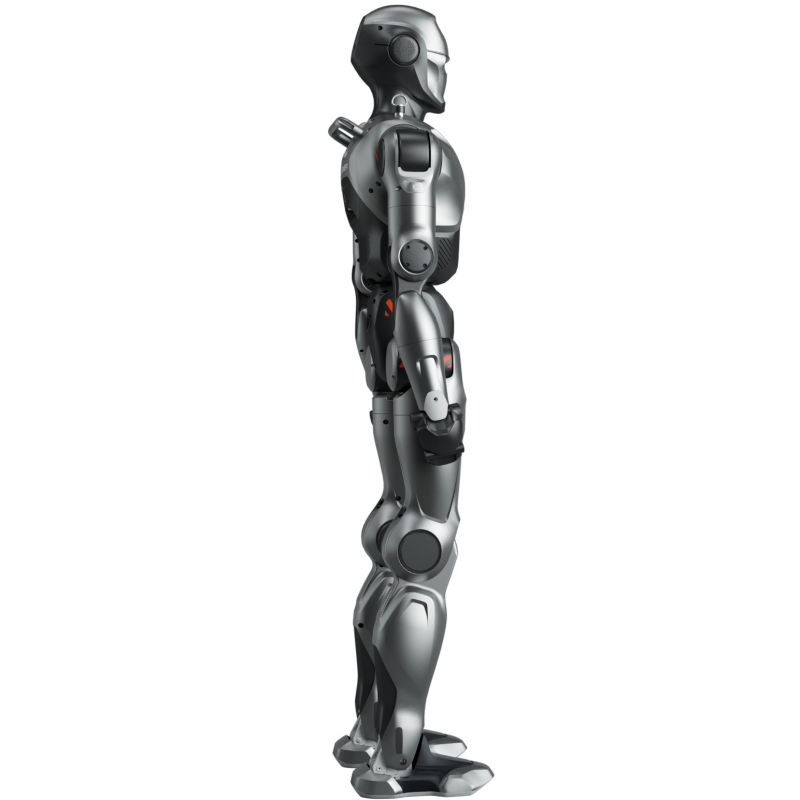
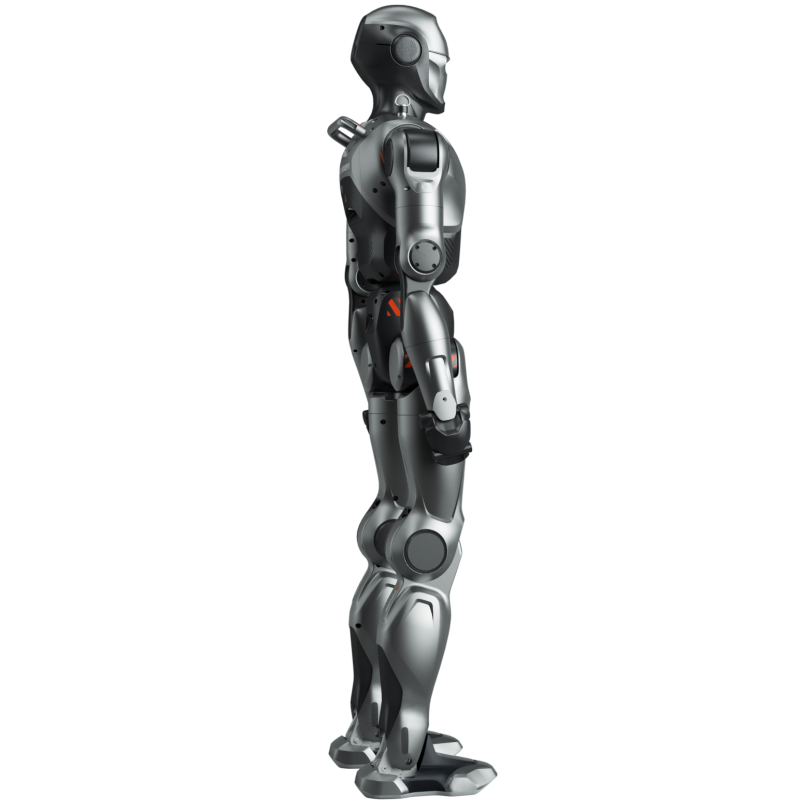
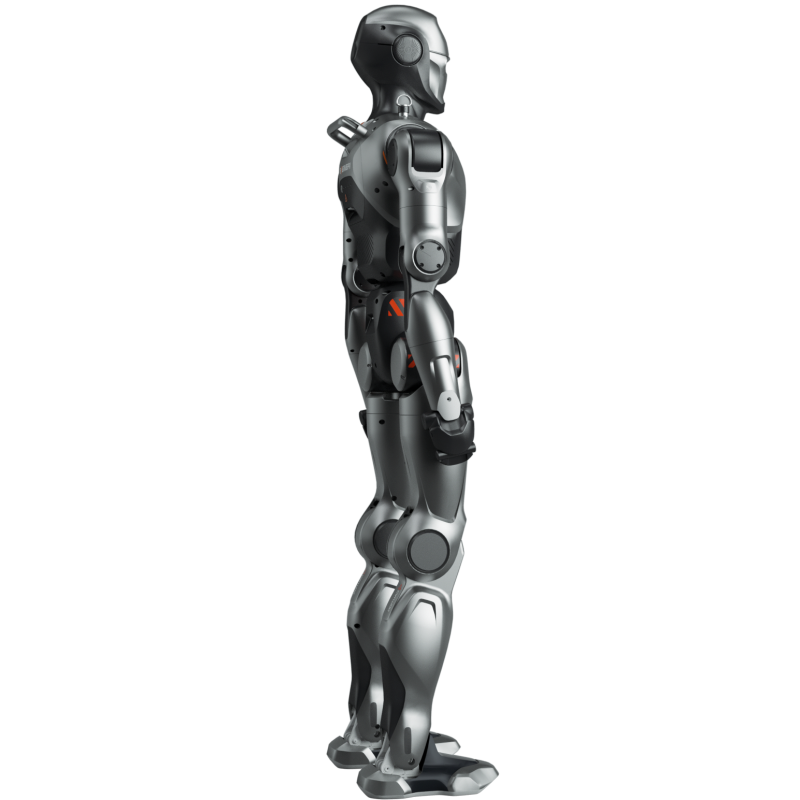

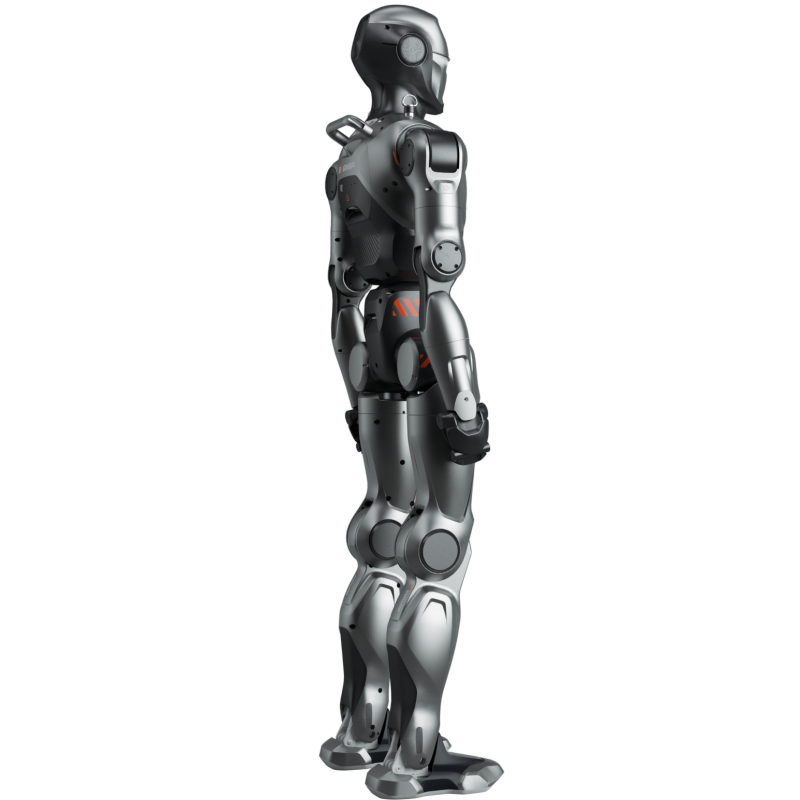
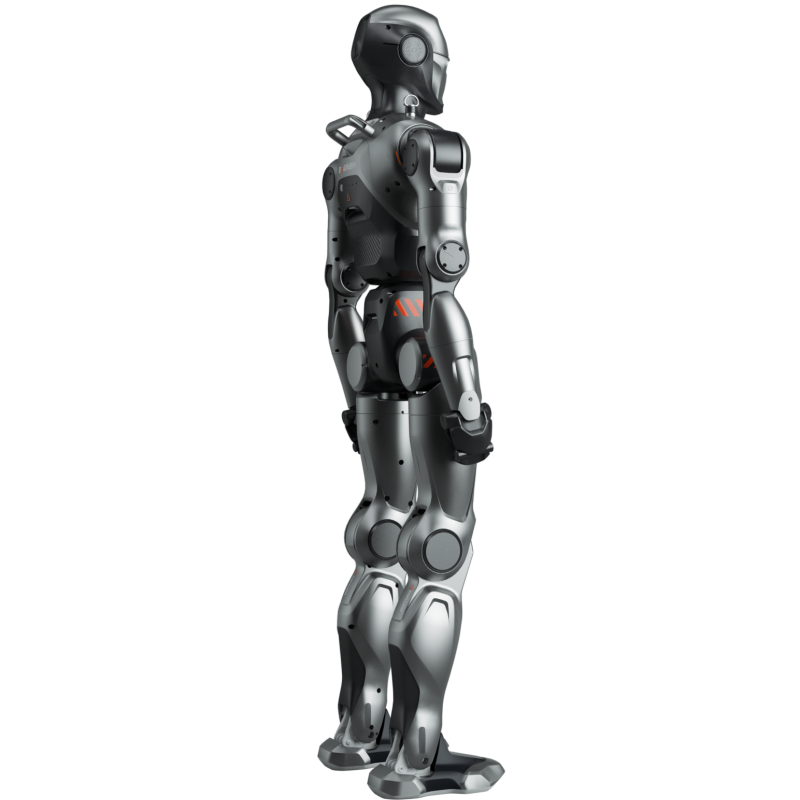
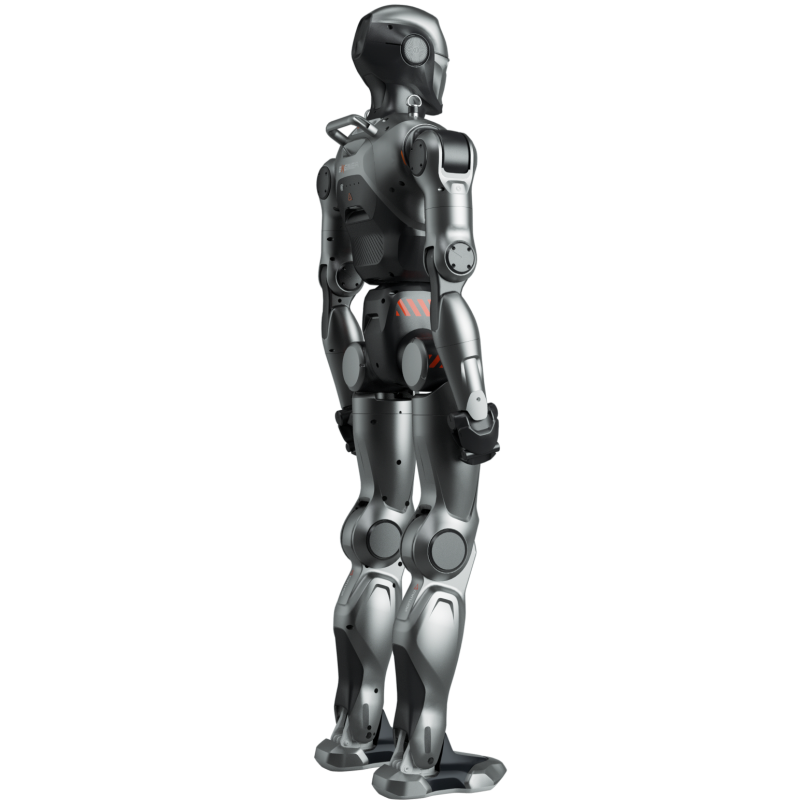
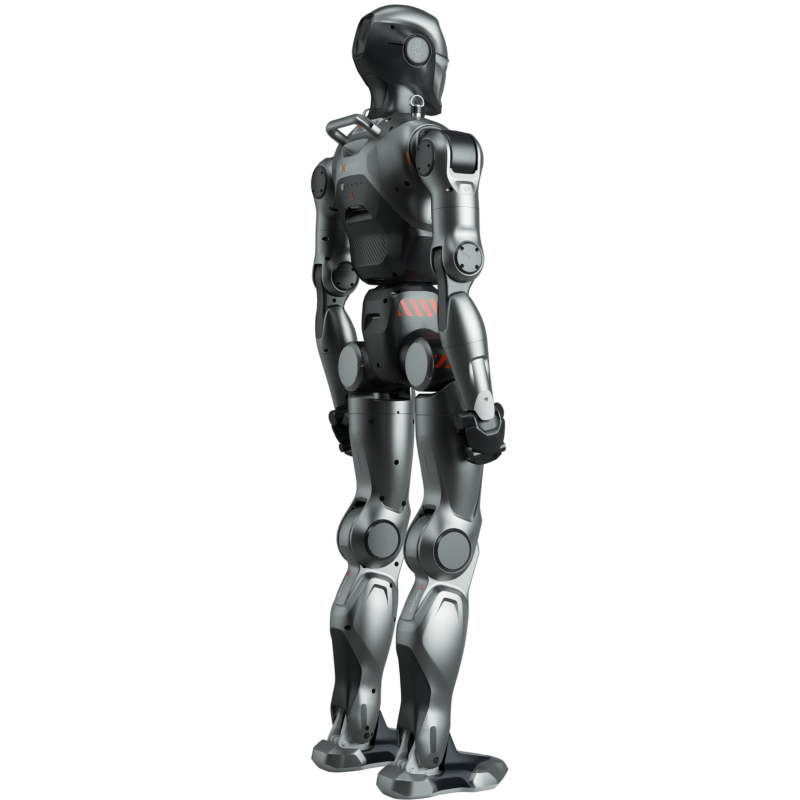

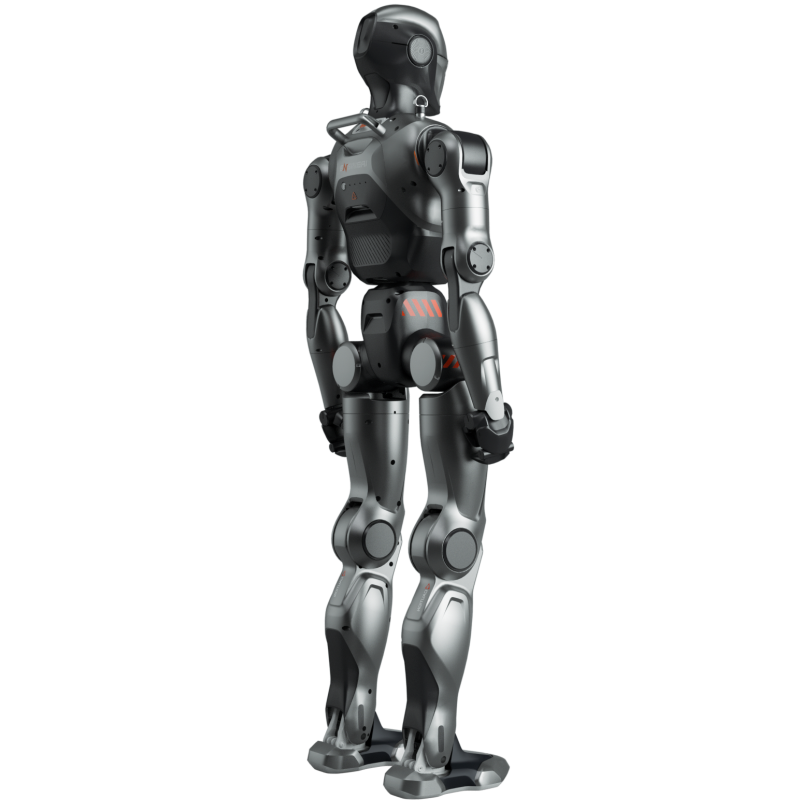
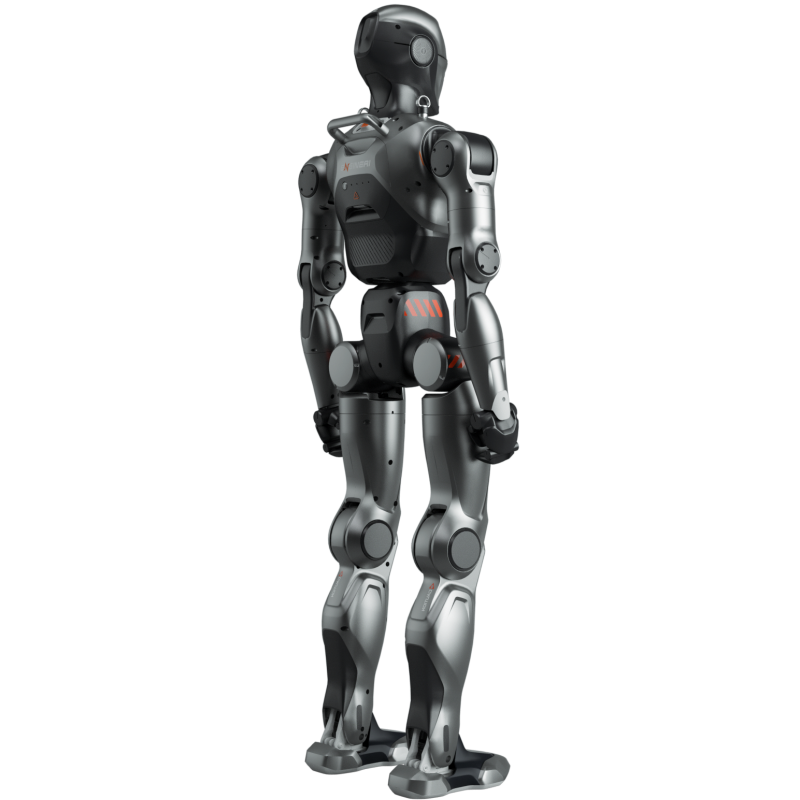
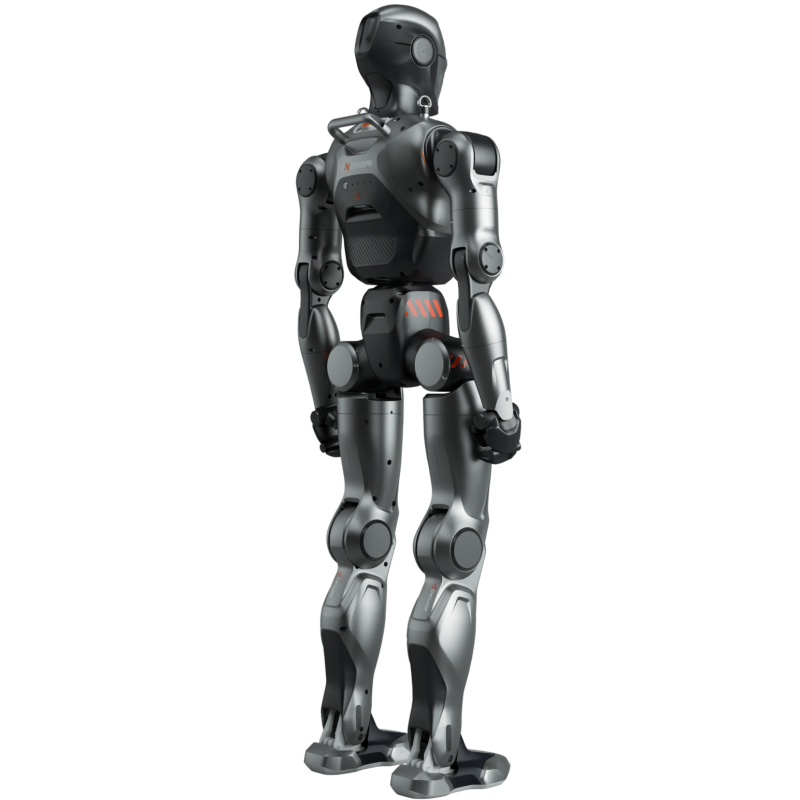
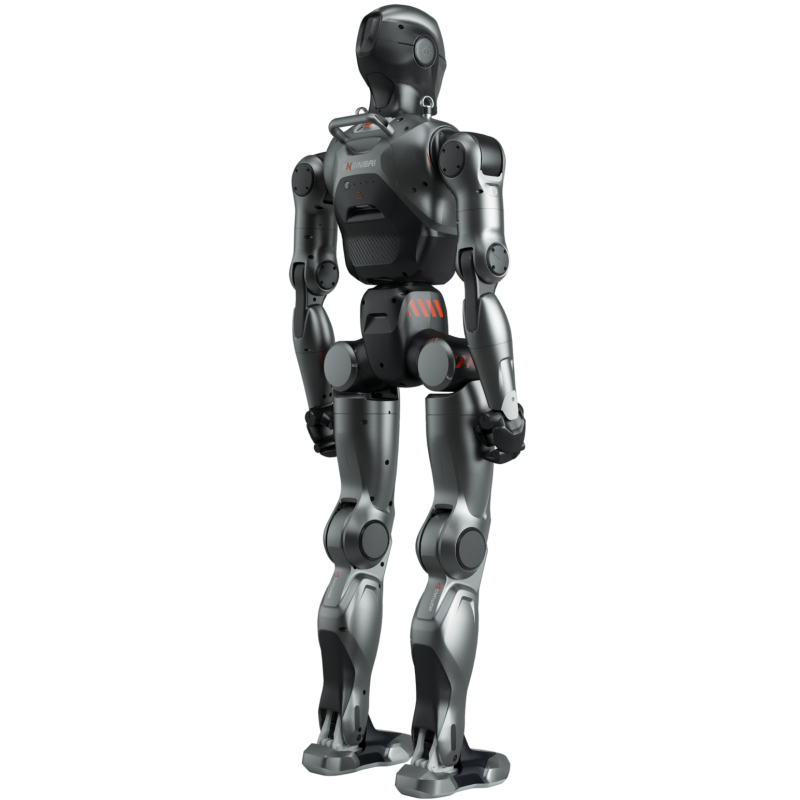
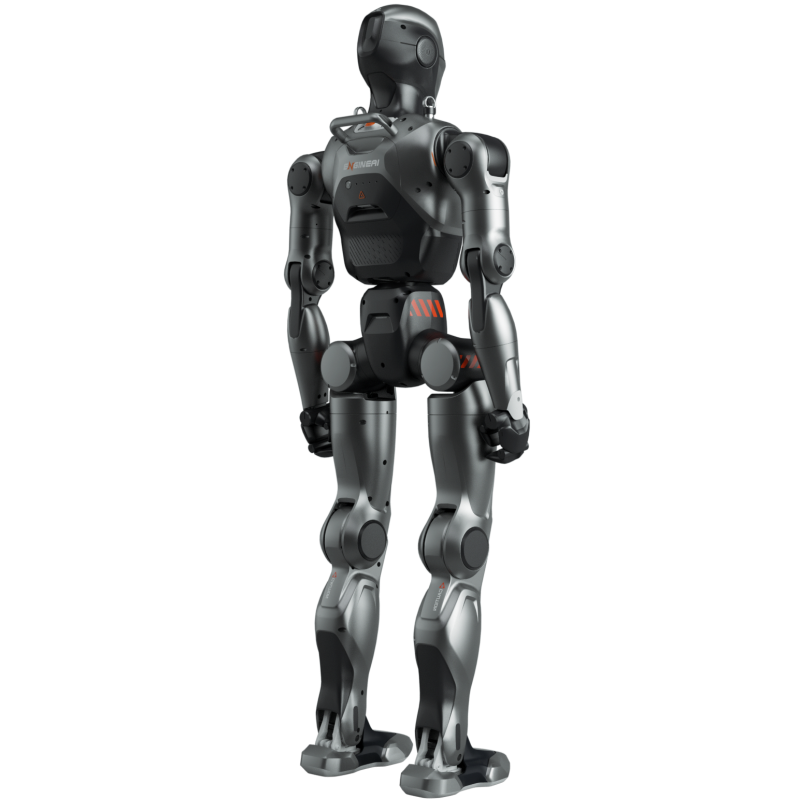
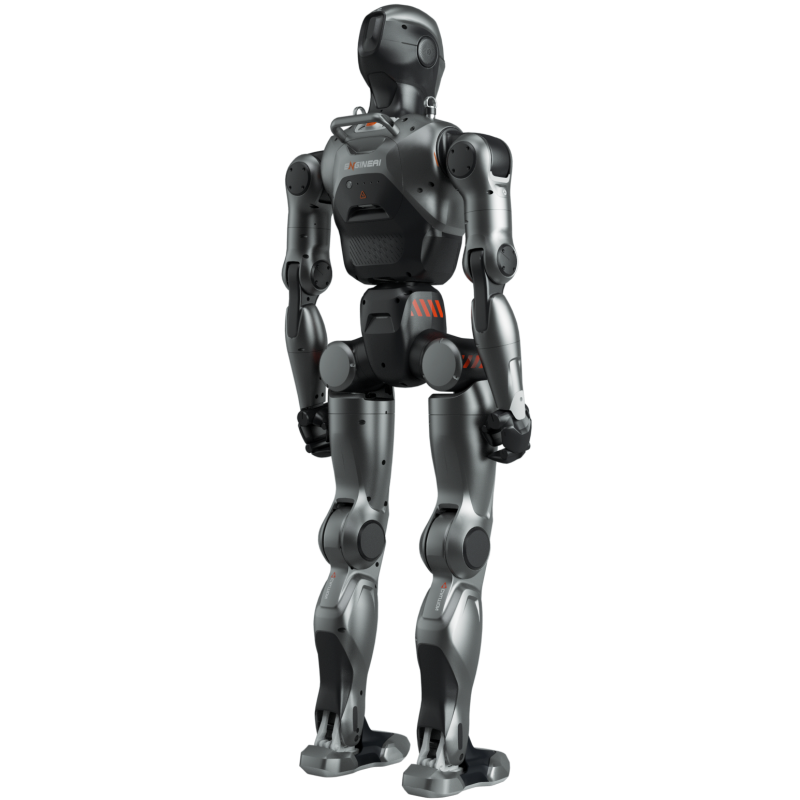


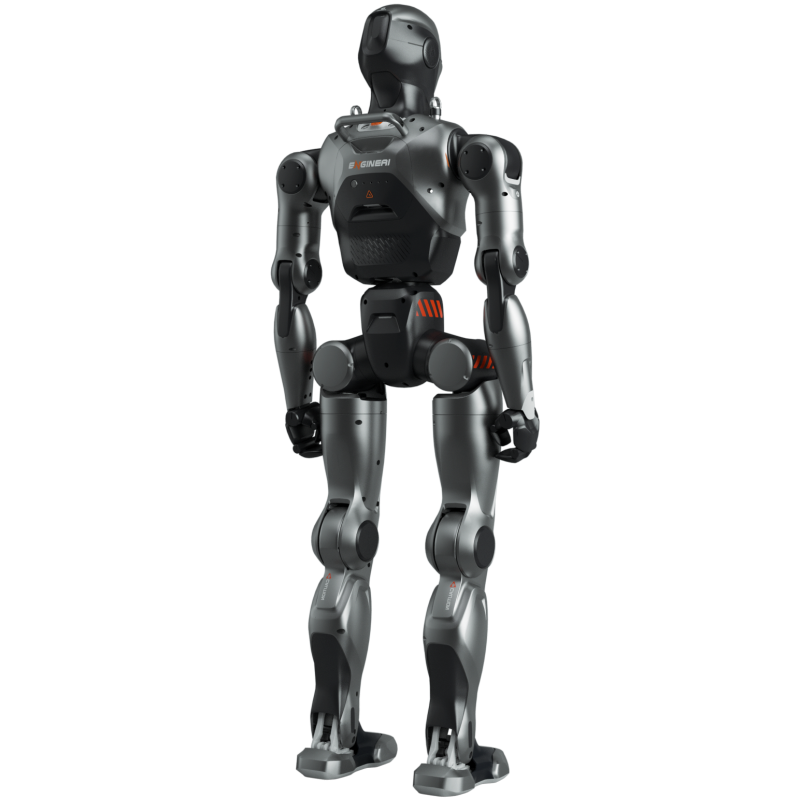
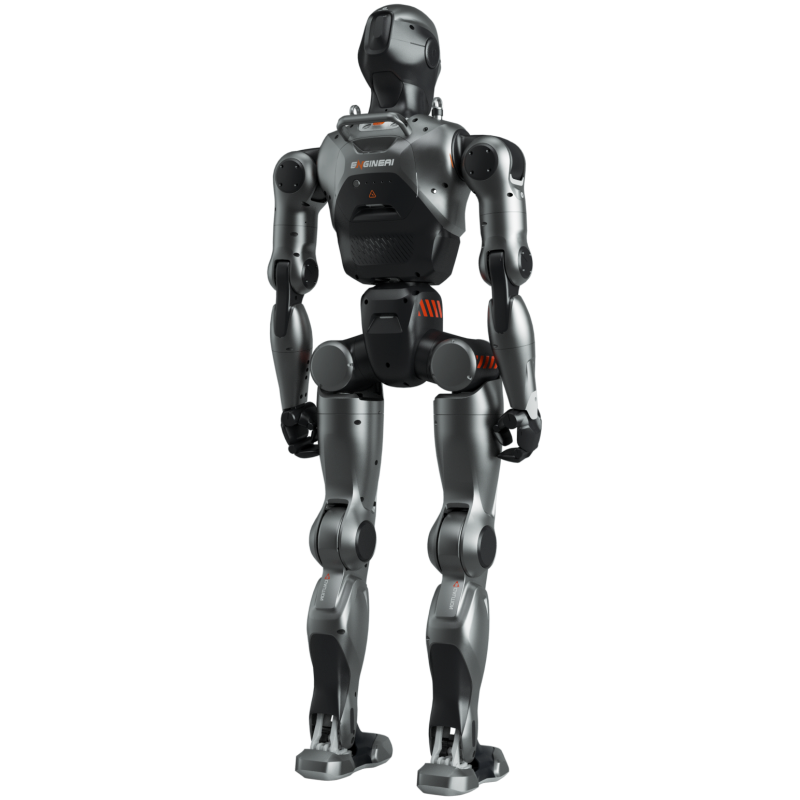

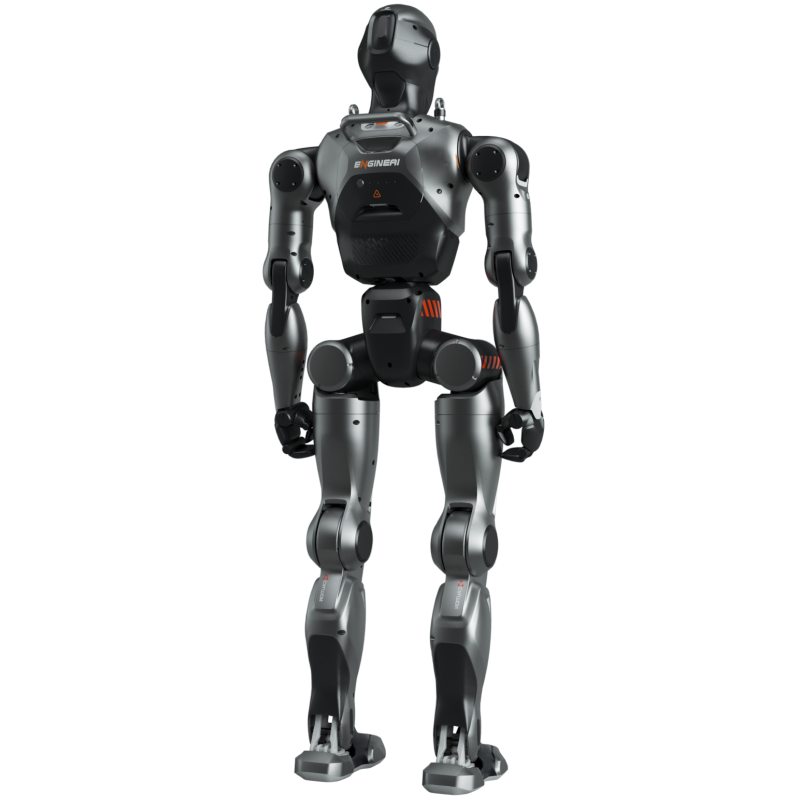




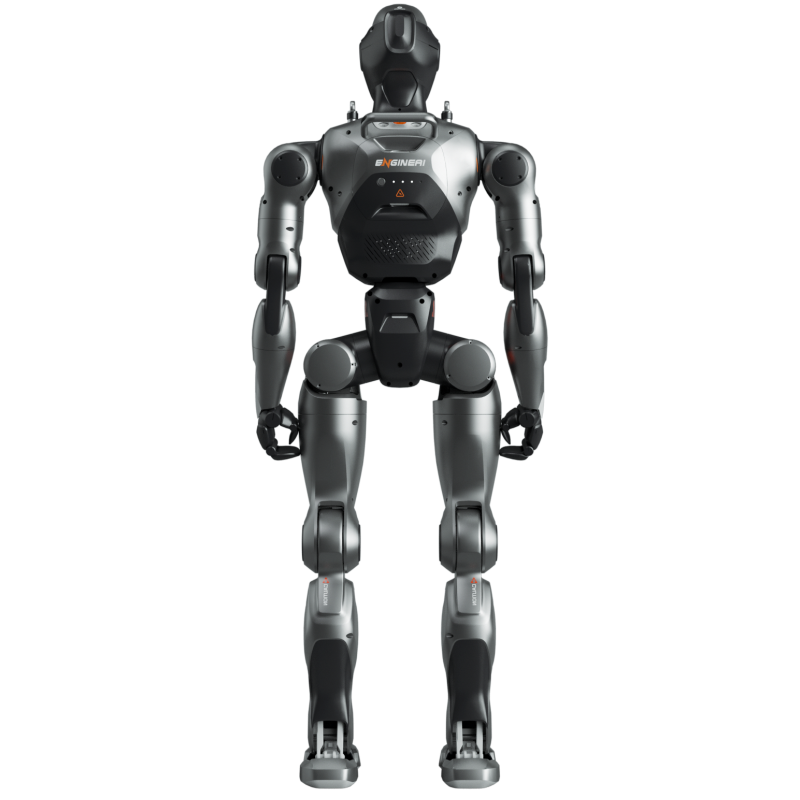
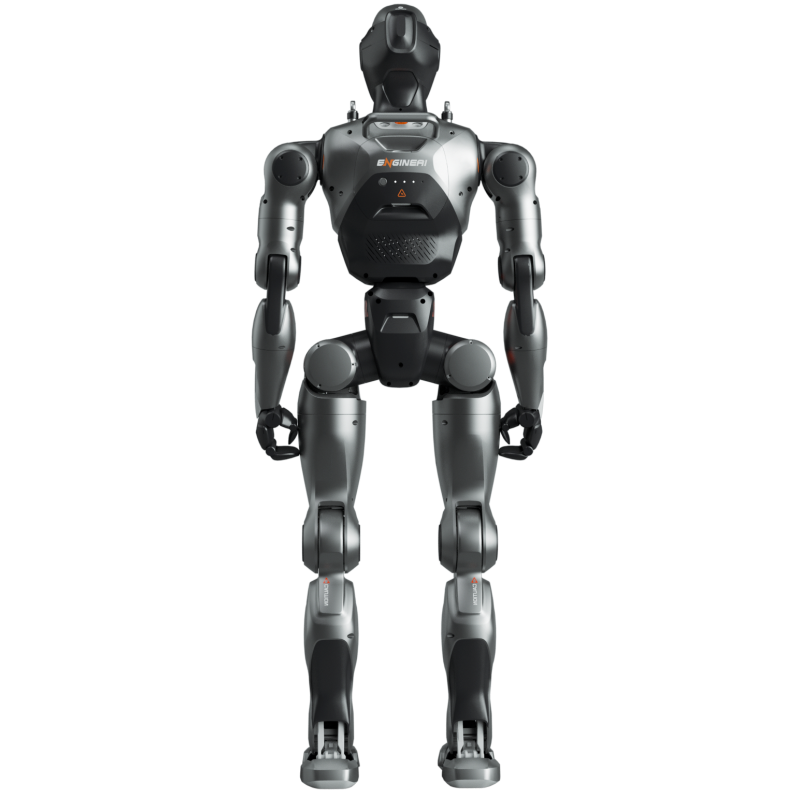
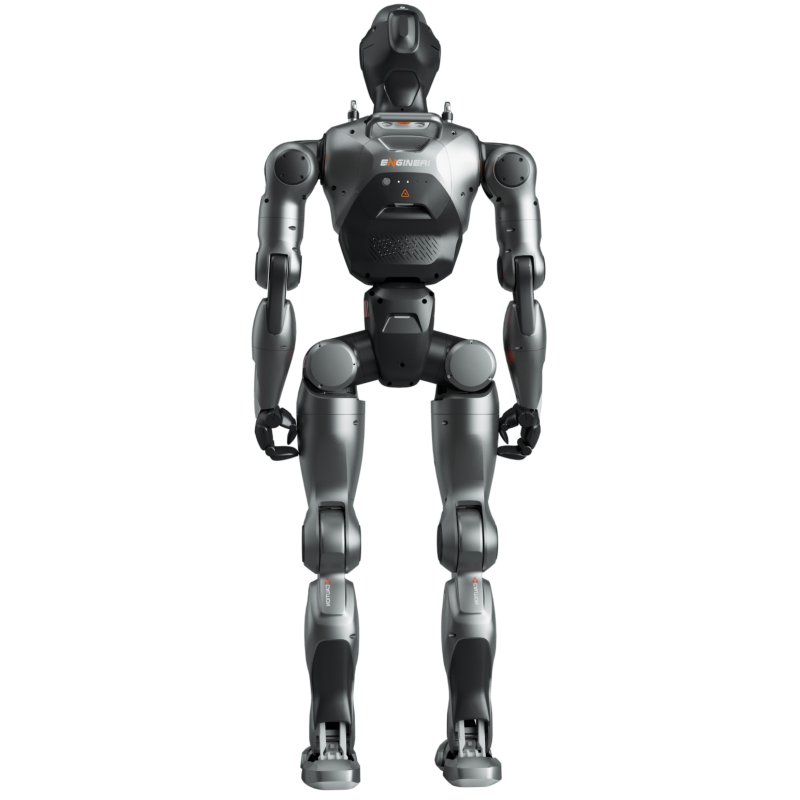

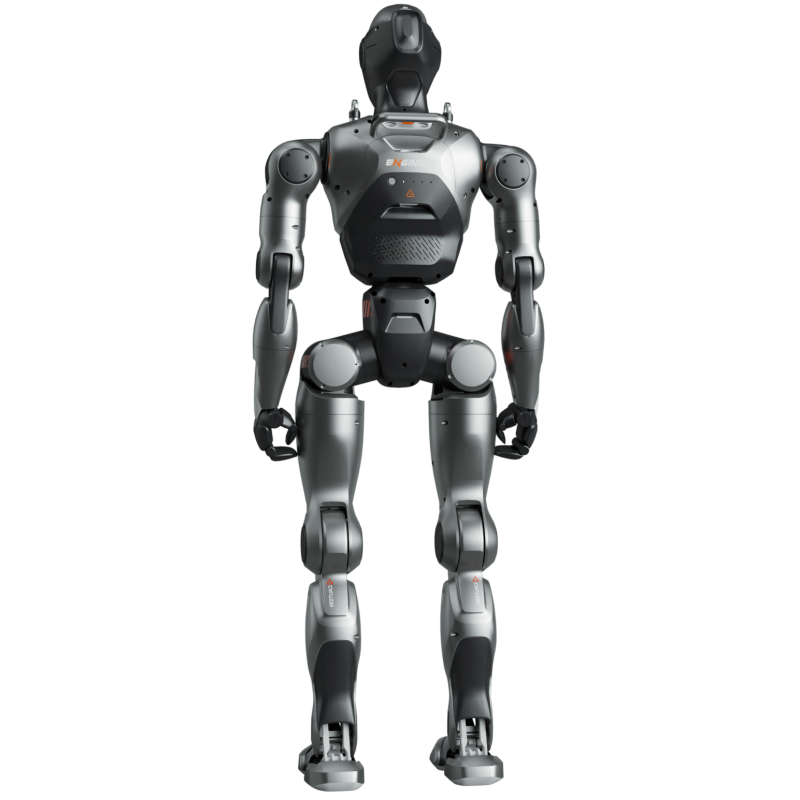
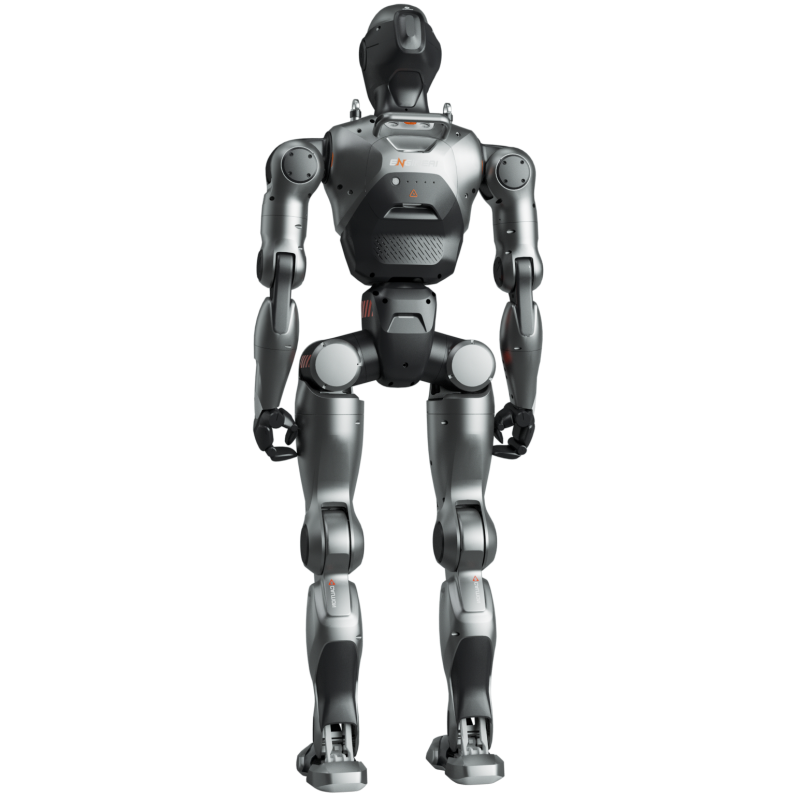


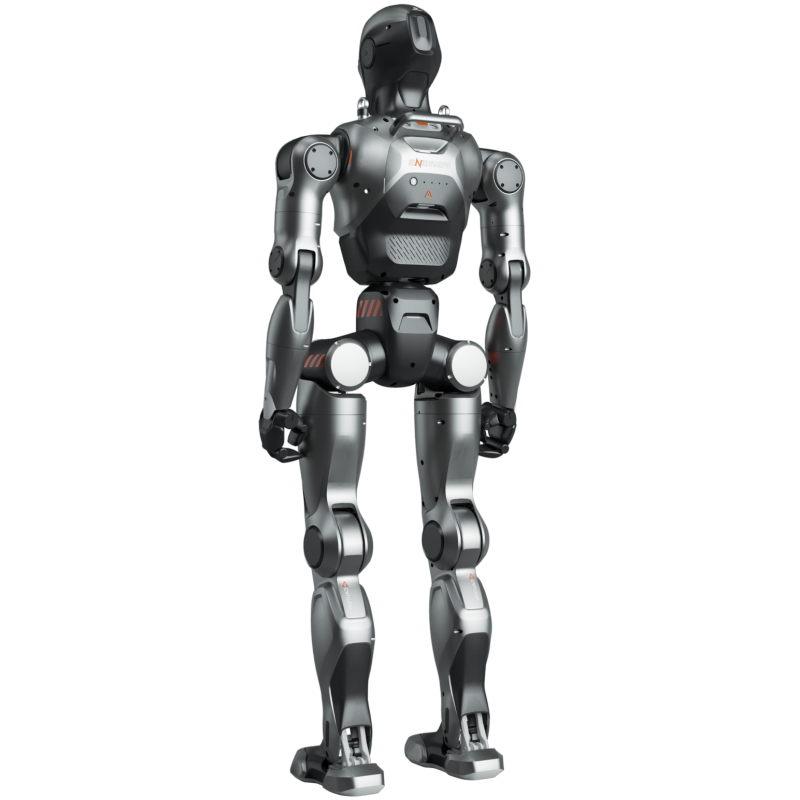
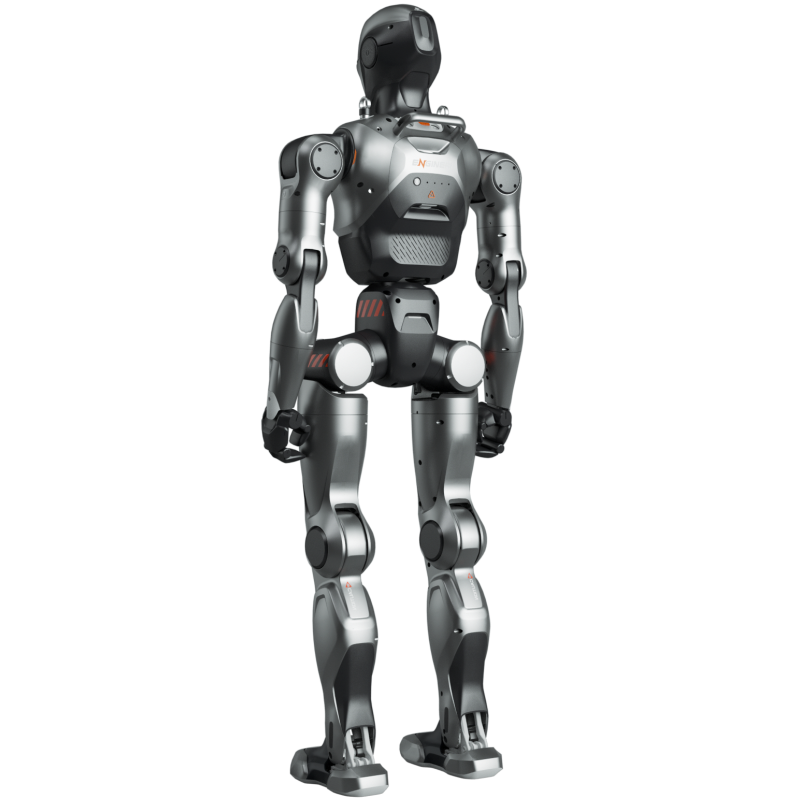
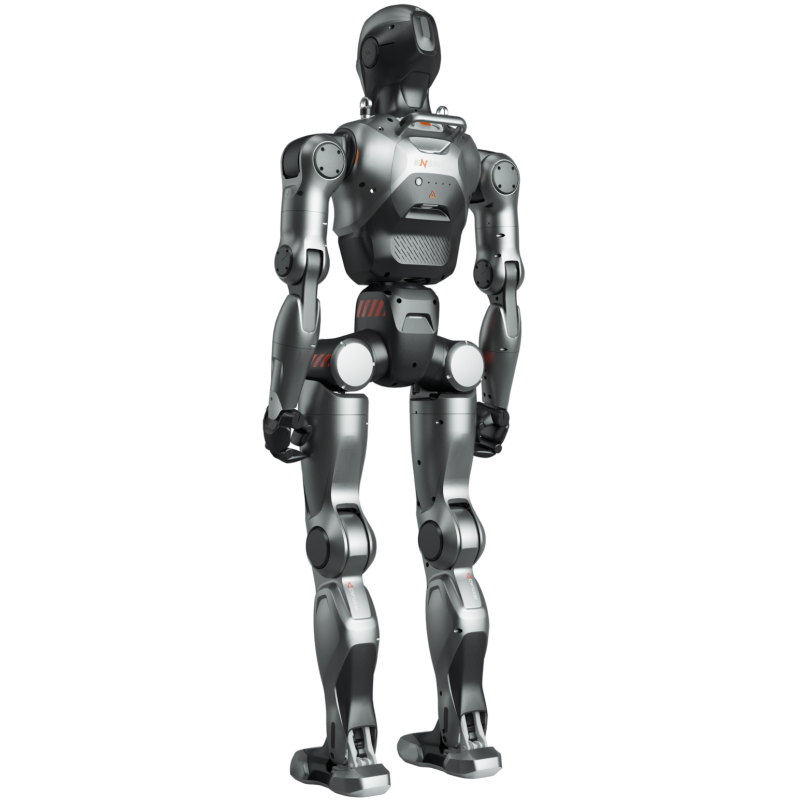
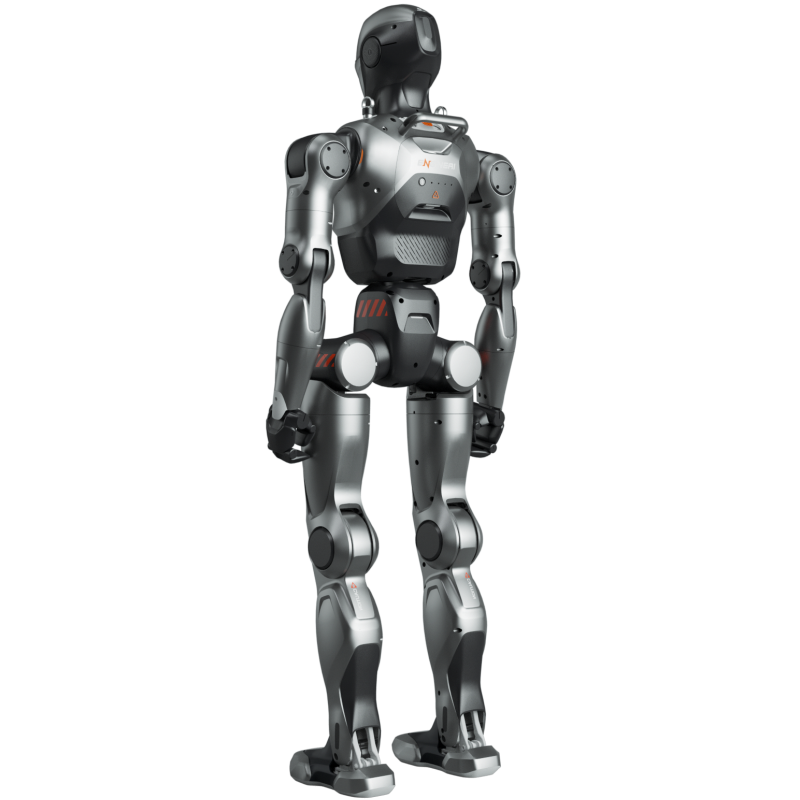

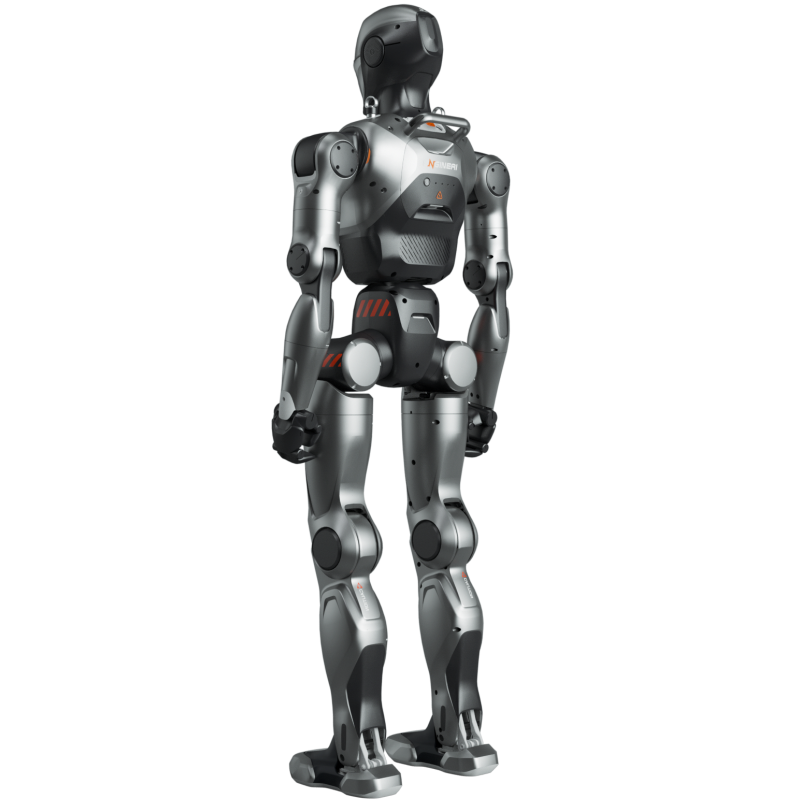
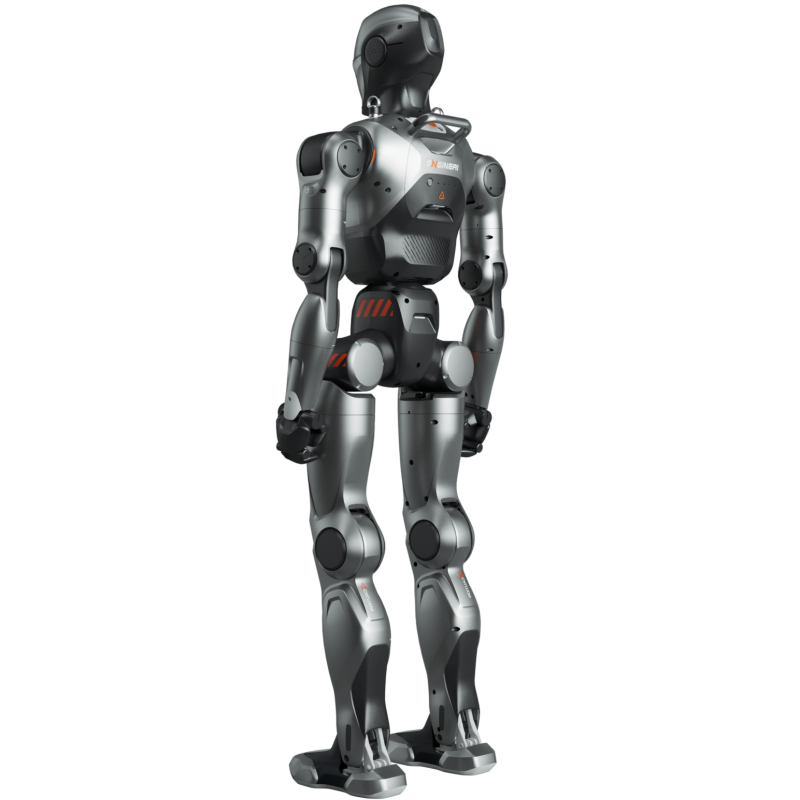

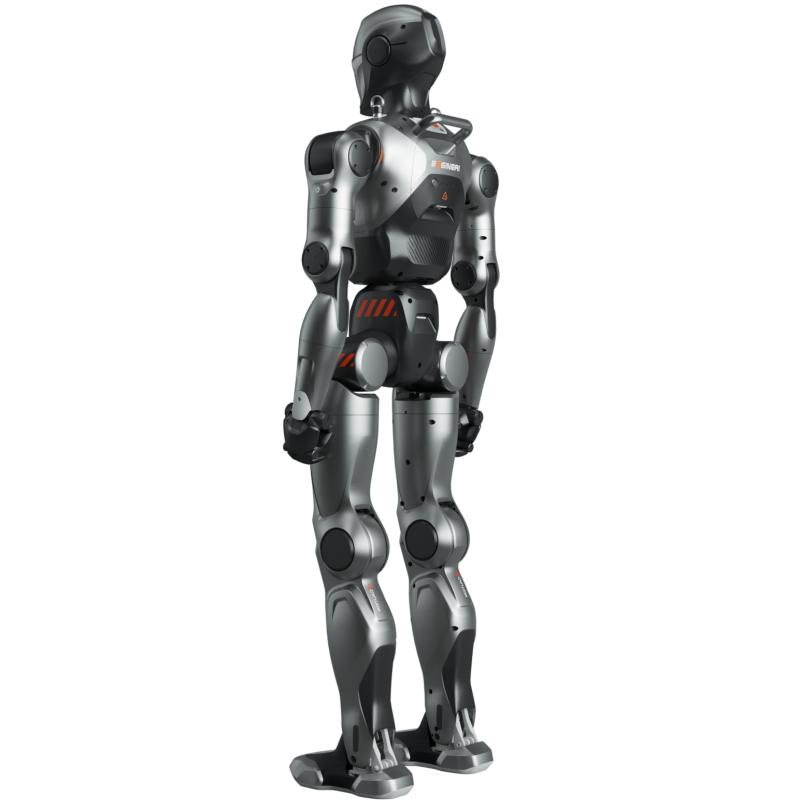
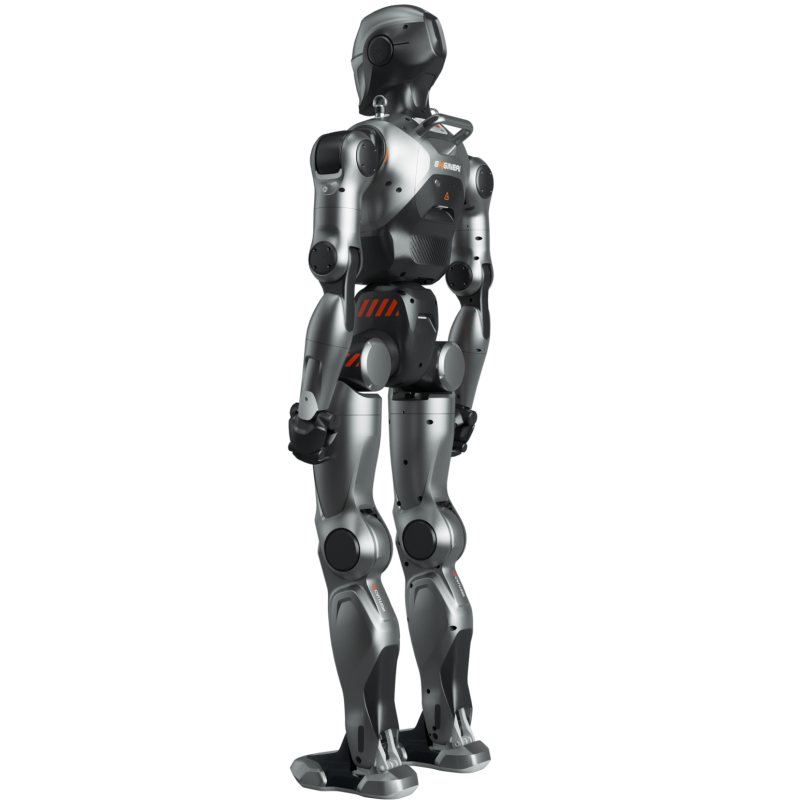
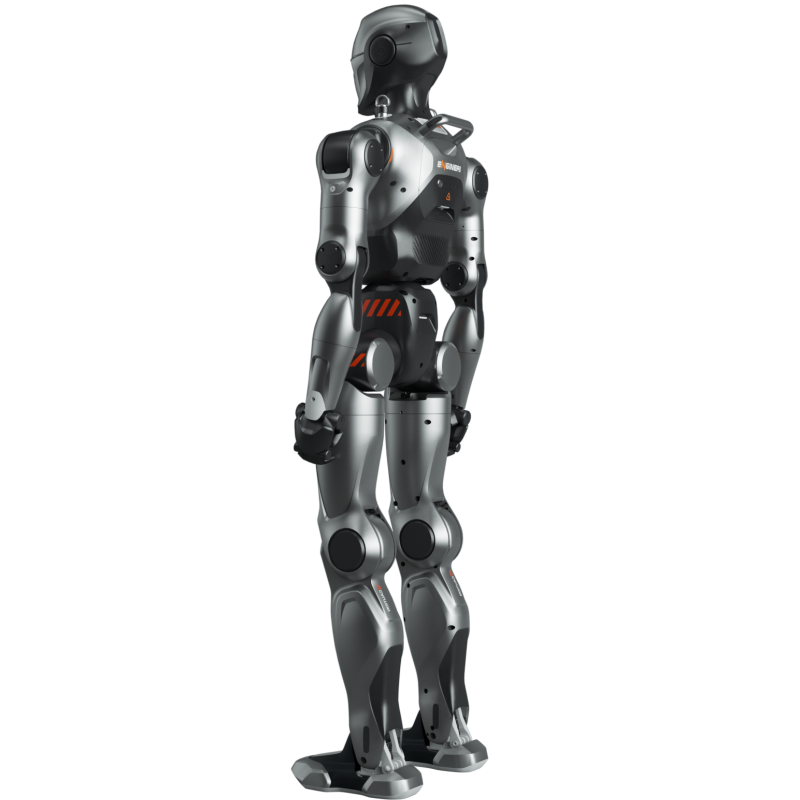
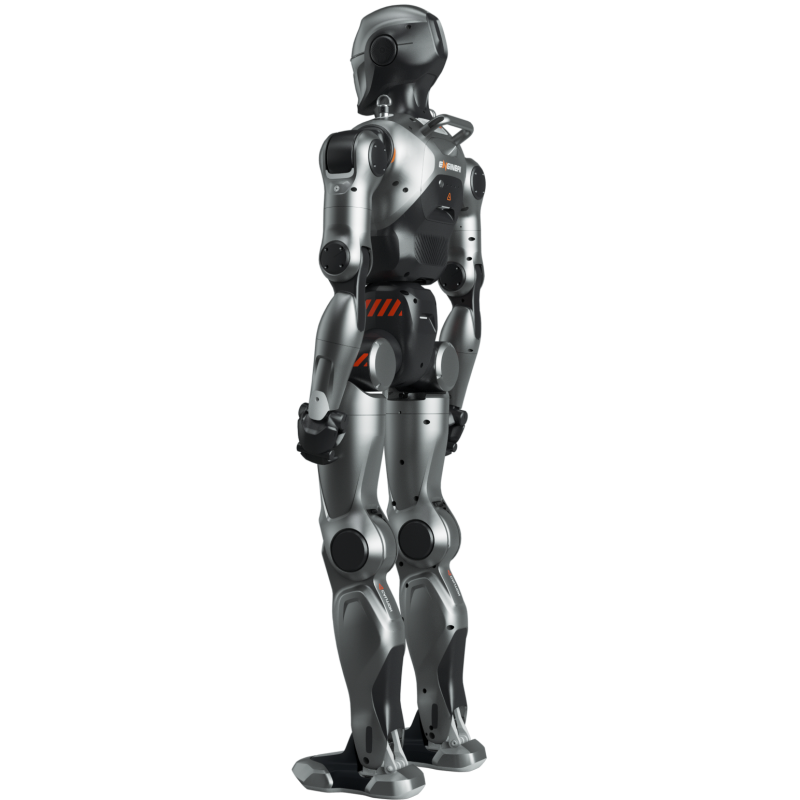
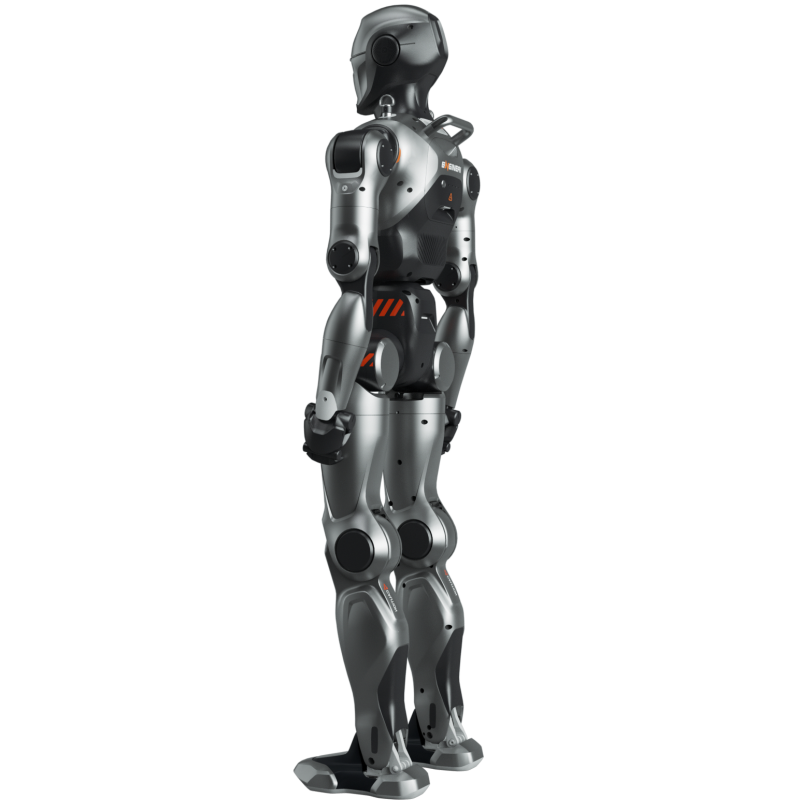
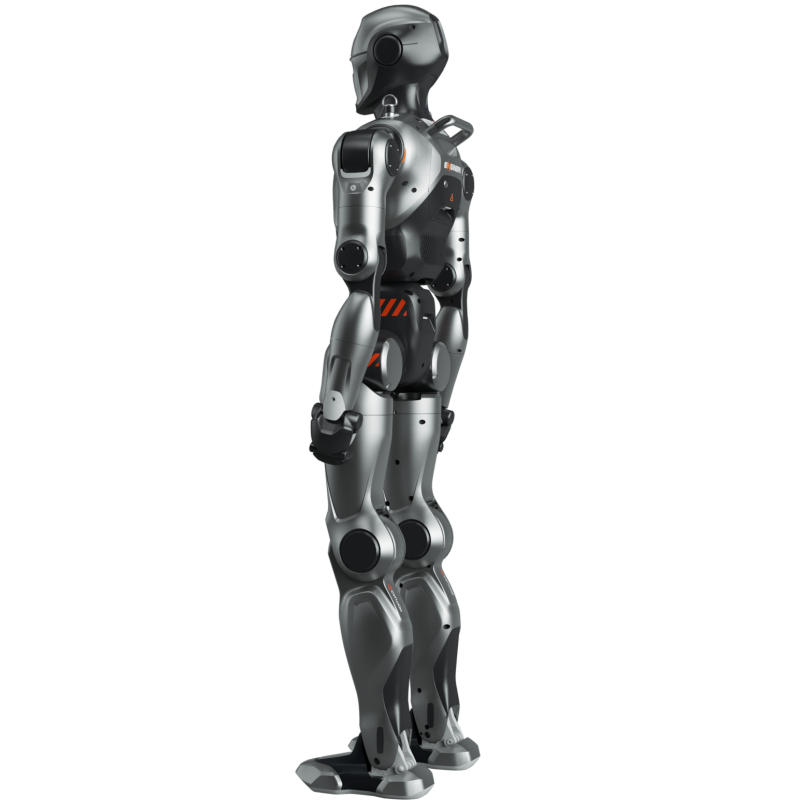

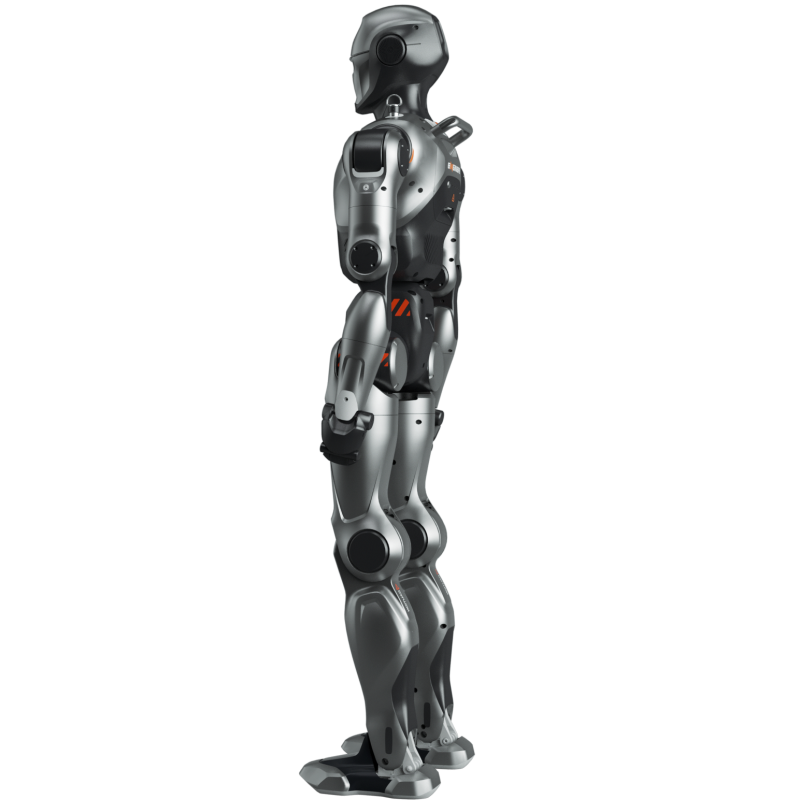
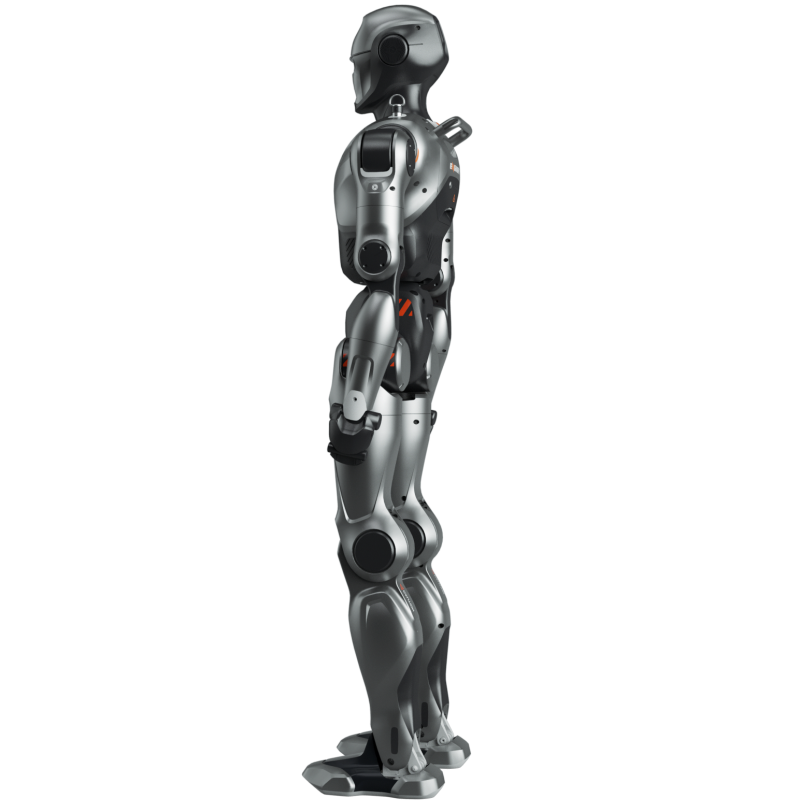
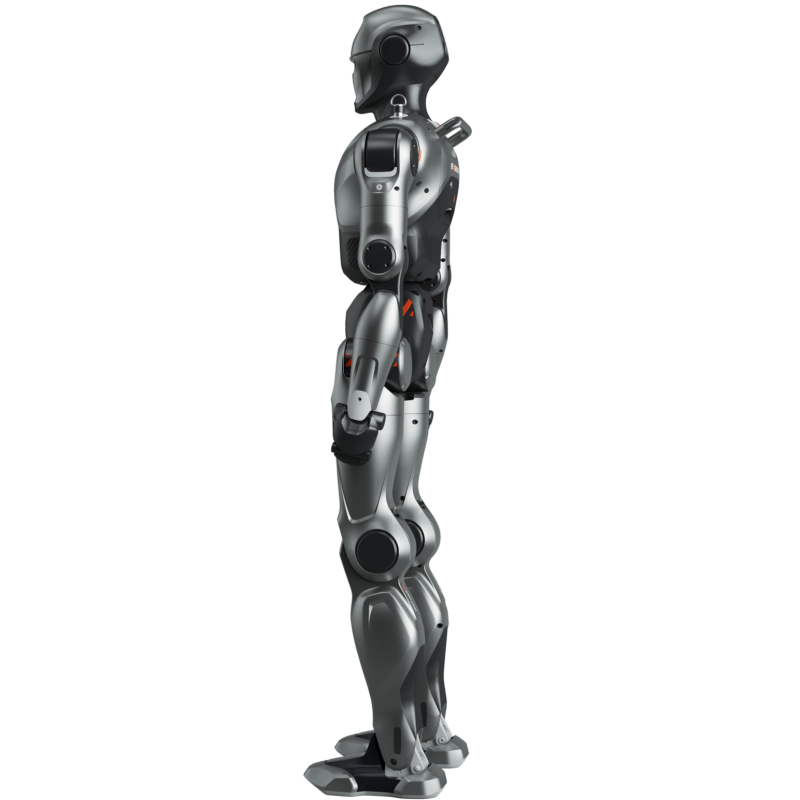
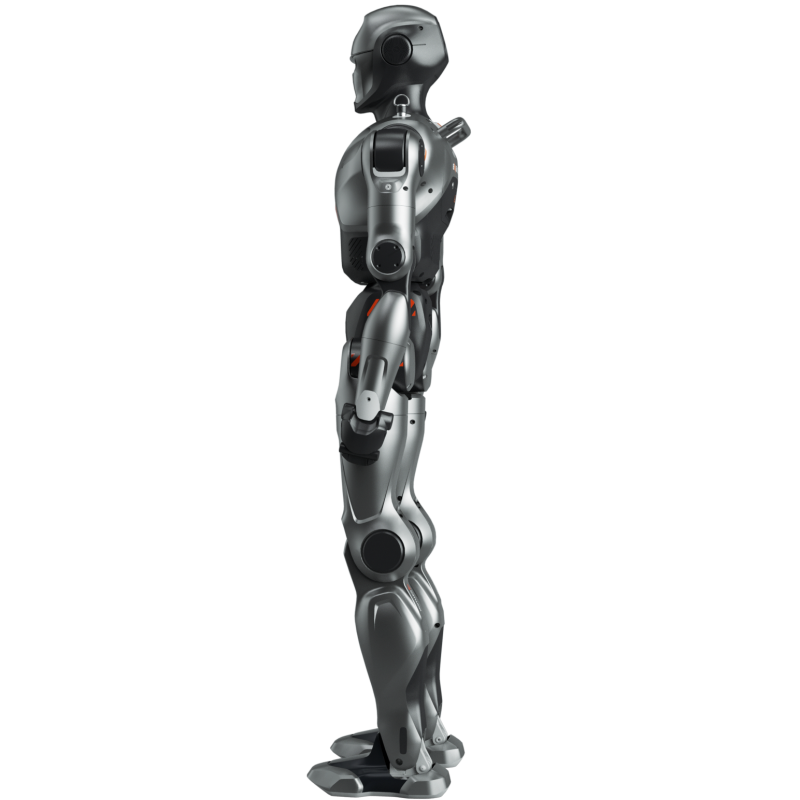
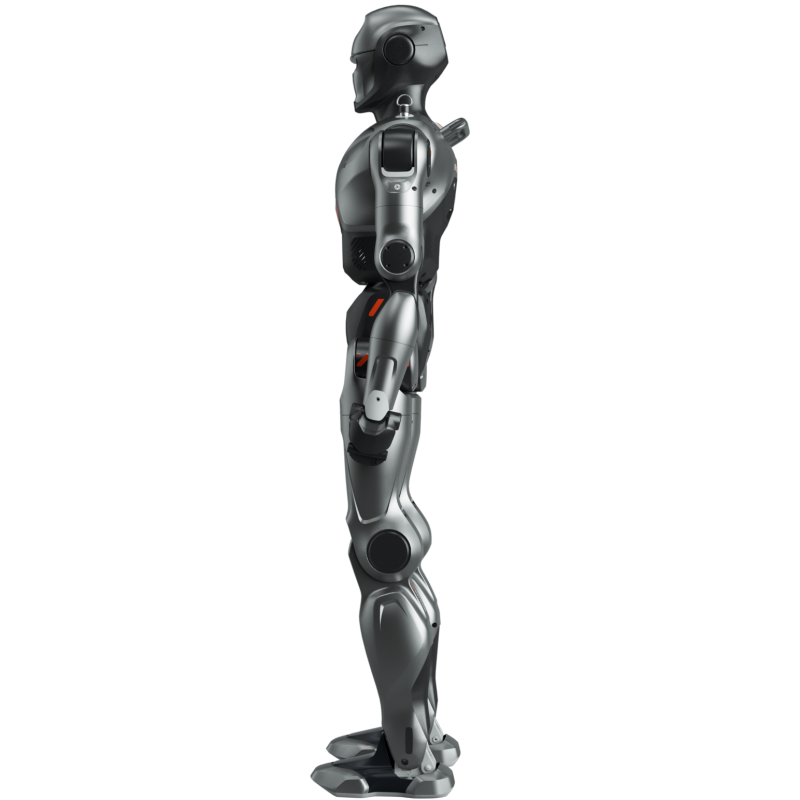

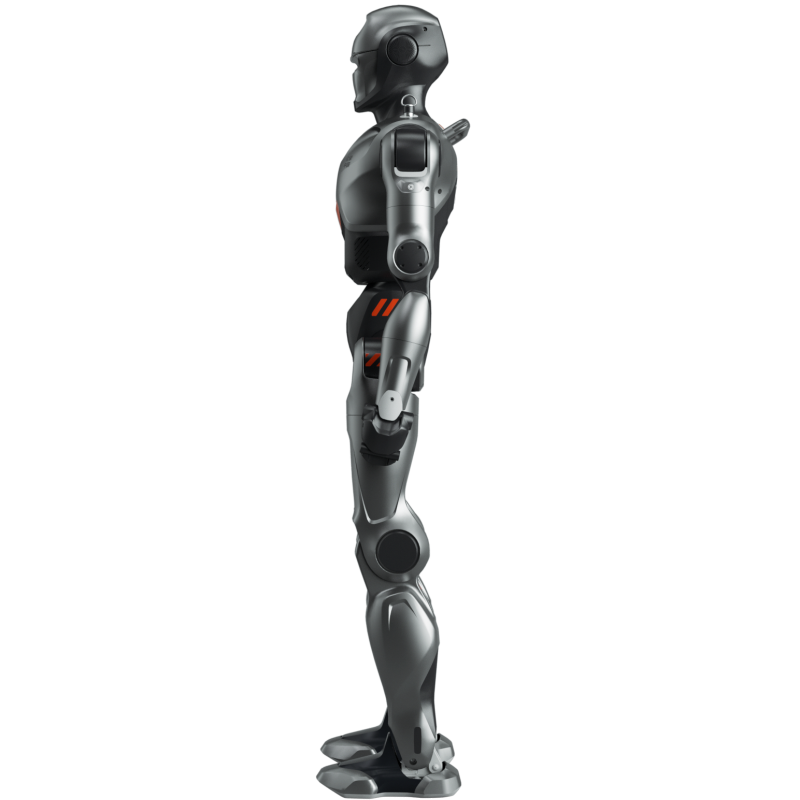
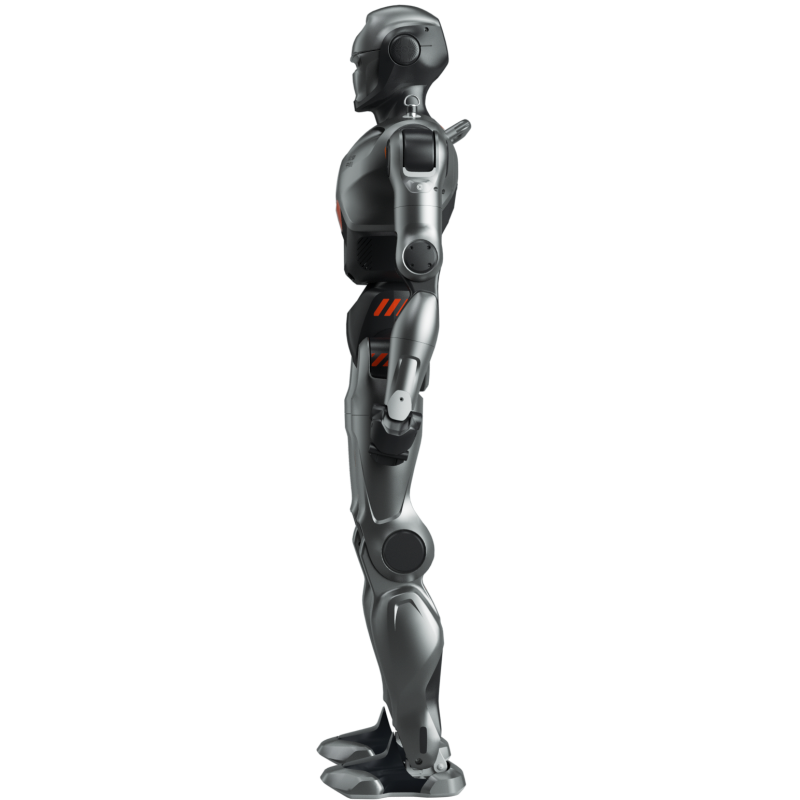
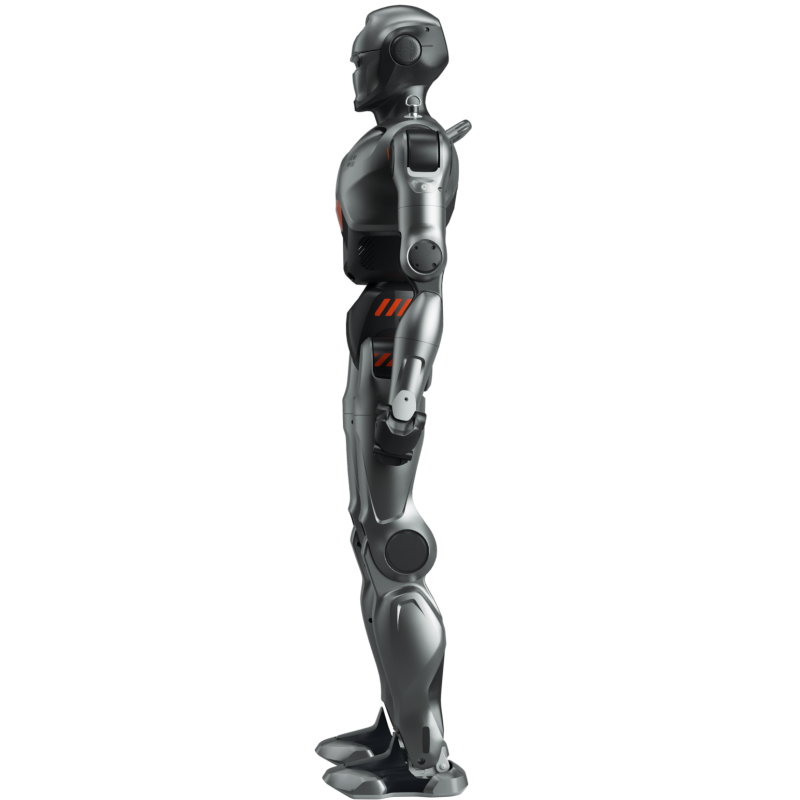
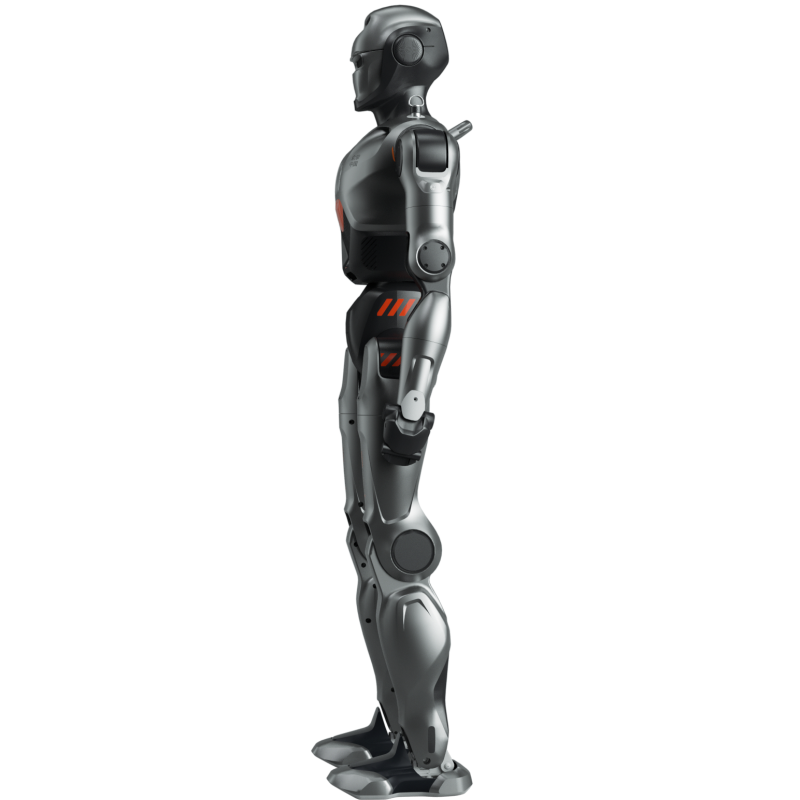
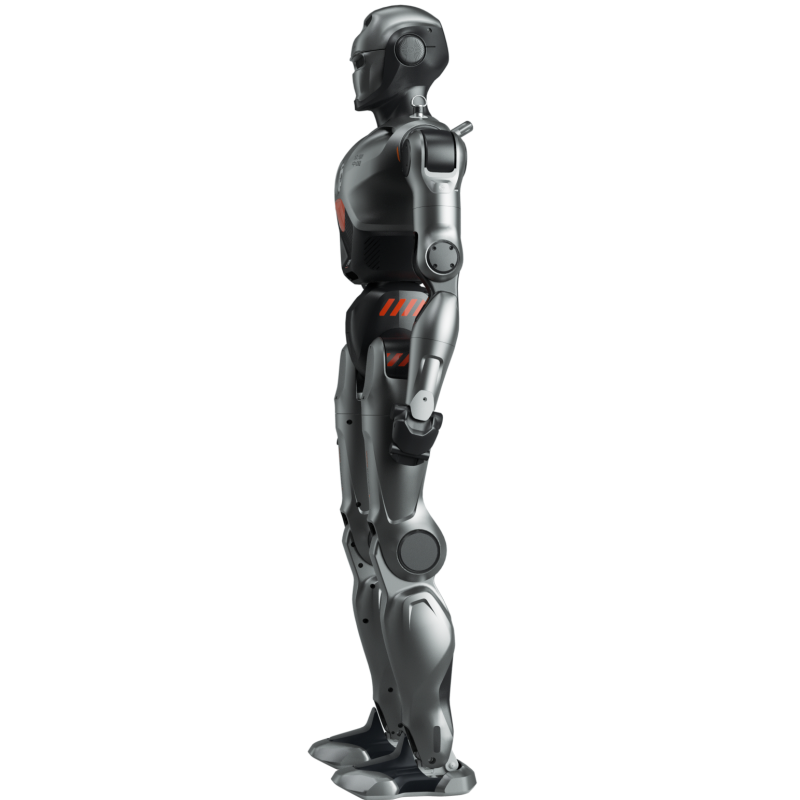
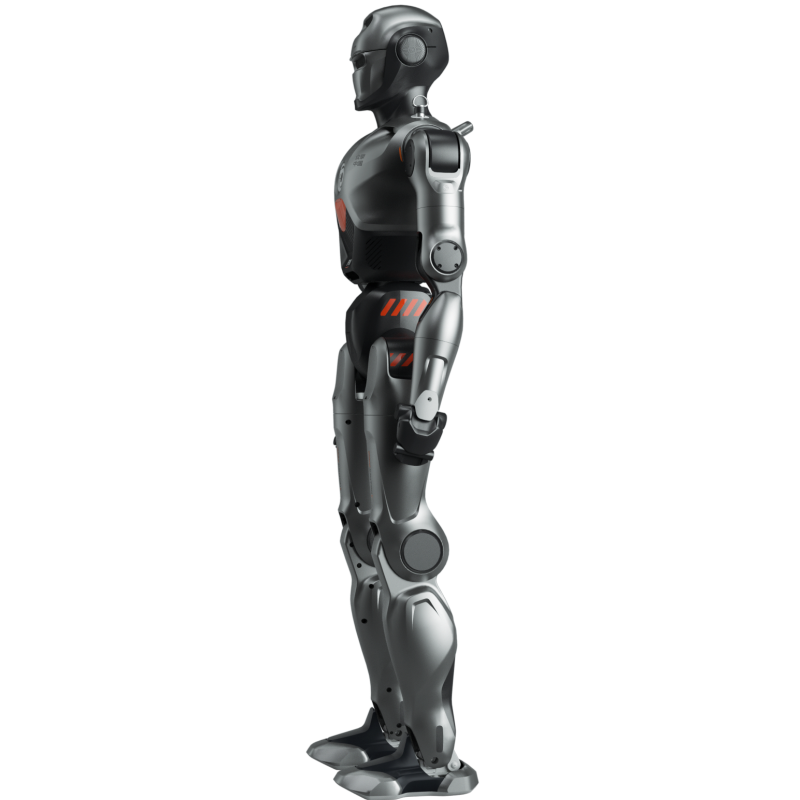
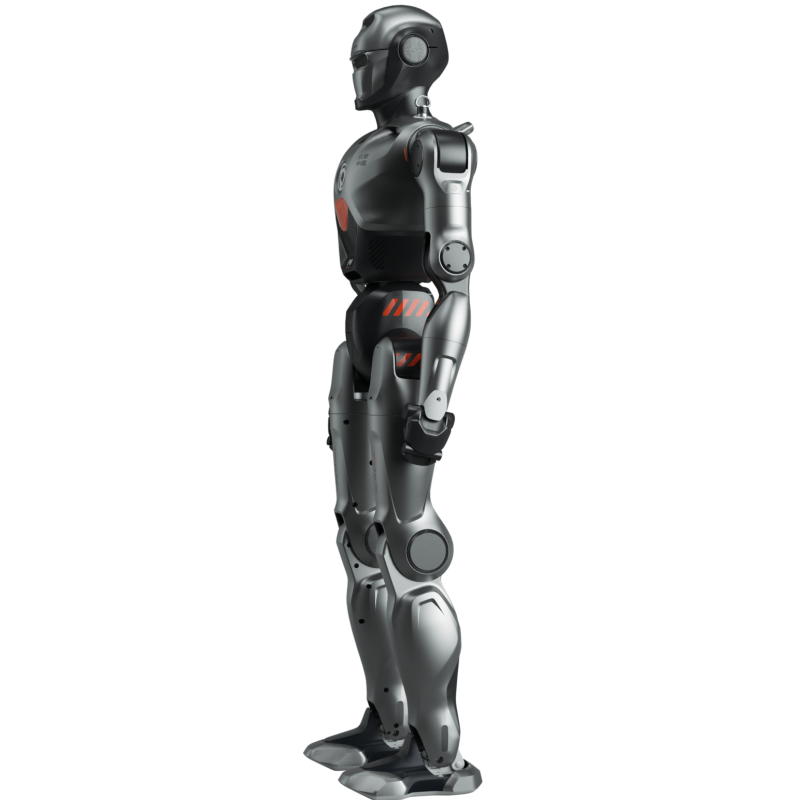
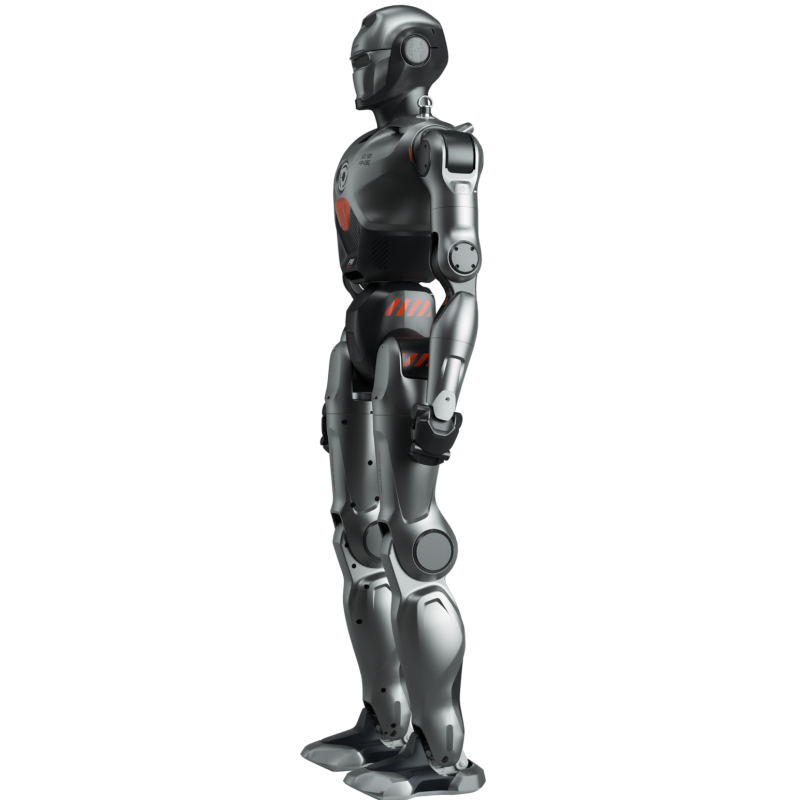
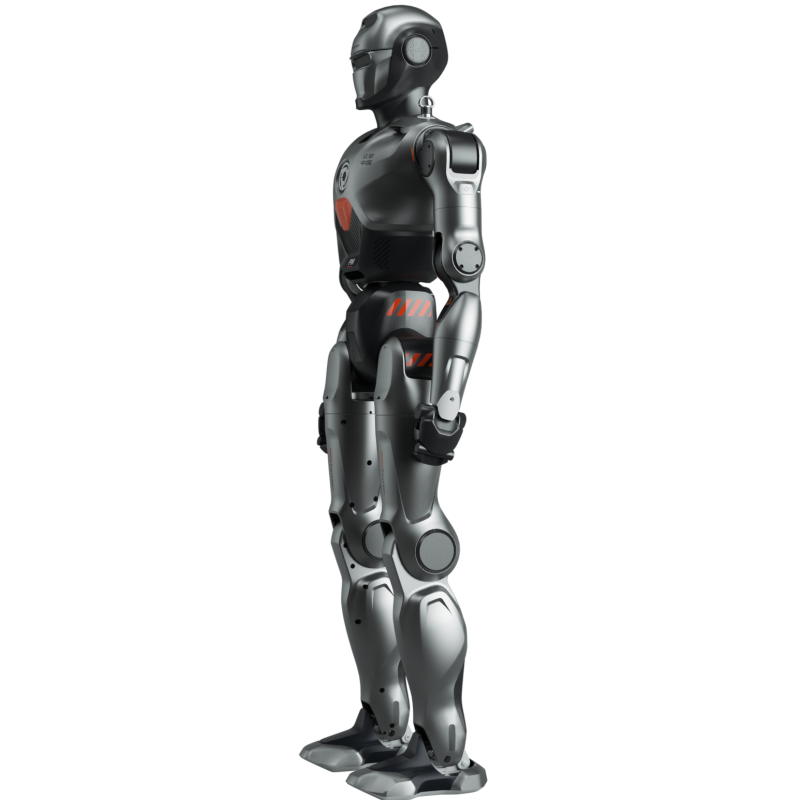
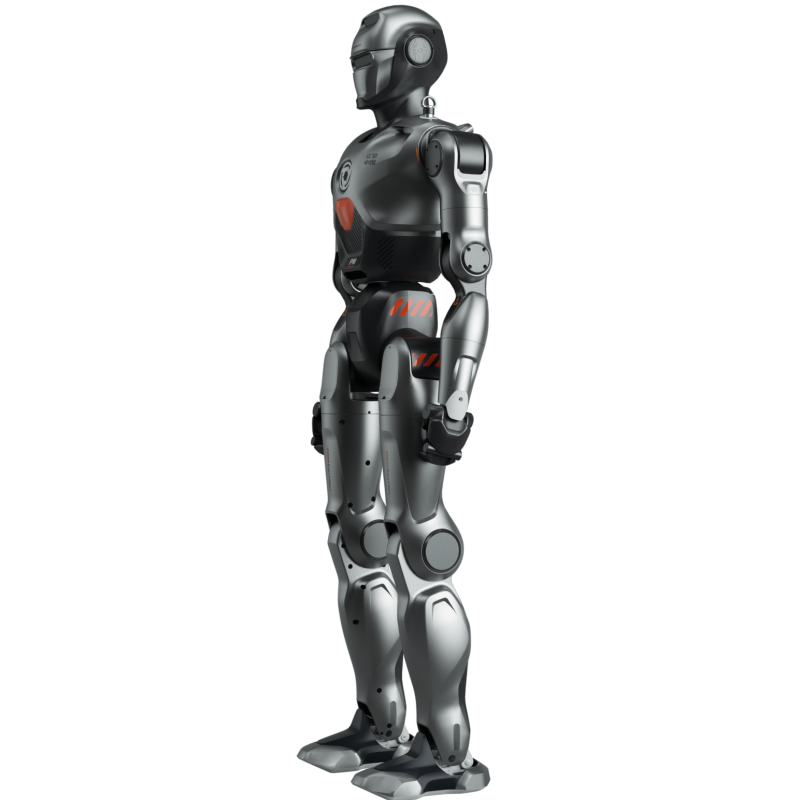
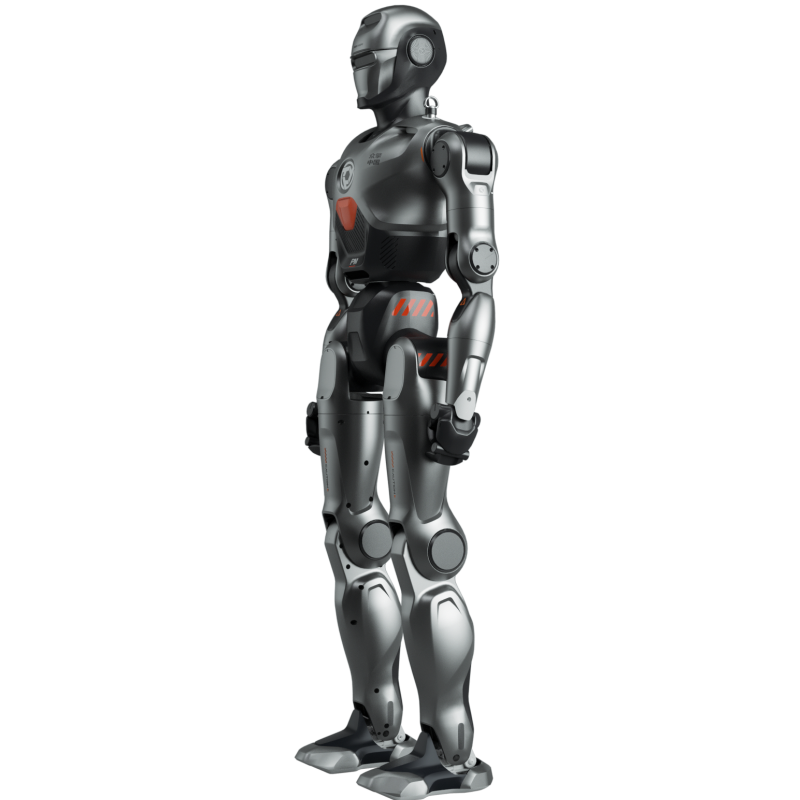
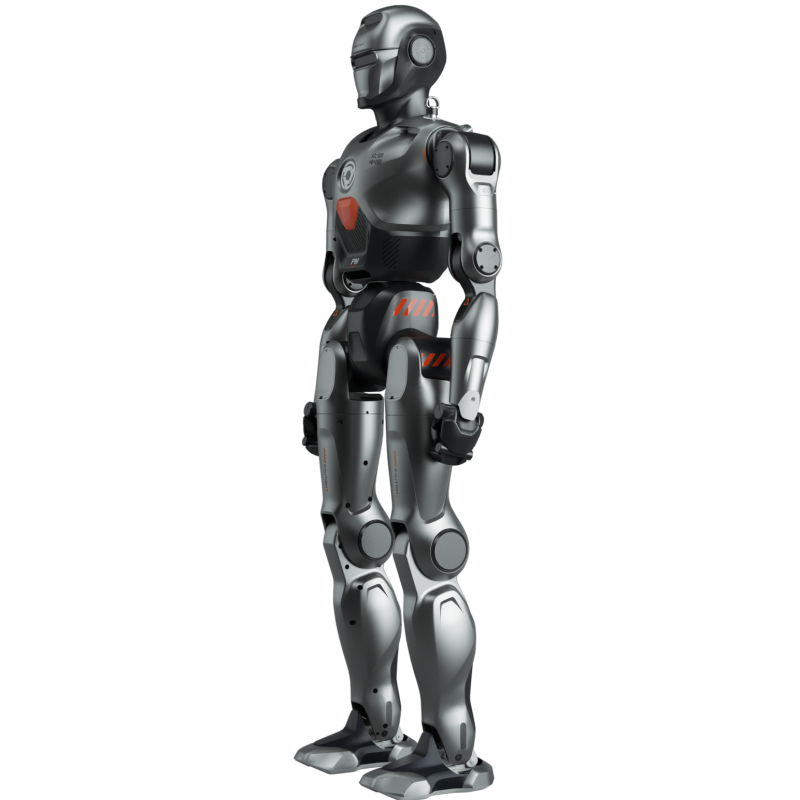
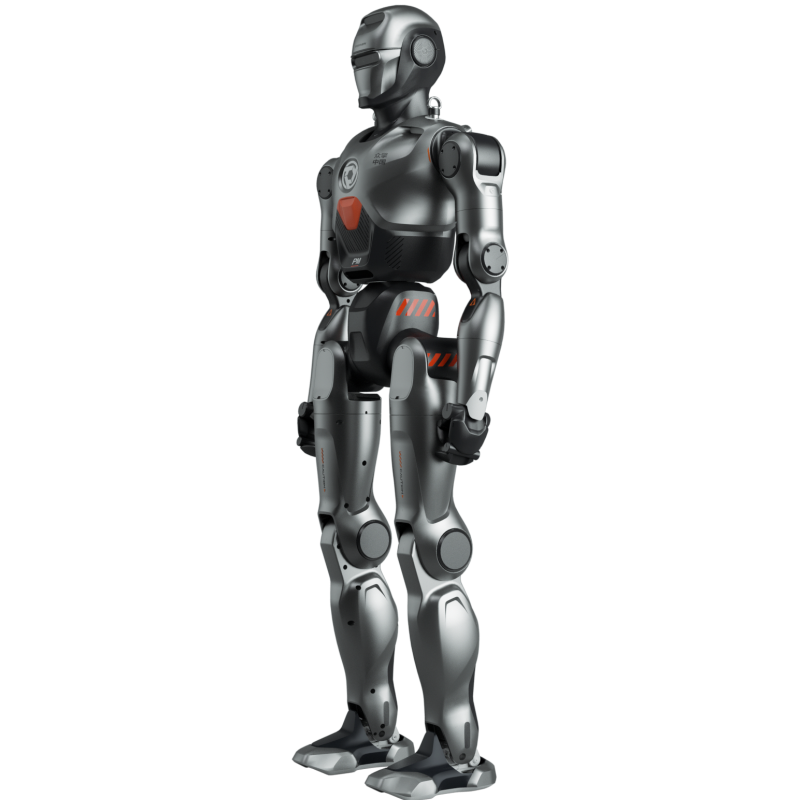
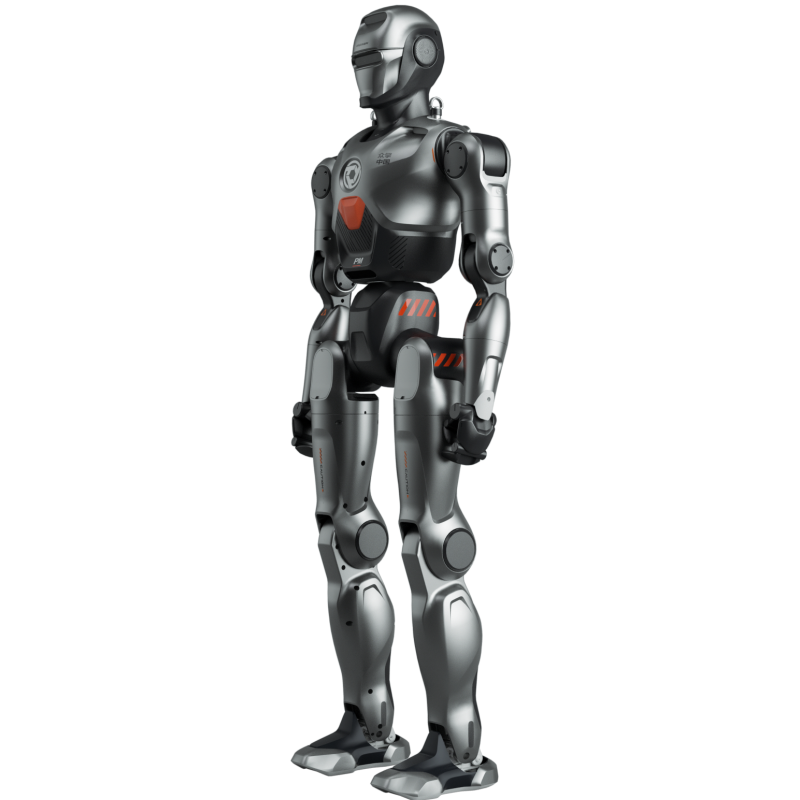
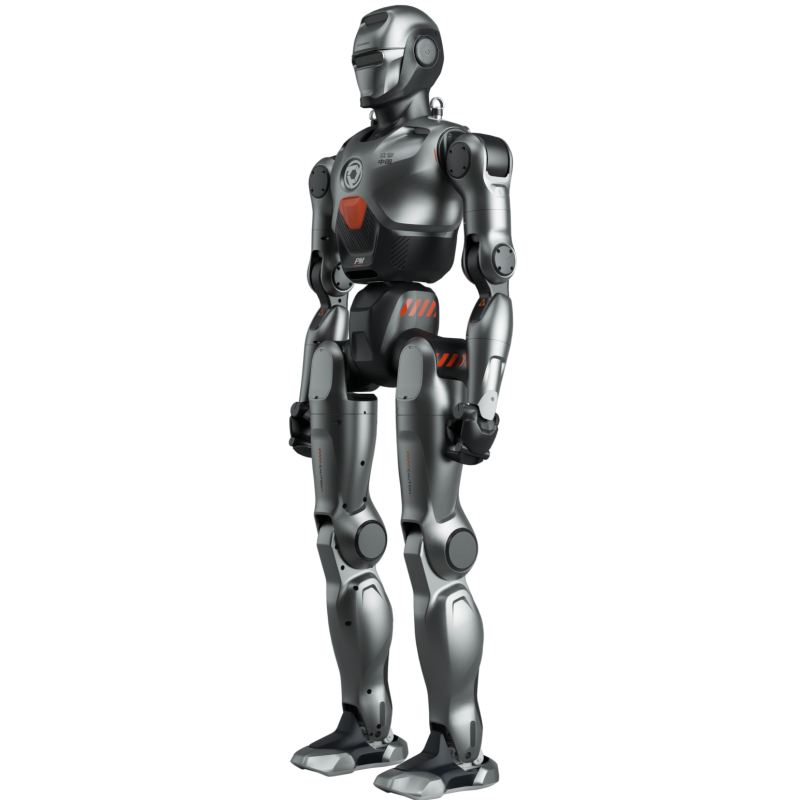

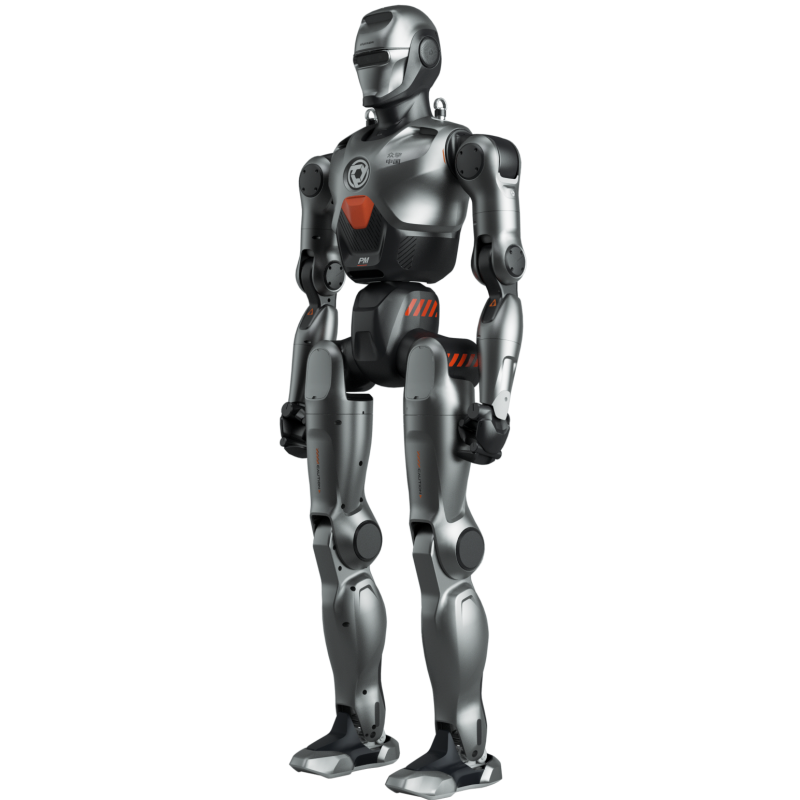

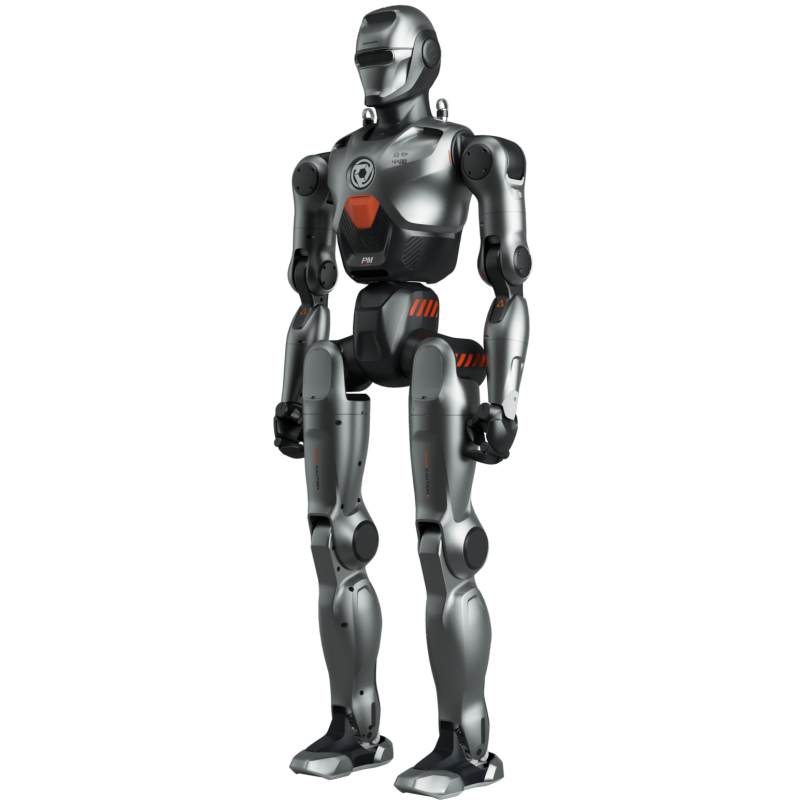

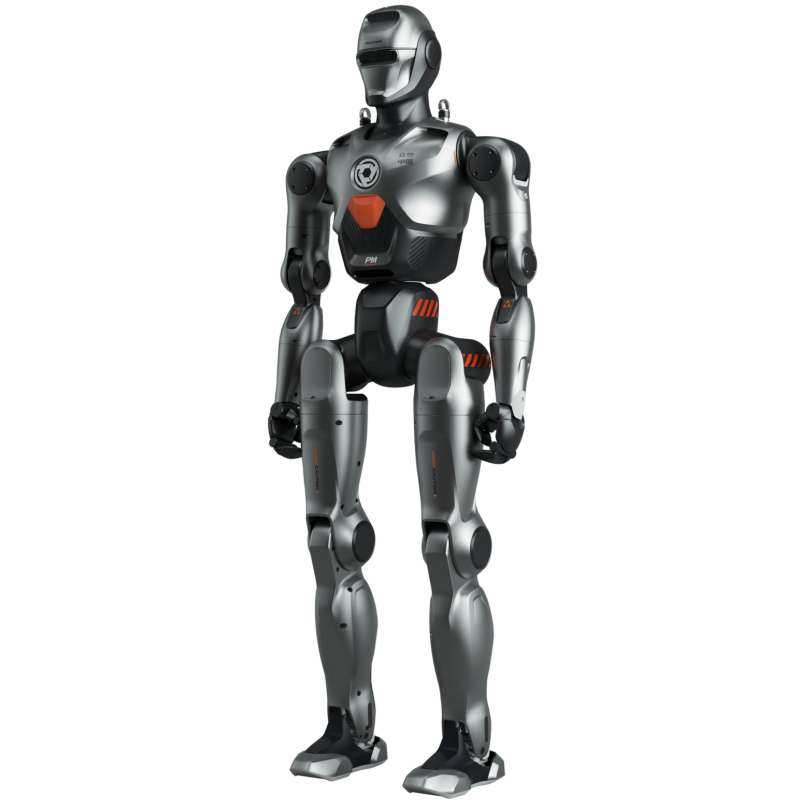
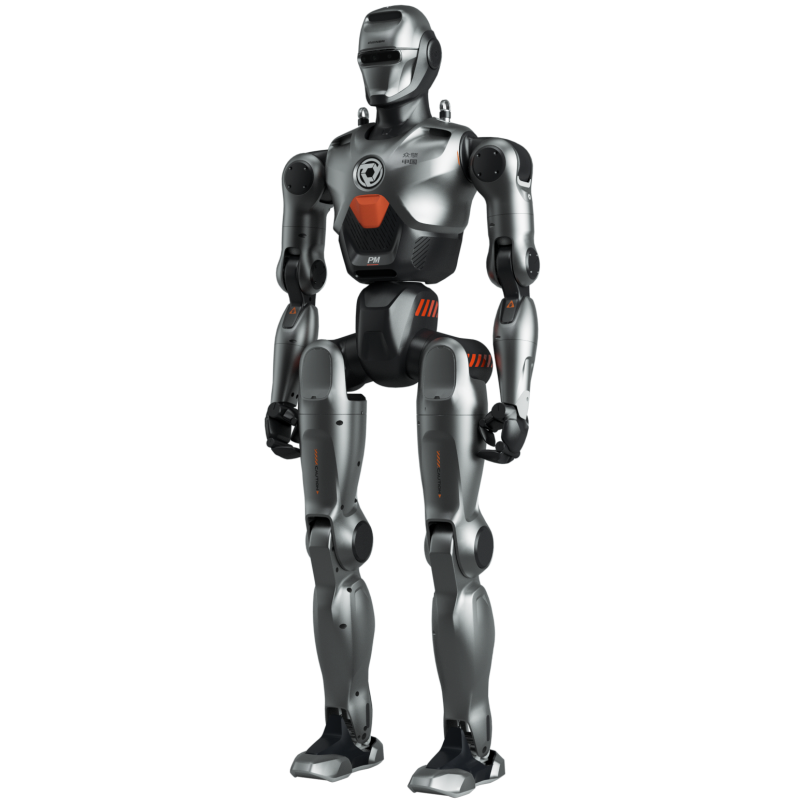
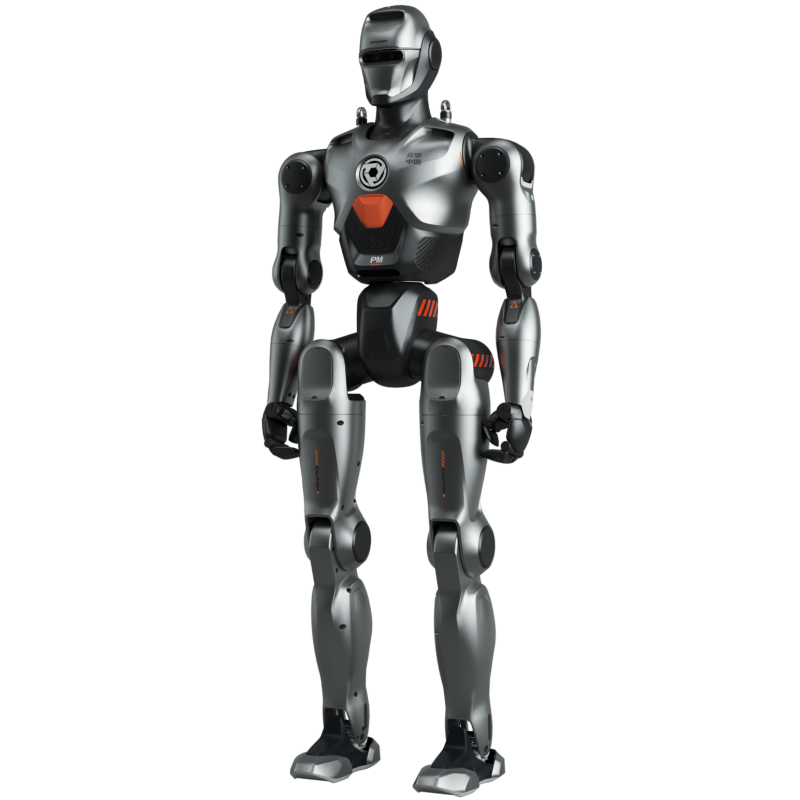


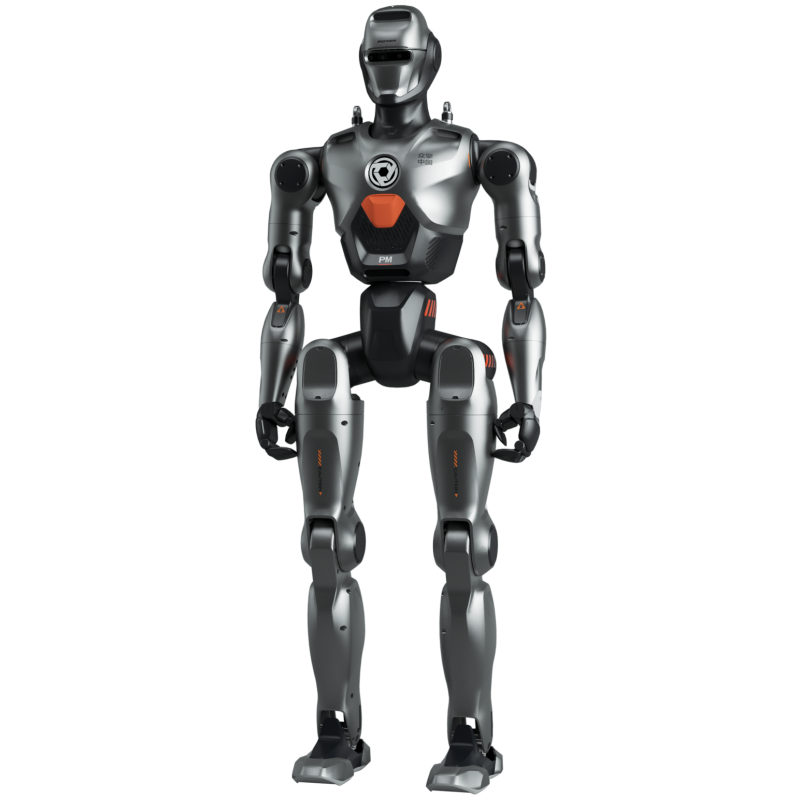
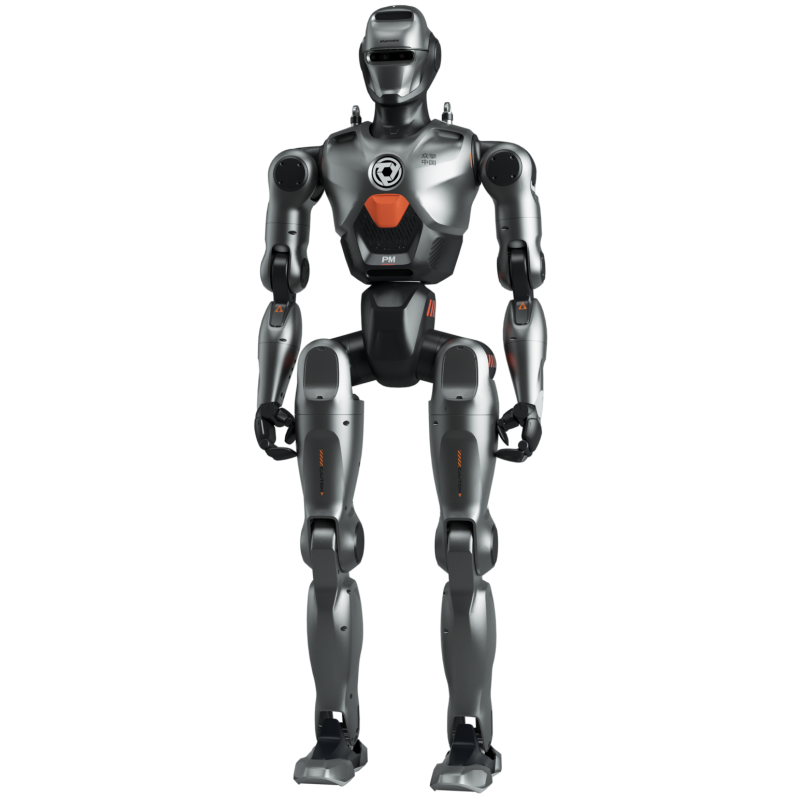
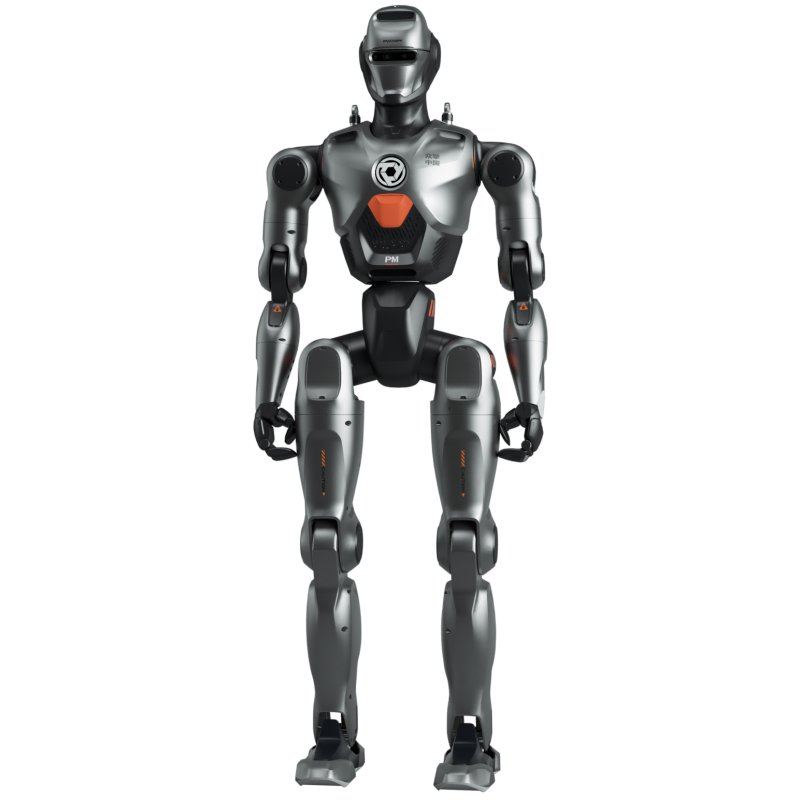
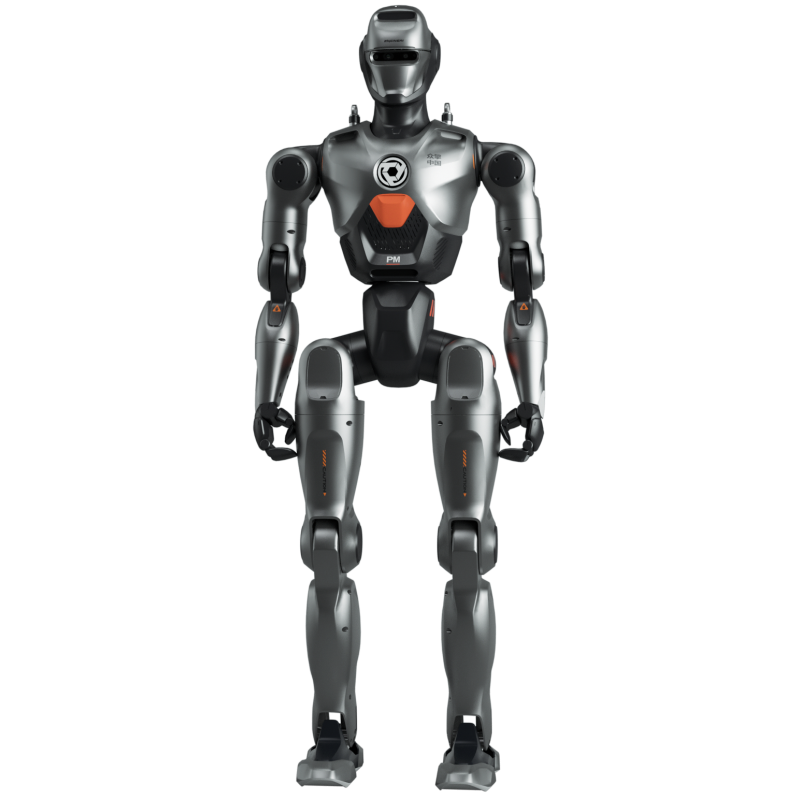

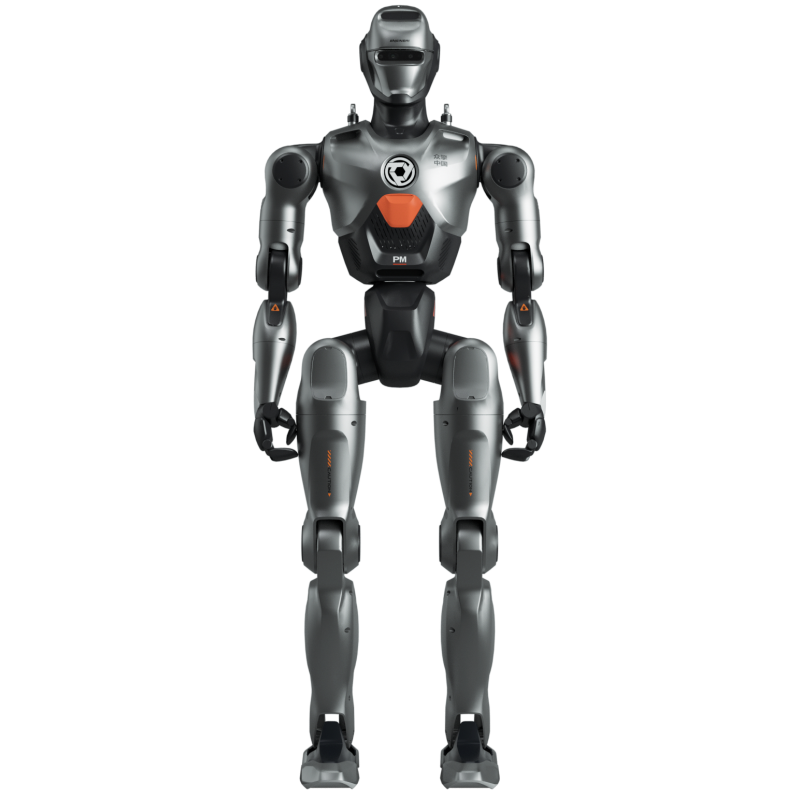
Core Parameters
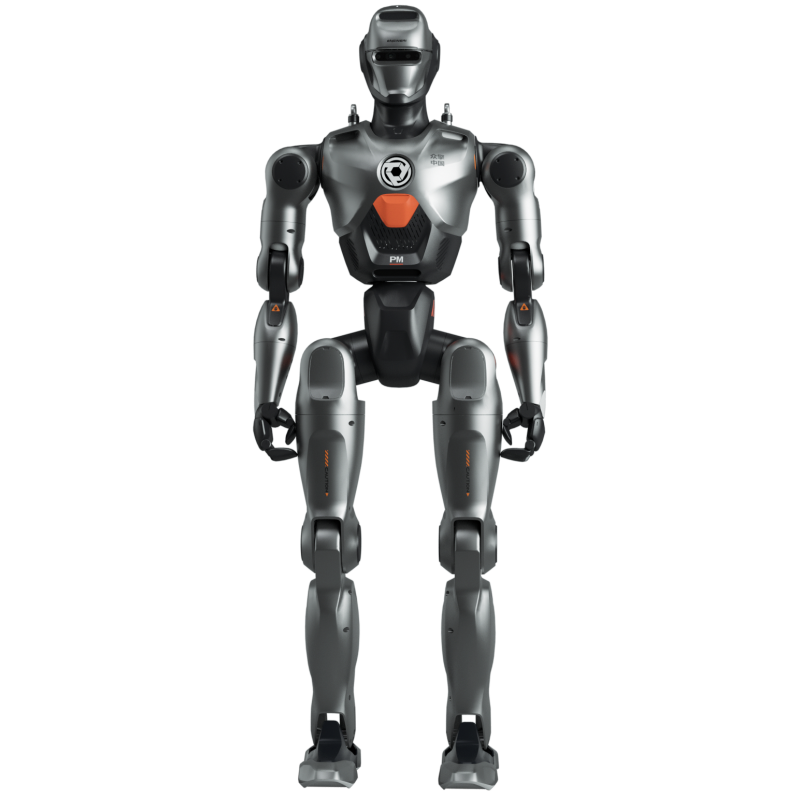

Lighting setup
Highly Recognizable Signature Star Halo Light
Touchscreen
Waist Joint Movement
>300°
Hip joint movement
R-29°~+134°、P-180°~+140°、Y-90°~+230°
Robot foot movement
All-Terrain Adaptation
Knee joint movement
-30°~+137°
Lighting setup
Highly Recognizable Signature Star Halo Light
Touchscreen
Waist Joint Movement
>300°
Hip joint movement
R-29°~+134°、P-180°~+140°、Y-90°~+230°

Robot foot movement
All-Terrain Adaptation
Knee joint movement
-30°~+137°
Detailed specifications
-
2026 EDUCATION EDITION
Dimension
1400(H) x 540(W) x 253(D)mm
Weight (with Battery)
Approx. 44.0kg
Leg Length (Thigh + Lower Leg)
686.5mm
Arm Span (Arms Fully Extended)
1440mm
Single-Arm Length
(Upper Arm+Forearm)470mm
Total Degrees of Freedom (Number of Joint Motor)
24
Neck DOF
1
Single-leg DOF
6
Waist DOF
1
Single-arm DOF
5
Joint Output Bearing
Indusrial-Grade High-Precision Crossed Roller Bearing (with High Load Capacity)
Joint Motor
Ultra-High-Speed Internal Rotor Permanent Magnet Synchronous Motor (Superior Heat Dissipation)
Max Torque [1]
164 N·m
Peak Torque Density[1]
145 Nm/kg
Structural Material
Aviation Aluminum
-
Electrical Specifications
Moving Speed
>2m/s(Hardware Supported)
Cooling System
Super Air-Cooled Heat Dissipation
Smart Battery
Intelligent Quick Disassembly Supported
Battery Life
2h
Charging Power
54.6V/4.5A
Charging Duration
2h for Full Charge
Perception Sensors
Ultra-Wide Field-of-View Binocular Camera x2 (Head&Waist)
3D LiDAR
/
Voice Interraction
√
-
Computing&
Development SupportBase Computing Power
8 CORE High Performance CPU
High Computing Module
NVIDIA Jetson Orin NX (16G)
Controller
Handheld Touchscreen Remote Controller
Touch Screen (Chest)
√
Sencondary Development[2]
√
-
2026 NAVIGATION EDITION
Dimension
1400(H) x 540(W) x 295(D)mm
Weight
(with Battery)Approx. 44.5kg
Leg Length
(Thigh + Lower Leg)686.5mm
Arm Span
(Arms Fully Extended)1440mm
Single-Arm Length
(Upper Arm+Forearm)470mm
Total Degrees of Freedom (Number of Joint Motor)
24
Neck DOF
1
Single-leg DOF
6
Waist DOF
1
Single-arm DOF
5
Joint Output Bearing
Indusrial-Grade High-Precision Crossed Roller Bearing (with High Load Capacity)
Joint Motor
Ultra-High-Speed Internal Rotor Permanent Magnet Synchronous Motor (Superior Heat Dissipation)
Max Torque [1]
164 N·m
Peak Torque Density[1]
145 Nm/kg
Structural Material
Aviation Aluminum
-
Electrical Specifications
Moving Speed
>2m/s(Hardware Supported)
Cooling System
Super Air-Cooled Heat Dissipation
Smart Battery
Intelligent Quick Disassembly Supported
Battery Life
2h
Charging Power
54.6V/4.5A
Charging Duration
2h For Full Charge
Perception Sensors
Ultra-Wide Field-of-View Binocular Camera x2 (Head&Waist)
3D LiDAR
√
Voice Interraction
√
-
Computing&
Development SupportBase Computing Power
8 CORE High Performance CPU
High Computing Module
NVIDIA Jetson Orin NX (16G)
Controller
Handheld Touchscreen Remote Controller
Touch Screen (Chest)
/
Sencondary Development[2]
√